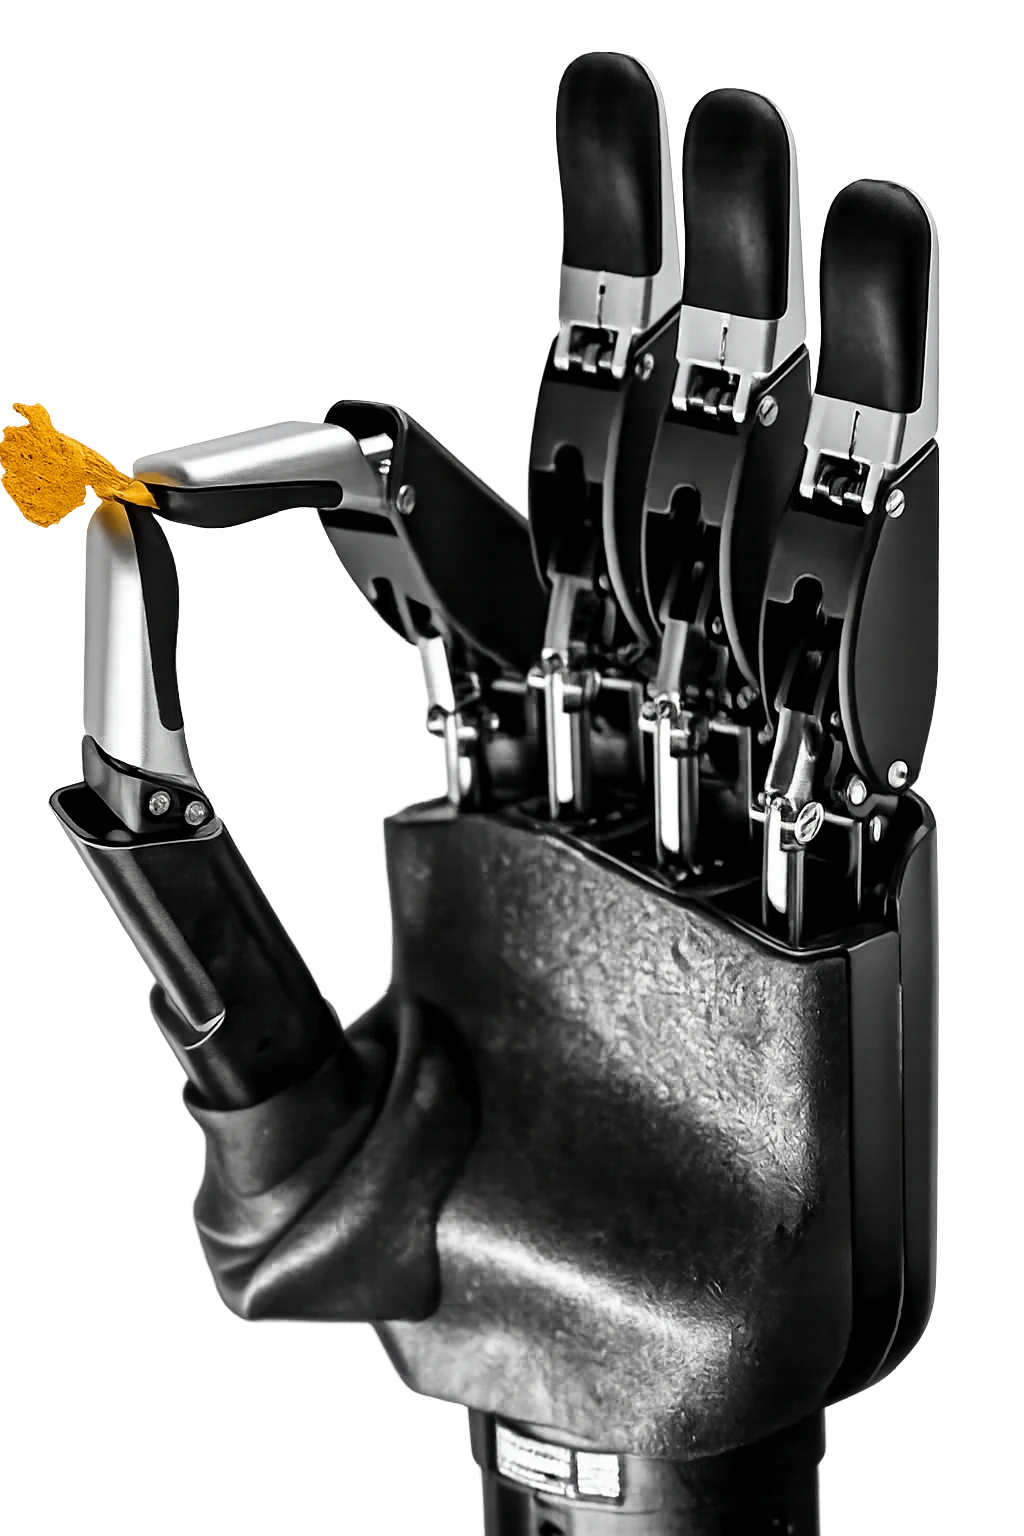
Robotic Hand
DH-Robotics DH-5-6 Dexterous Hand
Brand: DH-Robotics
DH-Robotics DH-5-6 is a five-finger robotic hand for manipulation development and data collection.
Specifications
- Technical specifications / Size
- 236 × 116 × 96 mm (Dimension sequence without labelled axes)
- Technical specifications / Total DOF
- 11 DOF
- Technical specifications / Active DOF
- 6 DOF
- Technical specifications / Cycle time
- 0.8 s
- Technical specifications / Lifting load
- 10 kg (Grip method and geometry unspecified in table)
- Technical specifications / Communication
- Modbus RTU / custom RS485 (M3 or M4 protocol selected by ordering code)
- Technical specifications / Thumb bending
- 38 + 7 °
- Optional tactile sensors / Pressure range
- 0-2 MPa (Optional tactile array)
- Optional tactile sensors / Array placement
- Fingertips and palm (Optional tactile sensors)
- Technical specifications / Fingertip force
- 25 N
- Technical specifications / Tactile sensing
- Optional
- Technical specifications / Weight per hand
- 790 g
- Technical specifications / Operating voltage
- 24 V (DC; ±10%)
- Optional tactile sensors / Sensor sensitivity
- 2.5 kPa⁻¹ (Optional tactile array)
- Technical specifications / Hand grip strength
- 80 N
- Optional tactile sensors / Sensor service life
- >5,000,000 cycles (Optional tactile array)
- Technical specifications / Four-finger bending
- 83 + 87 °
- Technical specifications / Thumb lateral swing
- 85 °
- Optional tactile sensors / Sensor response time
- <0.62 ms (Optional tactile array)
- Technical specifications / Stated hand service life
- ≥1000000 cycles (Manufacturer claim; test conditions unspecified)
- Construction and mounting configurations / Connector
- M8 (Hand technical drawing)
- Construction and mounting configurations / Hand side
- Left / right (L / R configurations)
- Technical specifications / Recommended friction load
- 2 kg (Recommended maximum)
- Construction and mounting configurations / Connection
- Plug & Play
- Construction and mounting configurations / Controller
- Built-in
- Construction and mounting configurations / Z1 adapter
- PCD 50; boss 31.5 mm (Z1 adapter configuration)
- Construction and mounting configurations / Z2 adapter
- PCD 49; boss 18 mm (Z2 adapter configuration)
- Construction and mounting configurations / Installation
- Bottom mounting
- Technical specifications / Recommended structural lifting
- 4 kg (Recommended maximum)
- Construction and mounting configurations / Drive mechanism
- Coreless motor; planetary reducer; ball screw; linkage
- Construction and mounting configurations / Extension cable
- 1 / 3 / 5 / 10 m (L1 / L3 / L5 / L10 configurations)
- Construction and mounting configurations / Grasp buffering
- Anti-collision buffering (For inward grasping)
- Construction and mounting configurations / Standard flange
- Without adapter (Z0 configuration)
- Construction and mounting configurations / Wrist interface
- Standard / quick-release (N / F configurations)
- Construction and mounting configurations / Speed adjustment
- Not included
- Construction and mounting configurations / Position adjustment
- Included
- Construction and mounting configurations / Grip-force adjustment
- Included
Source and import record
Catalog information was imported from the Unibot owner catalog. This source record documents provenance and import time; it is not an independent verification of the component information.
Imported 2026-11-11