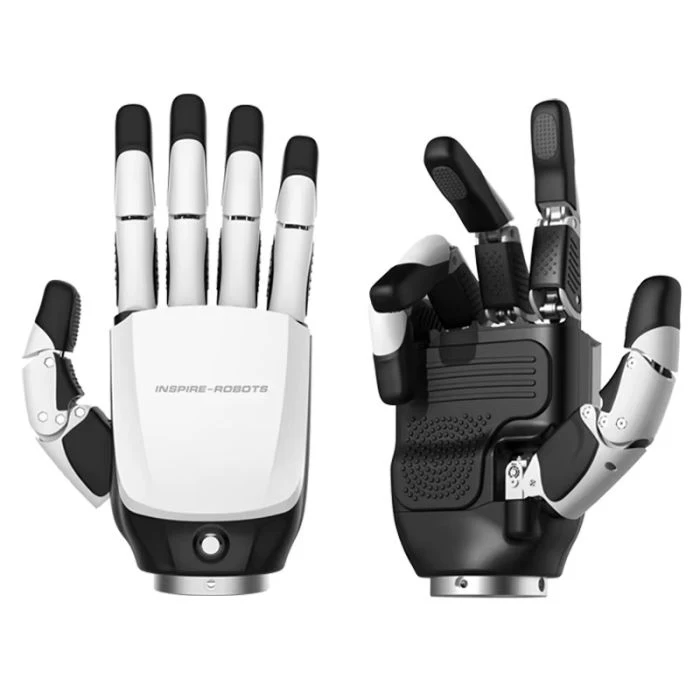
Robotic Hand
Inspire Robots RH56E2
Brand: Inspire Robots
Inspire Robots RH56E2 is an anthropomorphic hand for grasping research and robotic manipulators.
Specifications
- RH56E2: website variants / Interfaces
- RS485 /CAN /ModbusTCP (Depending on selected interface version)
- RH56E2: website variants / Joint count
- 12 pcs
- RH56E2: website variants / Peak current
- 4 A (At24V)
- RH56E2: website variants / Repeatability
- ±0.20 mm
- RH56E2: website variants / Fingertip force
- 28 N
- RH56E2: website variants / T1 RS485 models
- RH56E2-2L-T1 / RH56E2-2R-T1
- RH56E2: manual V1.0.0 (2025) / Motion modes
- Speed with force protection / closed-loop force control
- RH56E2: website variants / Force resolution
- 0.05 N
- RH56E2: website variants / T1 tactile range
- 0...30 N
- RH56E2: website variants / T2 tactile range
- 0...20 N
- RH56E2: manual V1.0.0 (2025) / Force sensors
- 6 pcs
- RH56E2: website variants / Hand closing time
- 0.8 s
- RH56E2: website variants / Operating voltage
- 24 ±10% V DC
- RH56E2: website variants / Degrees of freedom
- 6 DoF
- RH56E2: website variants / Interface suffixes
- 0: CAN; 2: RS485
- RH56E2: website variants / T1 tactile sensors
- 17 pcs (Resistive)
- RH56E2: website variants / T2 tactile sensors
- 5 pcs (Capacitive)
- RH56E2: manual V1.0.0 (2025) / RS485 baud rate
- 115200 bps (8N1)
- RH56E2: manual V1.0.0 (2025) / Wrist connector
- 1BZ1G08CLL00000 (Compatible with Lemo FGG-1B-8P)
- RH56E2: website variants / Thumb flexion speed
- >130 °/s
- RH56E2: website variants / Thumb lateral range
- 75-170 °
- RH56E2: website variants / Thumb lateral speed
- >130 °/s
- RH56E2: website variants / Weight with tactile
- 0.790 ±0.010 kg (T1 or T2 configuration)
- RH56E2: manual V1.0.0 (2025) / Linear actuators
- 6 pcs
- RH56E2: manual V1.0.0 (2025) / Actuator feedback
- Position, angle, force, current, temperature and errors
- RH56E2: manual V1.0.0 (2025) / Four-finger angle
- 91.5-170 °
- RH56E2: manual V1.0.0 (2025) / Parameter storage
- FLASH and parameter restore
- RH56E2: manual V1.0.0 (2025) / Quiescent current
- 0.2 A (At 24 V)
- RH56E2: website variants / Thumb fingertip force
- 30 N
- RH56E2: website variants / Weight without tactile
- 0.770 ±0.010 kg
- RH56E2: manual V1.0.0 (2025) / Thumb bending angle
- 28.5-64 °
- RH56E2: website variants / T1/T2 quiescent current
- 0.25 A (At 24 V)
- RH56E2: website variants / Tactile sensor accuracy
- ≤5 % FS (Full scale of sensor)
- RH56E2: manual V1.0.0 (2025) / Maximum-grip current
- 4.5 A (At 24 V)
- RH56E2: manual V1.0.0 (2025) / Thumb rotation angle
- 75-170 °
- RH56E2: website variants / Four-finger flexion speed
- >200 °/s
- RH56E2: manual V1.0.0 (2025) / Average no-load current
- 1.2 A (At 24 V)
- RH56E2: manual V1.0.0 (2025) / Connection alternatives
- Modbus TCP + CAN2.0 / Modbus TCP + RS485
- RH56E2: manual V1.0.0 (2025) / Force-sensor resolution
- 0.1 N
- RH56E2: website variants / Non-tactile quiescent current
- 0.2 A (At 24 V)
- RH56E2: manual V1.0.0 (2025) / Five-finger gripping force
- 30 N
Source and import record
Catalog information was imported from the Unibot owner catalog. This source record documents provenance and import time; it is not an independent verification of the component information.
Imported 2026-11-11