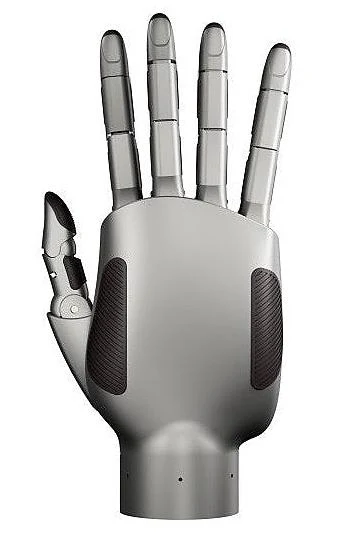
Robotic Hand
Linker Hand L20
Brand: Linkerbot
Linker Hand L20 is a multi-finger robotic hand from Linkerbot for manipulation research and application development.
Specifications
- Technical specifications / Mass
- ≈1200 g
- Technical specifications / Interfaces
- CAN / RS485
- Technical specifications / Maximum load
- 20 kg (Manufacturer claim; grip geometry, orientation and test method unspecified; not grip force)
- Technical specifications / Repeatability
- ±0.20 mm (Depends on scene, configuration and version; test conditions not disclosed)
- Technical specifications / Static current
- 0.3 A
- Technical specifications / External supply
- 24-48 V (External power source)
- Technical specifications / Maximum current
- 1.8 A
- Technical specifications / Degrees of freedom
- 21 DOF (16 active + 5 passive)
- Technical specifications / Thumb fingertip force
- 15 N (Maximum)
- Technical specifications / Five-finger grip force
- 100 N (Maximum)
- Technical specifications / Unloaded moving current
- 0.4 A (Average during unloaded movement)
- Technical specifications / Four-finger fingertip force
- 20 N (Maximum; individual or aggregate measurement method unspecified)
Source and import record
Catalog information was imported from the Unibot owner catalog. This source record documents provenance and import time; it is not an independent verification of the component information.
Imported 2026-11-11