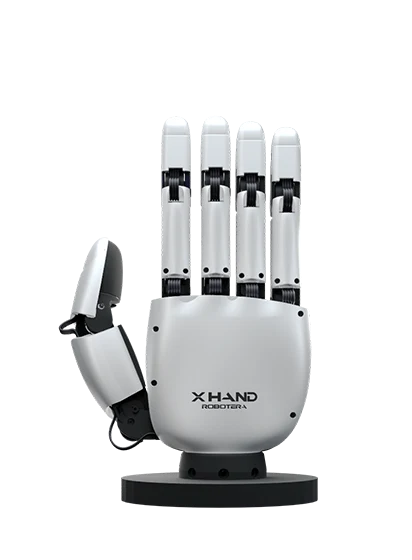
Robotic Hand
Robotera XHAND1
Brand: ROBOTERA
ROBOTERA XHAND1 is an anthropomorphic five-finger hand for robotic arms and humanoid platforms.
Specifications
- XHAND1 / Width
- 9.4 cm (Hand placed flat)
- XHAND1 / Length
- 19.1 cm (Hand placed flat)
- XHAND1 / Weight
- 1.1 kg
- XHAND1 / Fingers
- 5 pcs
- XHAND1 / Thickness
- 4.7 cm (Hand placed flat)
- XHAND1 / Thumb DOF
- 3 DoF
- XHAND1 / Interfaces
- EtherCAT /RS485 USB
- XHAND1 / URDF model
- Tactile simulation
- XHAND1 / Passive DoF
- 0 DoF
- XHAND1 / Joint module
- Reducer / motor / driver / encoder
- XHAND1 / Motor torque
- >1 N·m
- XHAND1 / Control modes
- Position (low/high damping) / current-loop force / force-position
- XHAND1 / Teleoperation
- Vision Pro / Manus / Pico / Meta Quest (Through compatible control equipment and integration)
- XHAND1 / Active degrees
- 12 DoF
- XHAND1 / Drag-and-teach
- Supported
- XHAND1 / Backdrivability
- Supported
- XHAND1 / Fingertip force
- 15 N (Maximum)
- XHAND1 / Maximum payload
- 25 kg (Palm facing up)
- XHAND1 / Ring-finger DOF
- 2 DoF
- XHAND1 / Thumb actuation
- 3 gear-driven force-controlled joint modules
- XHAND1 / Index-finger DOF
- 3 DoF
- XHAND1 / Little-finger DOF
- 2 DoF
- XHAND1 / Middle-finger DOF
- 2 DoF
- XHAND1 / Tactile equipment
- 3D tactile arrays on all fingertips (Tactile-equipped configuration of the extended brochure)
- XHAND1 / Back-drive damping
- ≤0.1 N·m
- XHAND1 / Fingertip coverage
- 270 °
- XHAND1 / Temperature sensing
- Supported (Tactile-equipped configuration)
- XHAND1 / No-load grasp cycles
- 1000000 cycles (No load)
- XHAND1 / Simulation platforms
- Isaac Gym / MuJoCo
- XHAND1 / Compatible robot arms
- xArm / Realman / UR
- XHAND1 / Four-finger actuation
- 9 gear-driven force-controlled joint modules
- XHAND1 / Open-close repetition
- >2 Hz
- XHAND1 / Single-finger payload
- 5 kg
- XHAND1 / Whole-hand grip force
- 80 N
- XHAND1 / Software compatibility
- TwinCAT / ROS1 / ROS2 / Ubuntu / x64 / ARM
- XHAND1 / Fingertip configuration
- Round / rounded
- XHAND1 / Fingertip repeatability
- ±0.20 mm (Under load)
- XHAND1 / RS485 communication rate
- 3 MHz
- XHAND1 / Tactile array resolution
- 12 ×10 ×5 (12×10 per each of 5 fingertips; 270° coverage)
- XHAND1 / Thumb farthest opposition
- Little finger
- XHAND1 / Index-finger lateral swing
- −15...+15 °
- XHAND1 / Tactile sensing dimensions
- 3D force including tangential X/Y
- XHAND1 / EtherCAT communication rate
- 100 MHz
- XHAND1 / Stated tactile-force accuracy
- 0.05 N (Tactile-equipped configuration)
- XHAND1: earlier official two-page brochure / Tactile sensors
- Optional equipment
- XHAND1: earlier official two-page brochure / Development tools
- Linux SDK / ROS-compatible applications / PC evaluation app
- XHAND1: earlier official two-page brochure / Thumb movement angle
- <110 °
- XHAND1: earlier official two-page brochure / Minimum grasp diameter
- 16 mm
- XHAND1: earlier official two-page brochure / Dimensions in source order
- 190.36 ×94 ×47 mm
Source and import record
Catalog information was imported from the Unibot owner catalog. This source record documents provenance and import time; it is not an independent verification of the component information.
Imported 2026-11-11