Humanoid robots on tea plantations undergo field testing ahead of 2026 games
English translation from Unibot. Source published 2026-05-26.
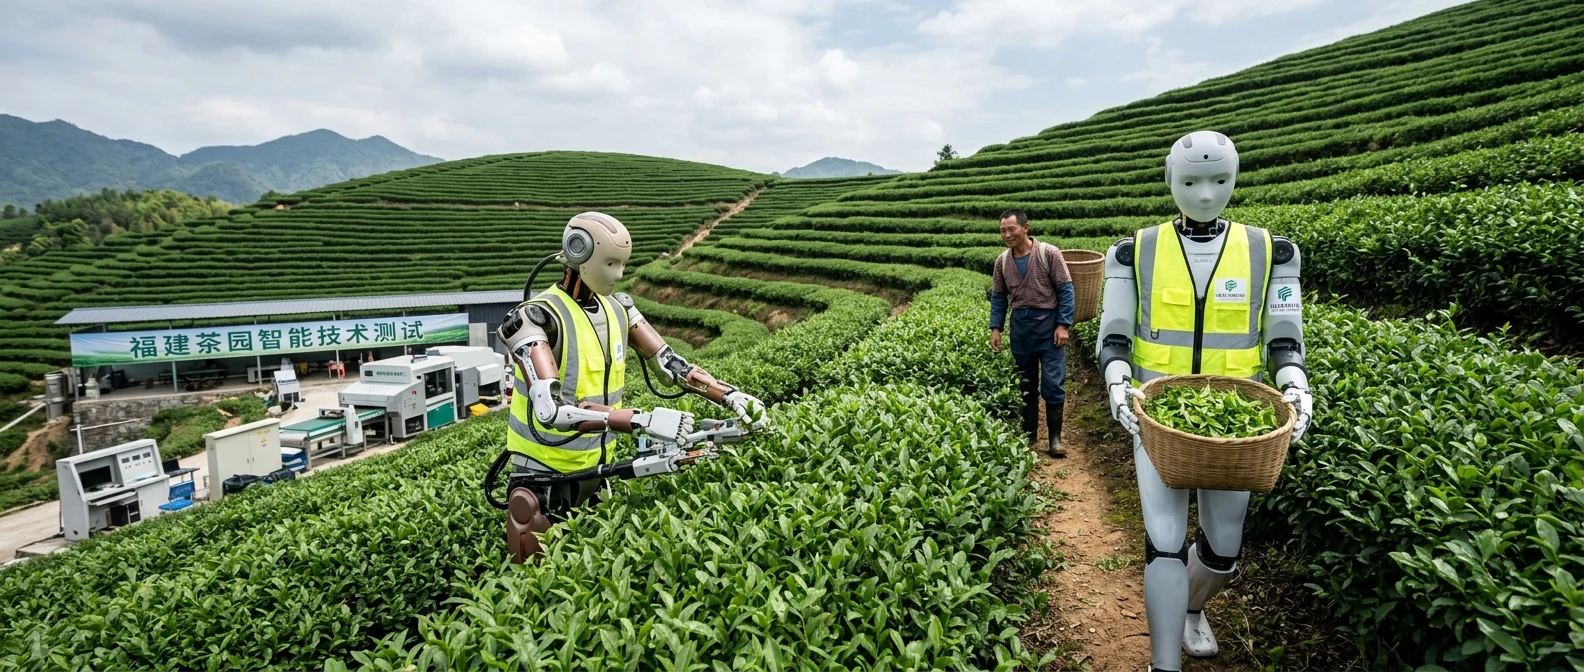
On May 10, in the tea gardens of Fuding, Fujian province, humanoid robots were field tested: they collected leaves, carried loads and participated in tea processing - this time in real agricultural conditions, and not in the laboratory. The test is important in that it tests whether humanoids are capable of simultaneously handling uneven terrain, variable vegetation, and delicate manipulation. It's also an early demonstration ahead of the 2026 World Humanoid Robot Games in China.
Humanoid robots on tea farms enter real field work
According to China Daily, the robots were tested in several stages of white tea production, rather than as part of a single production. Tasks included identifying and collecting leaves at different stages of maturity, carrying loads over hilly terrain, and assisting with sun drying and roasting. This combination places demands on perception, movement and dexterity at the same time - something that is often not demonstrated in indoor environments.
Why tea gardens are a significant standard
Agricultural work is especially difficult for humanoids because the environment does not follow fixed dimensions or a repeating arrangement of objects. Tea leaves vary in size, maturity and position on the bush; Light changes throughout the day and the ground underfoot may be unstable. All these factors simultaneously interfere with machine vision and grasping accuracy, while the robot needs to maintain balance.
According to the source, tea gardens provide a more rigid benchmark than standardized picking centers because work there is not organized around identical containers, shelves or assembly line rhythms. The robot has to assess the condition of the plants on the spot and choose a way to capture and move without damaging the crop. This makes the test relevant to a broader challenge in humanoid robotics: whether systems can adapt to human workspaces, which are inherently irregular in nature.
As CGTN notes, the Fujian test is designed to collect data for generalist AI systems that will operate in unstructured, human-centric environments. For robot development teams, the value of such tests lies not only in the success of the tasks, but also in where they fail - missed collections, unstable support or incorrect arm position. Field tests reveal edge cases that go undetected in carefully simulated laboratory scenarios.
The tea environment also emphasizes the tension between speed and accuracy. Harvesting and processing require contact with fragile materials, so simple brute force or monotonous, repetitive movements are not sufficient. Even if a humanoid can move around a tea garden, it requires controlled manipulation to be useful in agricultural processes.
The 2026 Games will test robots in more than just athletics
The Fujian event is being touted as part of preparations for the 2026 World Humanoid Robot Games. According to the Global Times, cited in the original article, the program will include 32 competitions, divided between athletic competitions and tests in real-life scenarios. These scenarios are expected to cover homes, hospitals, factories and emergency response situations.
According to the source, this is a broader program compared to the Beijing Games in 2025, which attracted 280 teams and more than 500 robots from 16 countries. The addition of agricultural trials to this trajectory suggests that organizers want humanoid judging to go beyond balance, speed or entertainment acts. It also reflects the growing emphasis on embodied AI performance in environments where objects, coverages, and people's expectations are constantly changing.
What the Fujian test does not yet show is data on throughput, error rates or product quality - the source does not provide relevant metrics. However, humanoid robots on tea farms provide a useful signal about the direction of the assessment: towards field data from non-ideal, real-world workplaces, rather than just polished demonstrations. As more competitions and pilot projects adopt this approach, the gap between benchmarks and deployable robot functionality will become easier to measure.