LimX COSA turns humanoids into autonomous partners
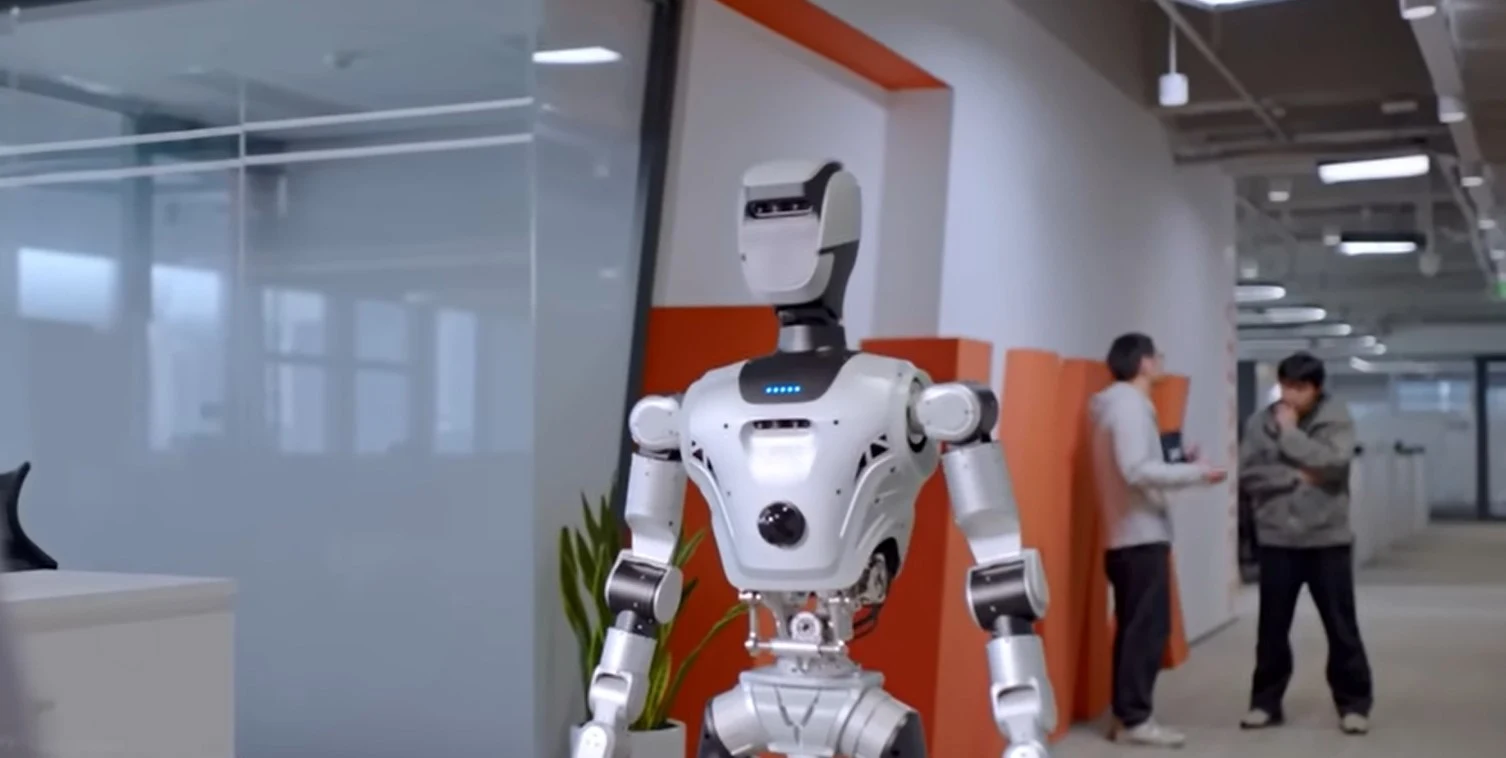
English translation from Unibot. Source published 2026-02-04.
LimX Dynamics introduces COSA, the world's first agentic operating system for humanoid robots. Find out how semantic memory frees robots from amnesia, allowing Oli to think and act proactively.
In 2008, the world of mobile devices changed not because of a new phone, but because of the Android operating system. On January 12, 2026, the robotics industry experienced a similar inflection point. While the West was focused on creating expensive hardware, the Chinese company LimX Dynamics introduced COSA, the world's first physical agent OS. This is not just the “brains” for their new Oli robot, but a bid to be the “universal software” for all humanoid robots on the market.
Biological prototype: three-level hierarchy
COSA (Cognitive OS of Agents) is an architecture that mimics the human nervous system to eliminate the “latency gap”—the awkward pause when a robot pauses to think.
Basic level: A robust foundation model of whole-body control. It is responsible for the “brute force” of physics - balance and locomotion, ensuring that the robot will not fall even on construction debris.
Skill Level: This level links cognitive planning to low-level movement cycles. It controls specific skills: avoiding sudden obstacles, climbing stairs, or lifting a fragile glass.
Cognitive level: This is where “agent” behavior lives. It is responsible for understanding natural language, recognizing intent, and decomposing long-term tasks.
Three pillars of a humanoid agent
The power of COSA lies in three key capabilities that transform a machine into an embodied agent—a robot that not only operates in our world, but understands it.
High-Level Cognition: The Think-While-Action Engine Traditional robots often operate in a “Stop → Think → Action” cycle. They reach their destination, pause to process the next command, and only then react. COSA breaks this cycle by combining the “big brain” (logic) with the “little brain” (movement). This allows the humanoid robot Oli to autonomously decompose long-term tasks, for example: “Find a guest and offer him a drink,” adjusting priorities in real time without stopping.
Semantic memory: the end of “robotic amnesia” Most robots suffer from digital amnesia. They use geometric mapping, seeing the world as a collection of 3D clouds of points and shapes to avoid collisions. However, after completing the path, they often "clean up" this data to save resources. COSA replaces this with semantic memory, allowing Oli to form a stable picture of the world.
Contextual stability: Oli recognizes people, remembers where objects were left, and stores a history of interactions.
Proactive Behavior: With memory, Oli moves from passive waiting to active action. He doesn't just wait for a command, but can proactively check to see if the printer is out of paper, or if a specific colleague needs help, based on what he remembered an hour ago.
Real-time locomanipulationThis is the highest physical manifestation of OS. COSA ensures that cognitive intent is directly realized through sustainable action. It enables locomipulation—the robot's ability to perform complex tasks with its hands while its legs negotiate complex terrain, such as long, uneven stairs.
Flagship: meet Oli
If COSA is the brain, then Oli is the body. At 165 cm tall and weighing 55 kg, Oli is the first humanoid robot designed to demonstrate the full potential of COSA. With 31 degrees of freedom, LimX positions this "agent OS" robot as the first truly accessible humanoid robot for research and industrial deployment