Xiaomi presents a robotic hand with 26 motors for factory tasks
English translation from Unibot. Source published 2026-10-28.
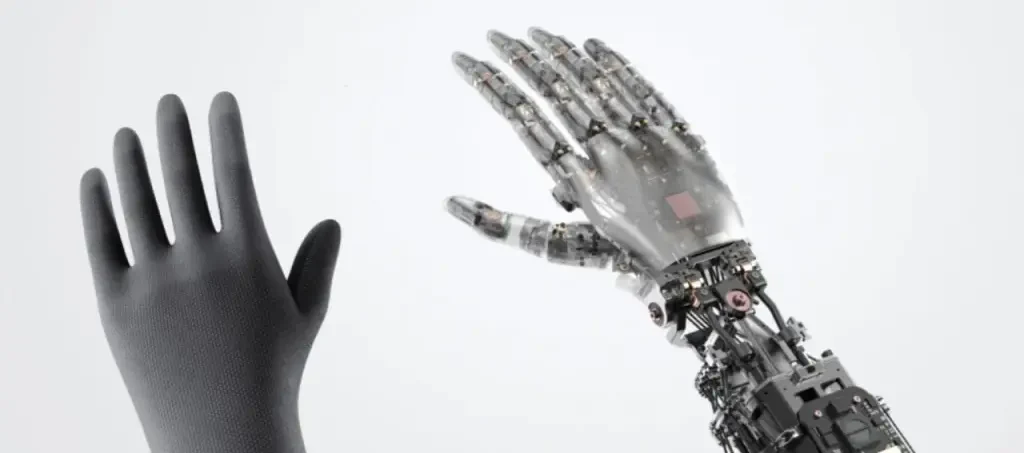
Xiaomi presented a robotic hand for industrial production. It has 21 degrees of freedom, a hybrid drive with 26 motors and 1,500 tactile sensors. XimiTime writes about this.
The development was carried out by the Intelligent Manufacturing division. The task is manipulations related to the company's automobile production. It is not reported when the hand will enter series production or where it will be deployed.
The design combines tendon tension control with dense tactile sensing. According to Xiaomi, this gives precise control of grip force and detailed feedback when handling objects.
Where did the requirements come from?
It was based on 1,827 real-life standard operating procedures collected at Xiaomi's mid-scale automobile manufacturing test center. These procedures cover more than 70% of typical manual operations in 16 key stages of vehicle assembly.
This way the project had a concrete production target, rather than an abstract task of “making a dexterous hand.”
The team also digitized factory tools and parts to simulate the grip from different angles. These simulations tested how the hand would cope with industrial objects. They were also included in the design review mentioned in the report.
What about sensing?
The tactile matrix covers the entire hand. The stated spatial resolution is 1 mm on the knuckles, pads and bases, 2 mm on the palm.
Xiaomi says the sensing system helps analyze and simulate grip, and the hybrid drive should improve reliability, simplify maintenance and improve force control. The team also worked specifically on cooling - after all, it is for industrial use.
The hand continues Xiaomi's previous experiments with haptic gloves. Modular sensors can be replaced one at a time - this is convenient for repairs, upgrades and analysis of tactile data. The anatomy of the sensors follows the structure of the human hand.