Category
Palletizing Robots
Compliance / EMC
Applicable industrial EMC standards (ABB preliminary specification: values may change without notice.)
Execution / Model
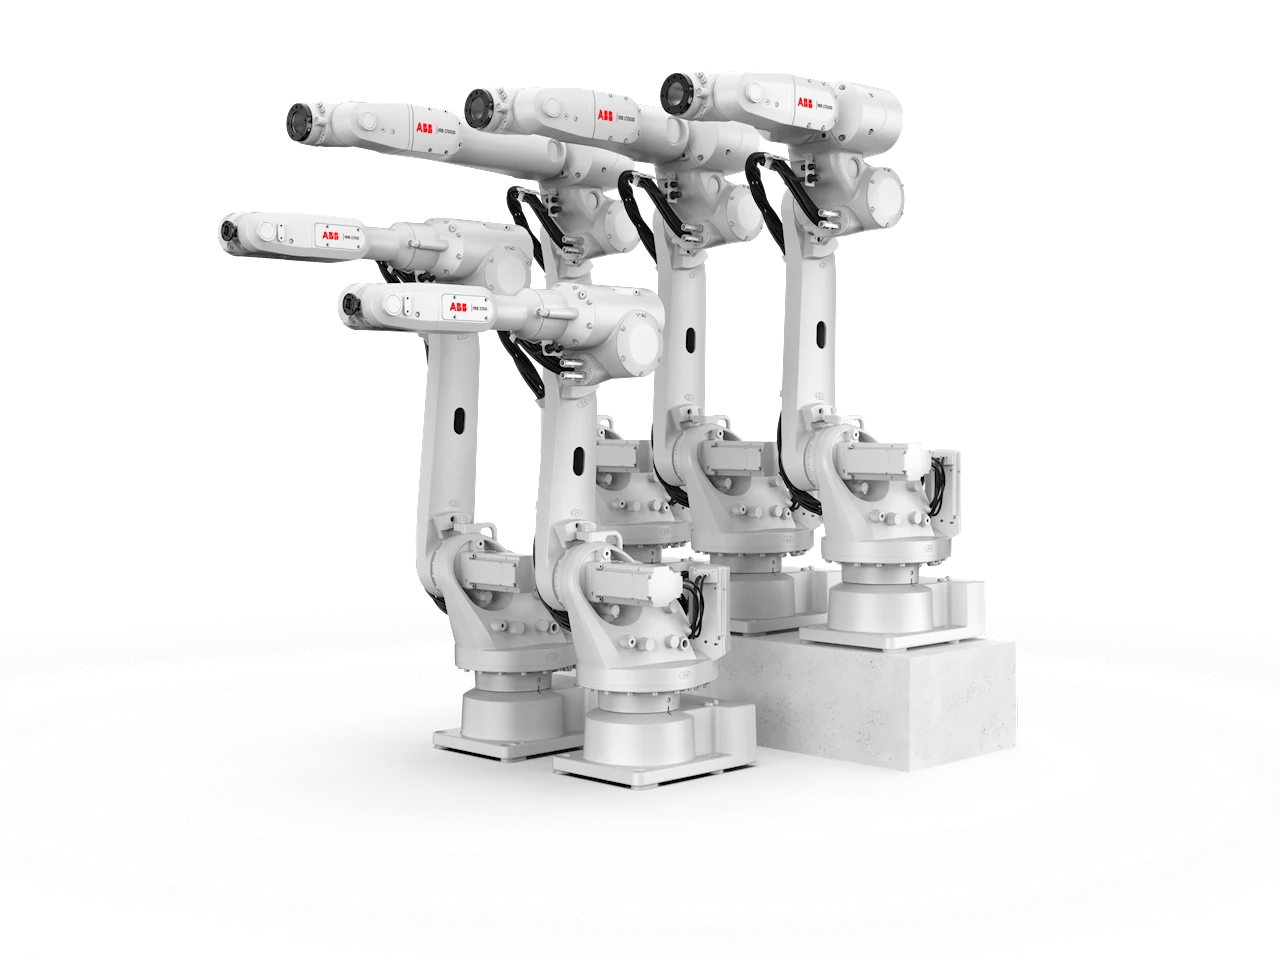
IRB 1700ID-6/1.85
Applications / Tasks
Material handling, arc welding, deburring, sanding, machine tending
Arm / Number of axes
6 (ABB preliminary specification: values may change without notice.)
Axis ranges / Axis 1
±180 ° (For wall mounting, depends on payload and other axis positions; RobotStudio simulation is recommended. ABB preliminary specification: values may change without notice.)
Axis ranges / Axis 2
−90 / +160 ° (ABB preliminary specification: values may change without notice.)
Axis ranges / Axis 3
−165 / +90 ° (ABB preliminary specification: values may change without notice.)
Axis ranges / Axis 4
±175 ° (ABB preliminary specification: values may change without notice.)
Axis ranges / Axis 5
±135 ° (ABB preliminary specification: values may change without notice.)
Axis ranges / Axis 6
±400 ° (ABB preliminary specification: values may change without notice.)
Mounting / Positions
Floor, wall, inverted, tilted 0–20° (ABB preliminary specification: values may change without notice.)
Arm / Additional load
10 kg (On the upper arm; not added to tool payload. ABB preliminary specification: values may change without notice.)
Options / Foundry Plus2
IP67 (Optional. ABB preliminary specification: values may change without notice.)
Arm / Wrist torque A4/A5
27 Nm (Reference value only. ABB preliminary specification: values may change without notice.)
Control / Safety software
Active Safety (Safety functions depend on the controller. ABB preliminary specification: values may change without notice.)
Design / Cables and hoses
Inside the arm (Integrated Dressing.)
Options / Extended safety
SafeMove2 (Availability and functions depend on the selected controller. ABB preliminary specification: values may change without notice.)
Control / Control platform
OmniCore
Electrical supply / Voltage
Controller-dependent (See the selected OmniCore specification. ABB preliminary specification: values may change without notice.)
Maximum axis speeds / Axis 1
280 °/s (ABB preliminary specification: values may change without notice.)
Maximum axis speeds / Axis 2
200 °/s (ABB preliminary specification: values may change without notice.)
Maximum axis speeds / Axis 3
250 °/s (ABB preliminary specification: values may change without notice.)
Maximum axis speeds / Axis 4
570 °/s (ABB preliminary specification: values may change without notice.)
Maximum axis speeds / Axis 5
600 °/s (ABB preliminary specification: values may change without notice.)
Maximum axis speeds / Axis 6
670 °/s (ABB preliminary specification: values may change without notice.)
Mechanical unit / Protection
IP67 (ABB preliminary specification: values may change without notice.)
Mechanical unit / Robot weight
225 kg (ABB preliminary specification: values may change without notice.)
Environment / Relative humidity
up to 95 % (ABB preliminary specification: values may change without notice.)
Control / Compatible controllers
C90XT / V250XT / V400XT (Execution selected for the application.)
Maintenance / Oil-change interval
up to 20,000 h (Stated family maximum interval; servicing requirements depend on the application.)
Mechanical unit / Base dimensions
339 × 486 mm (Two base dimensions; not overall arm dimensions. ABB preliminary specification: values may change without notice.)
Document status / Engineering data
Preliminary (3HAC100637-001 Revision A-ongoing (draft); values and dimensions may change without notice.)
Environment / Operating temperature
+5…+45 °C (ABB preliminary specification: values may change without notice.)
Environment / Storage and transport
−25…+55 °C (ABB preliminary specification: values may change without notice.)
Environment / Short-term temperature
up to +70 °C (Maximum 24 hours. ABB preliminary specification: values may change without notice.)
Motion performance / Path repeatability
0.07 mm (ISO 9283. ABB preliminary specification: values may change without notice.)
Family comparisons / Footprint reduction
50 % (ABB family comparison with its predecessor; not base dimensions.)
Working-envelope diagram / Left of centre
1586 mm (Dimension on the identified diagram; not an overall robot dimension. ABB preliminary specification: values may change without notice.)
Working-envelope diagram / Right of centre
1846 mm (Dimension on the identified diagram; not an overall robot dimension. ABB preliminary specification: values may change without notice.)
Motion performance / Position repeatability
0.05 mm (ISO 9283. ABB preliminary specification: values may change without notice.)
Working-envelope diagram / Above base plane
2226 mm (Dimension on the identified diagram; not an overall robot dimension. ABB preliminary specification: values may change without notice.)
Working-envelope diagram / Below base plane
1163.5 mm (Dimension on the identified diagram; not an overall robot dimension. ABB preliminary specification: values may change without notice.)
Family comparisons / Power-consumption reduction
up to 15 % (Compared with IRB1600 at the same payload on OmniCore; not absolute power.)
Working-envelope diagram / Inner diagram dimension
479 mm (Dimension on the identified diagram; not an overall robot dimension. ABB preliminary specification: values may change without notice.)