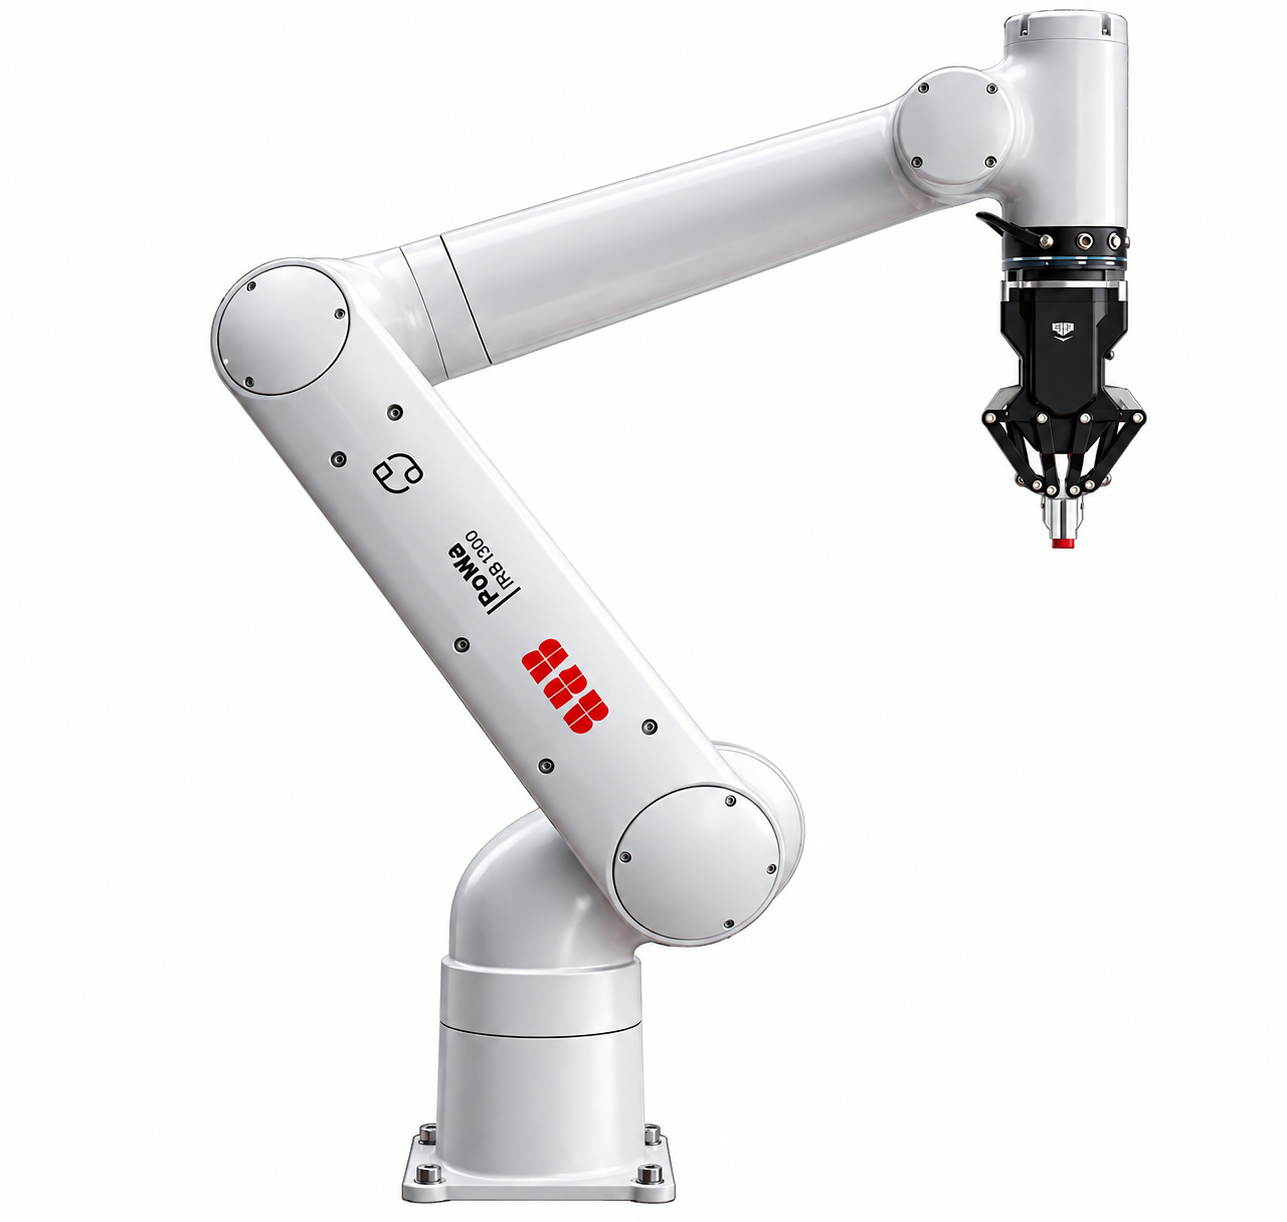
Category
Collaborative Robots and Manipulators
Tool / Torque
Up to 88 N·m (For screwdriving applications.)
Arm / Flange reach
1490 mm
Safety / Standards
ISO 10218-1; ISO 13849-1 PLd Cat 3
Arm axes / J1 range
±360 °
Arm axes / J2 range
±180 °
Arm axes / J3 range
−248…+74 °
Arm axes / J4 range
±360 °
Arm axes / J5 range
±180 ° (Default setting.)
Arm axes / J6 range
±400 °
Environment / Noise
<60 dB(A)
Arm / Base footprint
184 × 184 mm
FlexPendant / Screen
8 in (Colour touchscreen.)
Control / Programming
Wizard / AppStudio / RobotStudio
E10 controller / Mass
12 kg
Model / Robot version
CRB 1910-13/1.34
Mounting / Tool flange
ISO 9409-1-50-4-M6
Arm axes / Max J1 speed
230 °/s
Arm axes / Max J2 speed
230 °/s
Arm axes / Max J3 speed
230 °/s
Arm axes / Max J4 speed
300 °/s
Arm axes / Max J5 speed
300 °/s
Arm axes / Max J6 speed
300 °/s
Arm / Wrist-down payload
14 kg (Up to the stated value in the wrist-down configuration only.)
FlexPendant / Protection
IP65
FlexPendant / Resolution
1024 × 768 px
E10 fieldbuses / EtherCAT
Device (Supported controller network roles; supplied configuration is application-dependent.)
E10 fieldbuses / PROFINET
Controller / Device (Supported controller network roles; supplied configuration is application-dependent.)
Cables / Robot floor cable
2 / 5 / 15 m (Available lengths.)
Control / Arm-side buttons
Programmable
E10 fieldbuses / PROFIsafe
Controller / Device (Supported controller network roles; supplied configuration is application-dependent.)
Cycle / Cycle at1kg payload
1.13 s (400–900–400 path.)
E10 controller / Controller
OmniCore E10
E10 controller / Protection
IP20
E10 fieldbuses / CC-Link IE
Master / Device (Supported controller network roles; supplied configuration is application-dependent.)
Arm axes / Extended J5 range
±270 ° (Maximum setting through RobotWare configuration.)
E10 fieldbuses / EtherNet/IP
Adapter / Scanner (Supported controller network roles; supplied configuration is application-dependent.)
Mounting / Mounting position
Any angle: floor, wall, ceiling
Tool / Peripheral connection
Under 5 min (For connection of tooling through the tool interface.)
Arm load / Lower arm and elbow
Up to 7 kg (Combined additional load on the lower arm and elbow; not an increase in tool payload.)
Cleanroom / ISO 14644-1 Class4
ISO Class 4 (50% rated speed and 100% rated load.)
Cleanroom / ISO 14644-1 Class5
ISO Class 5 (100% rated speed and 100% rated load.)
Cycle / Cycle at rated payload
1.91 s (400–900–400 path.)
Cycle / Max TCP speed,1kg load
8.3 m/s (At 1 kg payload.)
E10 fieldbuses / EtherCAT FSoE
Device (Supported controller network roles; supplied configuration is application-dependent.)
Flange interfaces / C1 signals
8 DI / 6 DO / 4 AI
Flange interfaces / Tool power
24 V
Environment / Relative humidity
<95 % (At constant temperature, without condensation.)
Flange interfaces / C2 Ethernet
100 Mbit/s
Safety / SafeMove configuration
On FlexPendant
Flange interfaces / C1 protocols
Modbus RTU / RS-485
Flange interfaces / C2 protocols
Modbus TCP / TCP/IP
Commissioning / Initial operation
Up to 1 h (For the manufacturer-tested pick-and-place application.)
Cycle / Max TCP speed, rated load
5.8 m/s (At rated payload.)
Environment / Storage temperature
−40…+55 °C
Flange interfaces / Total current
4 A (With OmniCore E10 controller.)
Safety / Power and force limiting
PFL
E10 controller / FlexPendant cable
5 m
Environment / Operating temperature
+5…+45 °C
Flange interfaces / Current per pin
1.5 A (Four pins.)
E10 controller / Built-in digital IO
16 DI / 8 DO
Repeatability / Path repeatability RT
0.1 mm (According to ISO 9283.)
Repeatability / Pose repeatability RP
0.03 mm (According to ISO 9283.)
Control / Simultaneous tool connection
Camera and gripper via CPCS
Safety / Speed and separation monitoring
SSM (With safety devices.)