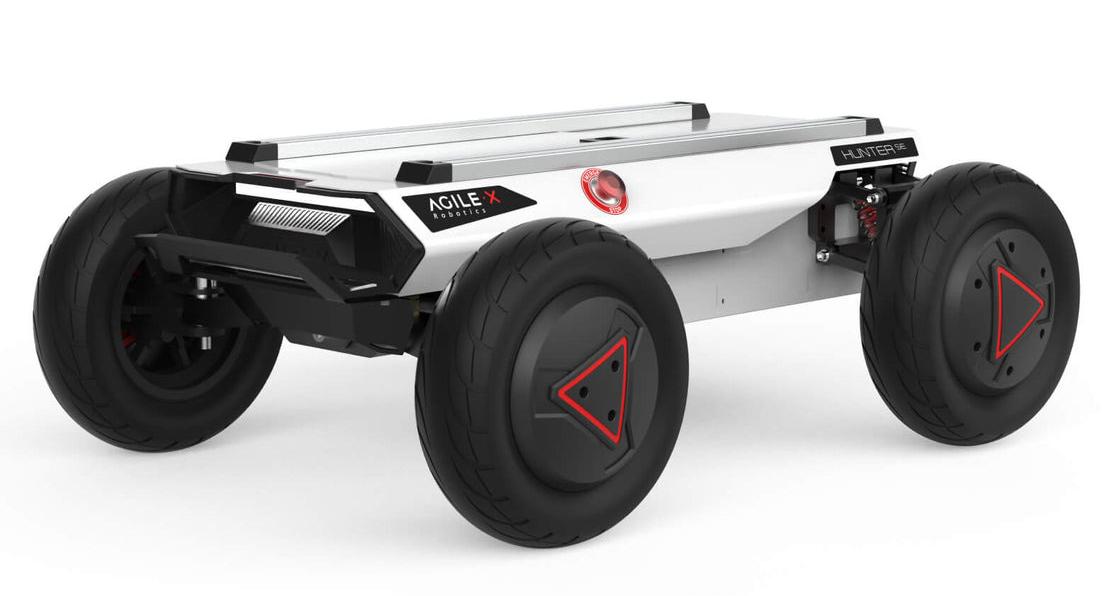
Category
Wheeled Robots and AMRs
HUNTER SE / Operation / Battery
24 V, 30 Ah
HUNTER SE / Mechanics / Steering
Ackermann
HUNTER SE / Drives / Drive motors
2 brushless wheel-hub motors×350 W
HUNTER SE / Mechanics / Wheelbase
550 mm
HUNTER SE / Control / CAN protocol
CAN 2.0B; 500 kbit/s; Motorola format
HUNTER SE / Operation / Protection
IP22
HUNTER SE / Mechanics / Kerb weight
42 kg
HUNTER SE / Mechanics / Track width
520 mm
HUNTER SE / Operation / Temperature
-10…40 °C
HUNTER SE / Operation / Charging time
3 h
HUNTER SE / Operation / Maximum range
45 km full load; 55 km no load
HUNTER SE / Operation / Maximum slope
8° full load; 15° no load
HUNTER SE / Operation / Maximum speed
4.8 m/s
HUNTER SE / Operation / Service braking
Electronic motor braking
HUNTER SE / Mechanics / Ground clearance
120 mm
HUNTER SE / Operation / Braking distance
2 m unloaded, friction coefficient 0.5
HUNTER SE / Operation / Trench clearance
100 mm full load; 150 mm no load
HUNTER SE / Operation / Battery chemistry
LiFePO4
HUNTER SE / Operation / Removable battery
Yes
HUNTER SE / Operation / Obstacle clearance
30 mm full load; 60 mm no load
HUNTER SE / Dimensions / Dimensions L×W×H
820×640×310 mm
HUNTER SE / Mechanics / Rated moving payload
50 kg
HUNTER SE / Operation / External power output
24 V, 10 A
HUNTER SE / Control and components / Suspension
Front non-independent; rear independent
HUNTER SE / Rear power and CAN connector / Pin 1
VCC: positive supply, 24.5–26.8 V, maximum10 A
HUNTER SE / Rear power and CAN connector / Pin 2
GND: negative supply
HUNTER SE / Rear power and CAN connector / Pin 3
CAN_H
HUNTER SE / Rear power and CAN connector / Pin 4
CAN_L
HUNTER SE / Control and components / Control modes
Remote control or CAN command control
HUNTER SE / Control and components / Parking brake
Power-loss electromagnetic brake
HUNTER SE / Control and components / Battery cutoff
Below24 V; with BMS connected, SOCbelow10%; external and motor power cutoff
HUNTER SE / Control and components / Drive feedback
Magnetic encoder
HUNTER SE / Control and components / Rear interface
Charging, power switch, display and CAN/24 V expansion
HUNTER SE / Control and components / Battery warning
Below24.5 V; with BMS connected, SOCbelow15%
HUNTER SE / Control and components / Emergency stops
On both sides of body
HUNTER SE / Control and components / Optional FS remote
2.4 GHz; maximum distance100m
HUNTER SE / Control and components / Remote speed levels
1.5, 3 and 4.8m/s
HUNTER SE / Control and components / Drive reduction ratio
1:4
HUNTER SE / Control and components / Maximum inner-wheel angle
22°