Category
Wheeled Robots and AMRs
Modular ALOHA / Equipment / Sensors
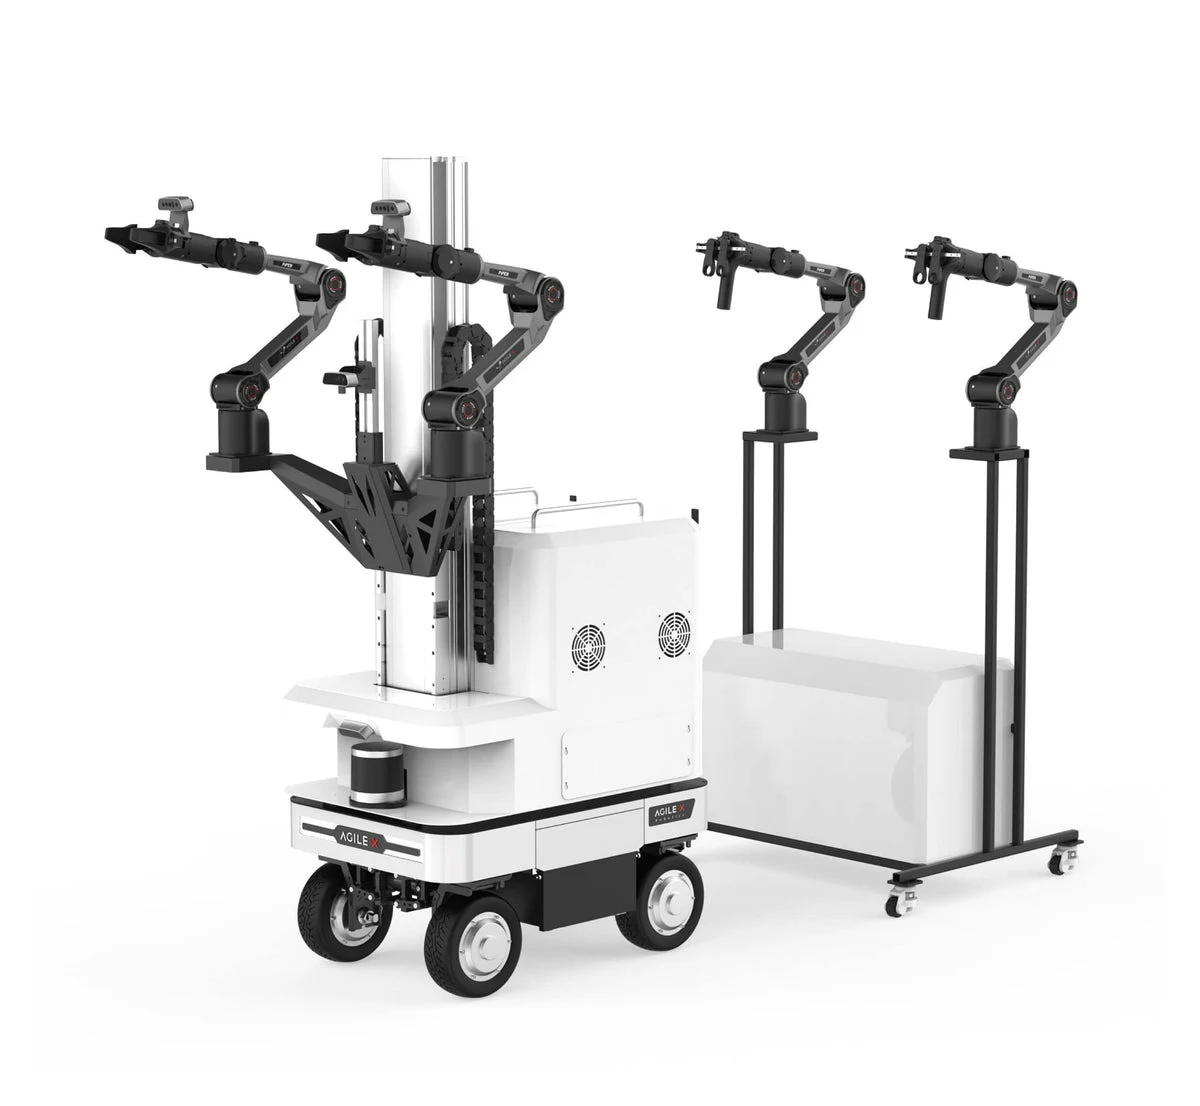
3 depth cameras and 1 LiDAR
Modular ALOHA / Equipment / Computer
Industrial PC with RTX 4060
Modular ALOHA / Equipment / System arms
4 × PiPER
Modular ALOHA / Equipment / System power
External portable power station
RANGER MINI 3.0 chassis / Chassis payload
120 kg
RANGER MINI 3.0 chassis / Chassis runtime
3 h full load; 6 h no load
Modular ALOHA / Equipment / Mobile platform
RANGER MINI 3.0
One PiPER working arm / Component / Arm DOF
6
Modular ALOHA / Equipment / Operator console
11.6-inch screen and Logitech keyboard
RANGER MINI 3.0 chassis / Chassis dimensions
720×500×345 mm
RANGER MINI 3.0 chassis / Chassis protection
IP54
One PiPER working arm / Component / Arm noise
<60 dB
RANGER MINI 3.0 chassis / Chassis temperature
-10…40 °C
Modular ALOHA / Manufacturer 2026 catalog / OS
Ubuntu 20.04 (Reference configuration; actual contents depend on the delivered execution.)
Modular ALOHA / System operation / Arm control
Split leader-follower architecture
One PiPER working arm / Component / Arm supply
DC 24 V; operating range 24–26 V
One PiPER working arm / Component / J1 / Range
±154° (Controlled-test data; varies with environment and use.)
One PiPER working arm / Component / J2 / Range
0…195° (Controlled-test data; varies with environment and use.)
One PiPER working arm / Component / J3 / Range
-175…0° (Controlled-test data; varies with environment and use.)
One PiPER working arm / Component / J4 / Range
-102…102° (Controlled-test data; varies with environment and use.)
One PiPER working arm / Component / J5 / Range
-75…75° (Controlled-test data; varies with environment and use.)
One PiPER working arm / Component / J6 / Range
±120° (Controlled-test data; varies with environment and use.)
Modular ALOHA / Manufacturer 2026 catalog / ROS
ROS 1 Noetic; ROS 2 Humble optional (Reference configuration; actual contents depend on the delivered execution.)
RANGER MINI 3.0 chassis / Maximum chassis speed
2 m/s
Modular ALOHA / System geometry / Dual-arm width
757.7 mm
Modular ALOHA / System geometry / Maximum height
1891.6 mm
Modular ALOHA / System geometry / Minimum height
1322.4 mm
One PiPER working arm / Component / Arm humidity
25–85%, non-condensing
Modular ALOHA / Manual v1.0.1 2025 / Port binding
Arm/chassis USB and LiDAR Ethernet connections are device-bound (Documented manual execution dated 4 June 2025.)
One PiPER working arm / Component / Arm materials
Aluminum alloy frame and plastic casing
One PiPER working arm / Mechanics / Tool mounting
M3×14 screws
Modular ALOHA / System operation / Data collection
Teleoperation and recording real-world demonstrations
One PiPER working arm / Component / Arm controller
Integrated
One PiPER working arm / Component / One-arm weight
4.2 kg (For one follower PiPER arm; allowed load depends on workspace according to the1/1.5 kg curves.)
Modular ALOHA / System operation / Lift development
ROS drivers for the lift
One PiPER working arm / Component / Arm temperature
-20…50°C
One PiPER working arm / Component / One-arm payload
1.5 kg (For one follower PiPER arm; allowed load depends on workspace according to the1/1.5 kg curves.)
Modular ALOHA / Manual v1.0.1 2025 / Module charging
Lower and upper modules are charged separately with matching chargers (Documented manual execution dated 4 June 2025.)
Modular ALOHA / System operation / Power architecture
External power station and redundant battery system
One PiPER working arm / Component / Arm base mounting
70×70 mm; 4 M5 threads
One PiPER working arm / Component / Arm communication
CAN
One PiPER working arm / Component / Arm repeatability
±0.1 mm (For one follower PiPER arm; allowed load depends on workspace according to the1/1.5 kg curves.)
Modular ALOHA / Manual v1.0.1 2025 / Controls Q2/Q3/Q5
Q2: chassis emergency stop; Q3: chassis, navigation and lift power; Q5: PC and two follower-arm power (Documented manual execution dated 4 June 2025.)
Modular ALOHA / Manufacturer 2026 catalog / Simulation
Gazebo, Isaac Sim, MuJoCo (Reference configuration; actual contents depend on the delivered execution.)
Modular ALOHA / System operation / Research frameworks
Mobile ALOHA, ACT and other open robot-learning approaches
One PiPER working arm / Component / Arm working radius
626.75 mm
One PiPER working arm / Component / J1 / Maximum speed
180°/s (Joint angular speed.)
One PiPER working arm / Component / J2 / Maximum speed
195°/s (Joint angular speed.)
One PiPER working arm / Component / J3 / Maximum speed
180°/s (Joint angular speed.)
One PiPER working arm / Component / J4 / Maximum speed
225°/s (Joint angular speed.)
One PiPER working arm / Component / J5 / Maximum speed
225°/s (Joint angular speed.)
One PiPER working arm / Component / J6 / Maximum speed
225°/s (Joint angular speed.)
One PiPER working arm / Component / Workspace and load
Separate 1 and 1.5 kg curves; 1.5 kg is not specified throughout the full maximum-radius workspace
Modular ALOHA / Manual v1.0.1 2025 / Display connection
HDMI or DisplayPort directly to GPU (Documented manual execution dated 4 June 2025.)
Modular ALOHA / System geometry / Mobile platform width
774.6 mm
Modular ALOHA / System operation / Automatic recharging
Operation with a charging station and navigation-based route planning
One PiPER working arm / Component / Arm control methods
Drag teaching, offline trajectory, API and host PC
One PiPER working arm / Mechanics / End flange mounting
6 M3×8 countersunk screws; M3×4 limit screw with 4.5 mm head
Modular ALOHA / Manufacturer 2026 catalog / Model support
Upgradable to PI0, PI0.5, LeRobot, RDT (Reference configuration; actual contents depend on the delivered execution.)
One PiPER working arm / Component / Arm power consumption
Maximum ≤120 W; average ≤40 W
Modular ALOHA / Manual v1.0.1 2025 / Navigation executions
Open-source navigation or NAVIS; navigation package optional (Documented manual execution dated 4 June 2025.)
Modular ALOHA / System operation / Working assembly height
Adjustable by lifting mechanism
One PiPER working arm / Component / Arm external interfaces
1 power interface and 1 CAN interface
Modular ALOHA / Communication / Console-to-mobile connection
CAN cable by default
Modular ALOHA / Manual v1.0.1 2025 / Rear connectors Q1/Q4/Q6
Q1: chassis external power and communications; Q4: chassis charging; Q6: upper battery charging (Documented manual execution dated 4 June 2025.)
Modular ALOHA / Manufacturer 2026 catalog / Algorithms and SDK
Sample algorithms and SDK (Reference configuration; actual contents depend on the delivered execution.)
One PiPER working arm / Mechanics / Kinematic-diagram segments
112.7; 285.03; 250.65; 91 mm
One PiPER working arm / Component / Power/CAN connector signals
Power positive, negative, CAN-H, CAN-L
Modular ALOHA / Manufacturer 2026 catalog / Working-arm grippers
2 (Reference configuration; actual contents depend on the delivered execution.)
Modular ALOHA / Manual v1.0.1 2025 / RTX 4060 training limitation
RTX 4060 is primarily recommended for inference; model training may run out of VRAM (Documented manual execution dated 4 June 2025.)
Modular ALOHA / Manufacturer 2026 catalog / Leader teaching devices
2 (Reference configuration; actual contents depend on the delivered execution.)