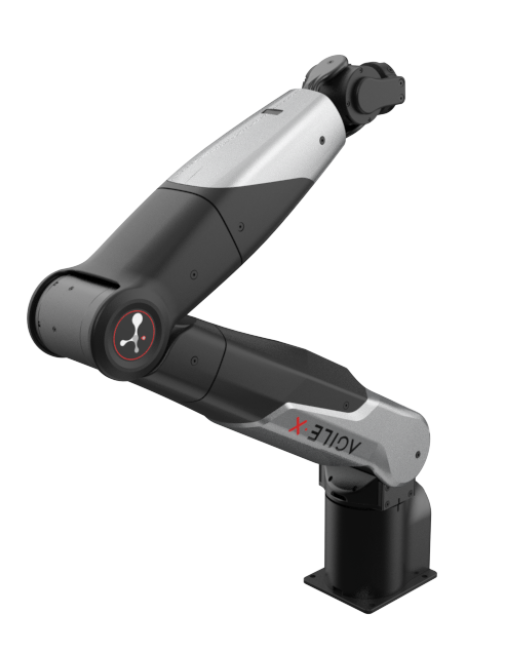
Category
Collaborative Robots and Manipulators
Arm / Frame
Aluminum alloy
Arm / Noise
<60 dB (Measurement distance and operating mode unspecified)
Arm / Control
Drag teaching, offline trajectory, API, host computer
Arm / Payload
3 kg (Per arm, accounting for fitted tooling)
Arm / Arm mass
4.8 kg (Included tooling unspecified)
Arm / Humidity
25–85 % (Non-condensing)
Arm / Mounting
Table, side, inverted
Arm / Controller
Integrated
Arm / Protection
IP22 (Standard version without customized protection)
Arm / Base mounting
70 ×70 mm; M5 ×4
Arm / Communication
CAN / HTTP / TCP
Arm / Repeatability
±0.1 mm (Load and measurement procedure unspecified)
Arm / Nominal supply
24 V DC
Arm / Degrees of freedom
7
Arm / Comprehensive power
≤60 W (Duty cycle unspecified)
Arm / Computer connection
Wi-Fi / Ethernet (Wireless hotspot control and wired control; manual sections 4 and 7.2)
Arm / End-effector output
XT30 2+2; 24 V; ≤2 A (End-effector CAN supports AgileX devices only)
Arm / External connectors
Power ×1; CAN ×1; Ethernet ×1
Arm / Manual working radius
58 cm (Manual specification; mounting and pose affect usable workspace)
Arm / Operating temperature
-20–50 °C
Joint motion / J1 motion range
-157–157 °
Joint motion / J2 motion range
-15–190 °
Joint motion / J3 motion range
-160–160 °
Joint motion / J4 motion range
-60–125 °
Joint motion / J5 motion range
-160–160 °
Joint motion / J6 motion range
-43–58 °
Joint motion / J7 motion range
-90–90 ° (Manual dated 2026-10-14; product page specifies ±97°)
Arm / Maximum power consumption
≤150 W
Joint motion / J1 maximum speed
180 °/s (Manufacturer controlled test environment)
Joint motion / J2 maximum speed
180 °/s (Manufacturer controlled test environment)
Joint motion / J3 maximum speed
180 °/s (Manufacturer controlled test environment)
Joint motion / J4 maximum speed
225 °/s (Manufacturer controlled test environment)
Joint motion / J5 maximum speed
225 °/s (Manufacturer controlled test environment)
Joint motion / J6 maximum speed
225 °/s (Manufacturer controlled test environment)
Joint motion / J7 maximum speed
225 °/s (Manufacturer controlled test environment)
Arm / Obstacle-avoidance sensors
Not included
Joint motion / Product-page J7 range
±97 ° (Manual specifies ±90°; limit for supplied version requires clarification)
Software and configuration / Pose control
Joint and linear
Software and configuration / End effectors
Selected separately
Software and configuration / Simulation tools
URDF / MoveIt 2 / Gazebo / Isaac Sim / Isaac Lab
Software and configuration / Software support
Python SDK / ROS1 / ROS2
Software and configuration / Tool compensation
Mass, center of gravity and geometry (After configuration of fitted end-effector parameters)