Category
Realistic Androids
Hardware and operation / Body
40 DoF (Within N2H)
Hardware and operation / Head
22 DoF (Within N2H; not the standalone Robot Head)
Hardware and operation / Weight
approx. 65 kg (Manufacturer example; assembly/battery scope not stated)
Hardware and operation / Cameras
Both eyes (Camera type, resolution and component models not specified)
Hardware and operation / Speaker
In the neck
Hardware and operation / Actuation
Pneumatic
Hardware and operation / Appearance
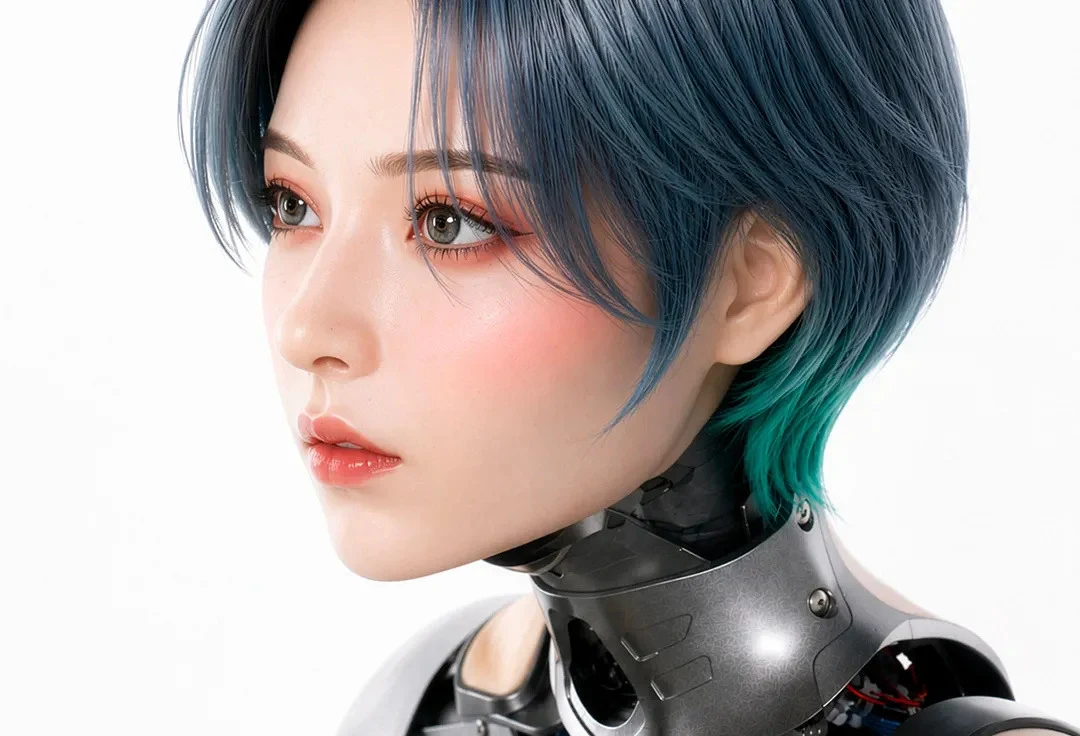
Person or character (Hair, eyes, teeth and skin; selected identity subject to configuration)
Hardware and operation / Applications
R&D, guidance, reception (Manufacturer-described applications)
Hardware and operation / Conversation
Autonomous (AVITA OS; language list and recognition metrics not specified)
Hardware and operation / Power supply
100-240 V AC
Hardware and operation / Skin material
Silicone (Proprietary skin; durability and flexibility claimed without quantified tests)
Hardware and operation / Head movements
upper eyelid opening/closing, horizontal eye movement, vertical eye movement, lower eyelid opening/closing, outer eyebrow raise, inner eyebrow raise, brow furrow, cheek pull, lip corner pull, lip corner lowering, lip pursing, upper/lower lip movement, tongue raise, head tilt, neck rotation, neck flexion/extension (Manufacturer motion list; independent walking not established)
Hardware and operation / Remote operation
Smartphone / computer (AVITA OS applications; network requirements and latency not specified)
Hardware and operation / Software updates
Over the internet (After hardware purchase; support term and update policy not specified)
Hardware and operation / Power consumption
150 W (Measurement conditions not specified)
Hardware and operation / Software platform
AVITA OS (Installable on N2H; supplied scope to be agreed)
Hardware and operation / Degrees of freedom
62+ DoF (Published minimum; head 22, body 40)
Hardware and operation / Dimensions, W×D×H
60 × 60 × 178 cm (Manufacturer example, not universal dimensions)
Hardware and operation / Lower-body movements
waist rotation, leg lateral movement, thigh flexion/extension, knee flexion/extension, ankle flexion/extension (Manufacturer motion list; independent walking not established)
Hardware and operation / System customisation
Supported (Application-specific extension; API/SDK list not published)
Hardware and operation / Upper-body movements
scapular elevation/depression, scapular protraction/retraction, arm forward/backward movement, shoulder abduction/adduction, upper arm rotation, elbow flexion/extension, forearm rotation, wrist flexion/extension, wrist lateral movement, five-finger opening/closing, thumb flexion/extension, torso lateral flexion, torso flexion/extension (Manufacturer motion list; independent walking not established)