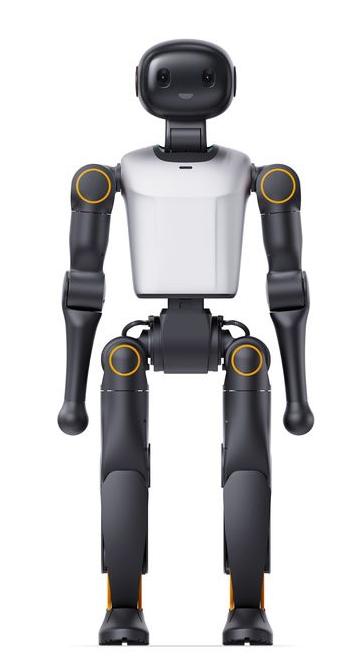
Network connections / Wi-Fi
Wi-Fi 6
Network connections / Ethernet
Gigabit Ethernet (One port per controller)
Network connections / Bluetooth
5.2
Construction and equipment / Audio
Microphones / speaker
Equipment and conditions / Speaker
1 unit
Construction and equipment / Weight
≈19.5 kg
Equipment and conditions / Indicator
1 × RGB LED
Construction and equipment / Head DoF
2 DoF
Construction and equipment / Humidity
5...90 % (Non-condensing)
Computing configurations / Geek memory
8 GB (Geek)
Equipment and conditions / Microphones
Array
Computing configurations / Geek storage
128 GB (Geek)
Construction and equipment / Connection
Wi-Fi 6 /Bluetooth 5.2
Equipment and conditions / Power button
1 unit
Joint limits in manual / Head Yaw Joint
-59...59 ° (ID 0; K1)
Computing configurations / Education CPU
6 × Cortex-A78AE @2 GHz (Education)
Construction and equipment / DoF per arm
4 DoF
Construction and equipment / DoF per leg
6 DoF
Equipment and conditions / Turning speed
1.5 rad/s
Equipment and conditions / Walking noise
≤70 dB (Measurement distance unspecified)
Joint limits in manual / Left Knee Joint
0...133 ° (ID 13; K1)
Computing configurations / Geek CPU cores
1 × GoldP@3.2 GHz / 4 × Gold@2.8 GHz / 3 × Silver@2.0 GHz (Geek)
Computing configurations / Geek processor
High-performance ARM (Geek)
Construction and equipment / Geek battery
2 Ah
Joint limits in manual / Head Pitch Joint
-19...49 ° (ID 1; K1)
Joint limits in manual / Left Elbow Joint
-129...39 ° (ID 5; K1)
Joint limits in manual / Right Knee Joint
0...133 ° (ID 19; K1)
Construction and equipment / Charging time
≤120 min
Equipment and conditions / Auditory alerts
Low battery / joint overheat
Joint limits in manual / Right Elbow Joint
-39...129 ° (ID 9; K1)
Computing configurations / Education memory
8 GB (Education)
Computing configurations / Professional CPU
8 × Cortex-A78AE @2.2 GHz (Professional)
Construction and equipment / Geek computing
48 TOPS (Dense;Geek)
Equipment and conditions / Camera in manual
Depth camera (Geek / Education / Professional)
Joint limits in manual / Left Hip Yaw Joint
-59...59 ° (ID 12; K1)
Computing configurations / Education storage
512 GB (Education)
Construction and equipment / Standing height
95 cm
Joint limits in manual / Left Ankle Up Joint
-17...38 ° (ID 14; K1)
Joint limits in manual / Left Hip Roll Joint
-22...89 ° (ID 11; K1)
Joint limits in manual / Right Hip Yaw Joint
-59...59 ° (ID 18; K1)
Equipment and conditions / Battery cycle life
≥500 cycles
Joint limits in manual / Left Hip Pitch Joint
-170...128 ° (ID 10; K1)
Joint limits in manual / Right Ankle Up Joint
-17...38 ° (ID 20; K1)
Joint limits in manual / Right Hip Roll Joint
-89...22 ° (ID 17; K1)
Computing configurations / Education processor
Jetson Orin NX 8GB (Education)
Computing configurations / Professional memory
32 GB (Professional)
Equipment and conditions / Interaction buttons
3 units
Joint limits in manual / Left Ankle Down Joint
-16...41 ° (ID 15; K1)
Joint limits in manual / Right Hip Pitch Joint
-170...128 ° (ID 16; K1)
Computing configurations / Professional storage
512 GB (Professional)
Construction and equipment / Degrees of freedom
22 DoF
Joint limits in manual / Right Ankle Down Joint
-16...41 ° (ID 21; K1)
Construction and equipment / Ambient temperature
-10...45 °C
Construction and equipment / Education computing
117 TOPS
Construction and equipment / Education processor
Jetson Orin NX 8GB
Joint limits in manual / Left Shoulder Yaw Joint
-109...109 ° (ID 4; K1)
Computing configurations / Professional processor
Jetson AGX Orin 32GB (Professional)
Construction and equipment / Geek walking runtime
20 min (Walking at1.1m/s;Geek2Ah)
Joint limits in manual / Left Shoulder Roll Joint
-94...94 ° (ID 3; K1)
Joint limits in manual / Right Shoulder Yaw Joint
-109...109 ° (ID 8; K1)
Equipment and conditions / Certification standards
CE / FCC
Joint limits in manual / Left Shoulder Pitch Joint
-169...69 ° (ID 2; K1)
Joint limits in manual / Right Shoulder Roll Joint
-94...94 ° (ID 7; K1)
Construction and equipment / Professional computing
200 TOPS
Construction and equipment / Professional processor
Jetson AGX Orin 32GB
Joint limits in manual / Right Shoulder Pitch Joint
-169...69 ° (ID 6; K1)
Construction and equipment / Education/Professional battery
5 Ah
Construction and equipment / Education/Professional walking runtime
70 min (Walking at1.1m/s;5Ah)