Category
Industrial Robots
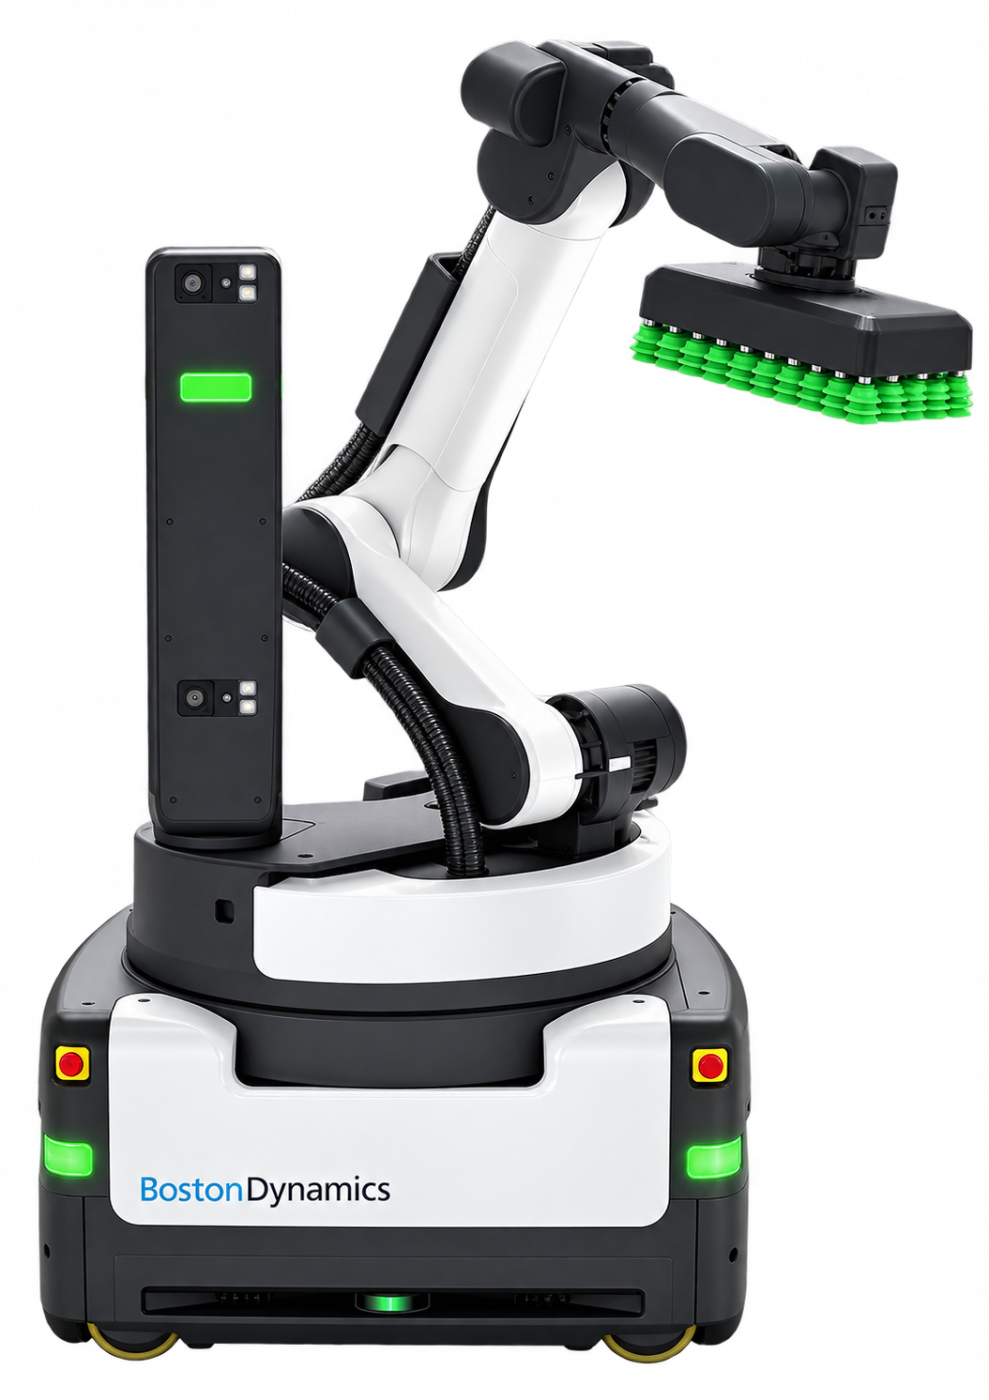
Trailer unloading / Gripper
Vacuum gripper with sensing and pneumatic control
Trailer unloading / Arm axes
7 (Unloading arm; not total mobile-platform degrees of freedom.)
Trailer unloading / Footprint
100 ×125 cm (Base footprint; total height is not stated.)
Trailer unloading / Multipick
Multiple cases per arm swing (Boxes are spaced on the conveyor for downstream sortation.)
Trailer unloading / Label Sense
Places boxes with labels facing the same direction (For downstream scanning in a compatible sortation system.)
Trailer unloading / Robot weight
1300 kg (Unloading configuration; the weighed assembly is not specified.)
Trailer unloading / Task startup
Step-by-step console wizard
Trailer unloading / EU conformity
2006/42/EC;2014/30/EU;2014/53/EU (Manufacturer declaration for the described configuration.)
Trailer unloading / Charging to90%
105 min (With Fast Charger; initial state of charge is not stated.)
Trailer unloading / Vertical reach
3200 mm
Trailer unloading / Horizontal reach
1950 mm
Trailer unloading / Trailer lighting
Onboard camera lighting (External lighting is not required for its vision system.)
Trailer unloading / Vision processing
Real-time perception decisions
Trailer unloading / Eligible case type
Rectangular cardboard boxes with taped or glued flaps (Most common packaging wear and tear is acceptable.)
Trailer unloading / Battery life, up to
960 min (For unloading; test payload and duty cycle are unspecified.)
Trailer unloading / Compatible conveyor
Telescopic (Models from different manufacturers; system compatibility must be established.)
Trailer unloading / Compatible trailers
Enclosed cargo and curtainsider trailers
Trailer unloading / Maximum case weight
23 kg
Trailer unloading / Positioning control
Handheld pendant (For placing the robot at its work position.)
Trailer unloading / Unloading case rate
600–800 cases/h (Actual throughput depends on container and case configuration.)
Trailer unloading / Fallen-case recovery
Automatic (During trailer unloading.)
Trailer unloading / Box recognition setup
Pre-trained model (No pre-operational programming of box types and sizes is required.)
Trailer unloading / Compatible containers
20/40-foot standard and high-cube containers
Trailer unloading / Operating temperature
5…45 °C
Trailer unloading / Case surface dimension
15…91 cm (Minimum length of any surface15cm; maximum91cm.)
Trailer unloading / Conveyor communication
Wireless (Coordinates conveyor extension and retraction; radio protocol is unspecified.)
Trailer unloading / External utility lines
No tethered power or air lines required
Trailer unloading / Multi-robot supervision
From one console