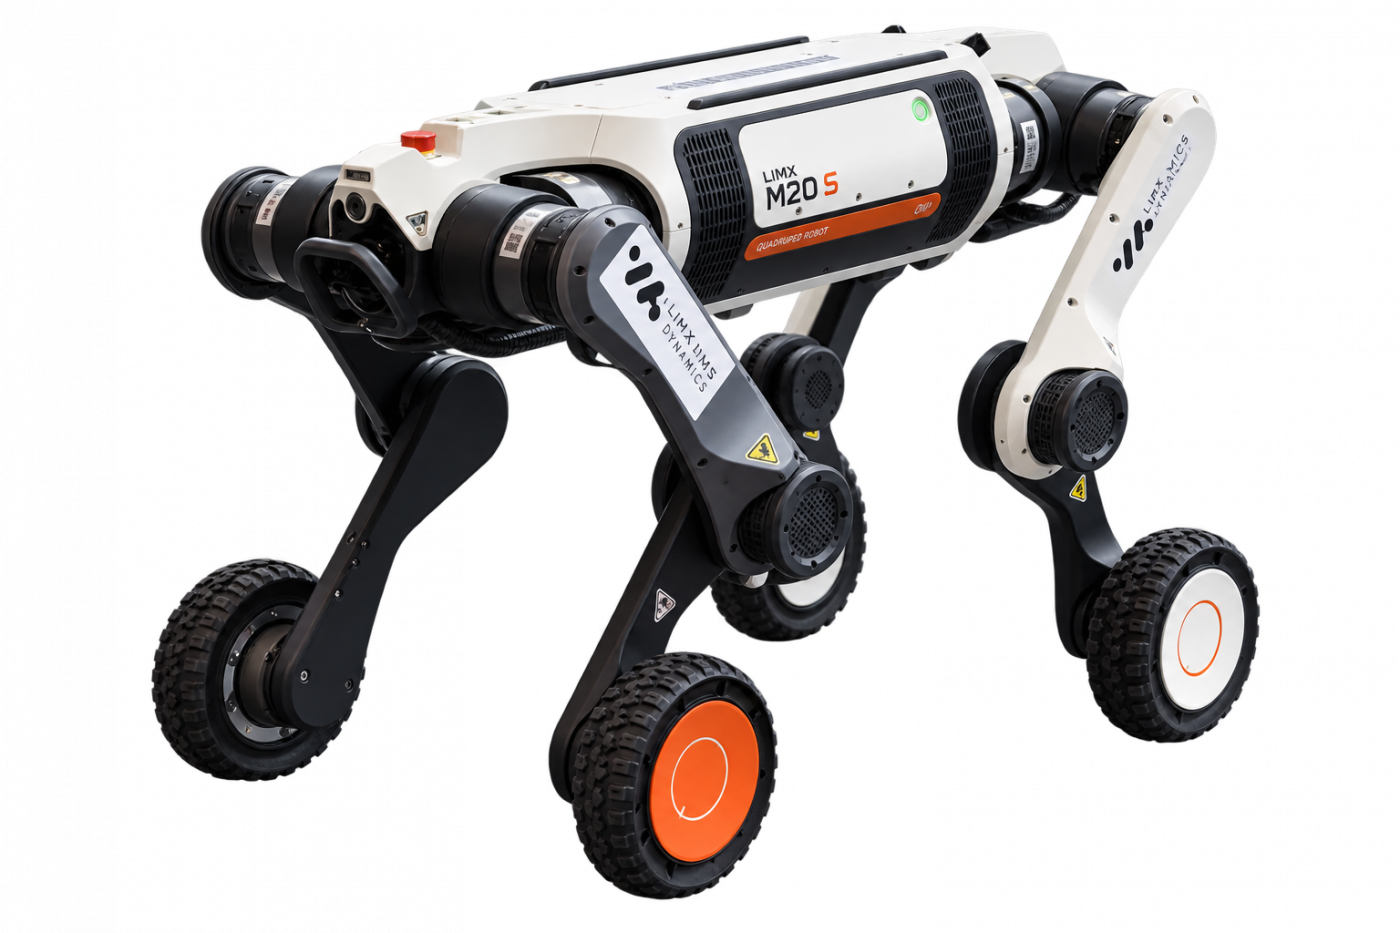
Category
Wheeled Robots and AMRs
72 V output / Pinout / Pin 1
GND; black.
72 V output / Pinout / Pin 2
-; unassigned.
72 V output / Pinout / Pin 3
-; unassigned.
72 V output / Pinout / Pin 4
VCC; red.
M20S V1.0.6 connectors / USB
① USB3.0
M20S sensor coordinates / IMU
X=60.8, Y=-32.8, Z=-40.65 mm relative to the body frame.
M20S link geometry / Offset L1
≈ 0.104m
Mechanics / Degrees of freedom
16;4 motors in each of 4 legs.
24 V + Ethernet / Pinout / Pin 1
GND; black.
24 V + Ethernet / Pinout / Pin 2
24 V; red.
24 V + Ethernet / Pinout / Pin 3
TX+; orange/white.
24 V + Ethernet / Pinout / Pin 4
TX-; orange.
24 V + Ethernet / Pinout / Pin 5
RX+; green/white.
24 V + Ethernet / Pinout / Pin 6
TX2+; blue.
24 V + Ethernet / Pinout / Pin 7
TX2-; blue/white.
24 V + Ethernet / Pinout / Pin 8
RX2-; brown.
24 V + Ethernet / Pinout / Pin 9
GND; light green.
M20S link geometry / Wheel width
≈ 0.05m
24 V + Ethernet / Pinout / Pin 10
24 V; pink.
24 V + Ethernet / Pinout / Pin 11
RX-; green.
24 V + Ethernet / Pinout / Pin 12
RX2+; white/brown.
LYNX M20S / Operation / USB power
5 V
24 V + PPS + SBUS / Pinout / Pin 1
GND; black.
24 V + PPS + SBUS / Pinout / Pin 2
24 V; red.
24 V + PPS + SBUS / Pinout / Pin 3
TX+; orange/white.
24 V + PPS + SBUS / Pinout / Pin 4
TX-; orange.
24 V + PPS + SBUS / Pinout / Pin 5
RX+; green/white.
24 V + PPS + SBUS / Pinout / Pin 6
1PPS-OUT; blue.
24 V + PPS + SBUS / Pinout / Pin 7
RMC-OUT; blue/white.
24 V + PPS + SBUS / Pinout / Pin 8
SBUS-RX; brown.
24 V + PPS + SBUS / Pinout / Pin 9
GND; light green.
LYNX M20S / Operation / Basic gait
Limited to 2 m/s; regular structured terrain.
LYNX M20S / Operation / Stair gait
For stairs, not intended for flat-floor travel.
LYNX M20S / Operation / Wheel size
7 in
24 V + PPS + SBUS / Pinout / Pin 10
24 V; pink.
24 V + PPS + SBUS / Pinout / Pin 11
RX-; green.
24 V + PPS + SBUS / Pinout / Pin 12
SBUS-TX; brown/white.
M20S link geometry / Foot offset L5
≈ 0.073m
M20S link geometry / Knee offset L3
≈ 0.029m
M20S link geometry / Wheel diameter
≈ 0.18m
LYNX M20S / Specifications / Mapping
SLAM mapping and localization.
LYNX M20S / Specifications / Updates
OTA
M20S link geometry / Shank length L4
≈ 0.25m
M20S link geometry / Thigh length L2
≈ 0.25m
M20S sensor coordinates / Rear LiDAR
X=-320.28, Y=0, Z=-13 mm relative to the body frame.
LYNX M20S / Operation / Control modes
Manual, perception-assisted and autonomous navigation modes.
M20S link geometry / Body width Wbody
≈ 0.506m
M20S sensor coordinates / Front LiDAR
X=320.28, Y=0, Z=-13 mm relative to the body frame.
V1.0.6 contents / Manual packing list
Robot without batteries×1; controller×1; swappable battery×2; intelligent charger×1; transport case×1.
LYNX M20S / Operation / High-step gait
For a single obstacle below100 cm; not intended for stairs.
LYNX M20S / Specifications / Batteries
Hot-swappable dual battery system.
LYNX M20S / Specifications / Computers
3×octa-core 64-bit industrial processors; each 16 GB RAM and128 GB storage.
M20S link geometry / Body length Lbody
≈ 0.82m
LYNX M20S / Operation / Charger / Input
100–240 V
LYNX M20S / Specifications / Navigation
Autonomous navigation and omnidirectional obstacle avoidance.
V1.0.6 contents / Documents and harness
Warranty card, leaflet, certificate and wiring-harness kit:1 each.
LYNX M20S / Operation / Charger / Output
84 V,3 A per channel.
LYNX M20S / Specifications / LiDAR units
2 units;128 channels,360°×95° field of view, approximately 1152000 points/s.
LYNX M20S / Specifications / Single step
Up to 100 cm
M20S V1.0.6 connectors / Power connector
⑦72 V,5 A.
LYNX M20S / Operation / Status monitoring
Motor and driver temperatures, joint parameters, CPU, battery, motion and attitude status.
LYNX M20S / Specifications / Loaded range
12–15 km
LYNX M20S / Specifications / Stair height
Up to 30 cm
M20S V1.0.6 connectors / Gigabit Ethernet
⑥ Gigabit Ethernet
LYNX M20S / Operation / Battery monitoring
The controller displays front and rear battery charge separately.
LYNX M20S / Specifications / Maximum slope
45°; laboratory data, performance depends on surface material.
LYNX M20S / Operation / Wireless connection
Wi-Fi
LYNX M20S / Specifications / Loaded runtime
2.5–3.5 h
LYNX M20S / Specifications / Unloaded range
16–20 km
LYNX M20S / Specifications / Extreme payload
100 kg; extreme capacity, distinct from 35 kg effective payload.
M20S mounting and expansion / Mounting holes
14 M4 holes on two mounting rails.
LYNX M20S / Operation / Simultaneous charging
The charger supports two batteries simultaneously;1.5 h per battery.
LYNX M20S / Specifications / Unloaded runtime
3.5–5 h
M20S mounting and expansion / Cable clearance
At least 10 mm above the rail top at the cable outlet.
M20S link geometry / Fore-aft hip spacing Lhip
≈ 0.625m
LYNX M20S / Operation / Battery nominal voltage
72 V
LYNX M20S / Operation / Lighting and indication
Front and rear light strips indicate direction, operating modes, charging, warnings and protection states.
LYNX M20S / Operation / Single battery capacity
4.5 Ah; ideal measurement for one battery at 25 °C.
LYNX M20S / Specifications / General interfaces
24/72 V power, Gigabit Ethernet, USB3.0.
LYNX M20S / Specifications / Image transmission
RF link
LYNX M20S / Specifications / Wide-angle cameras
2 units
LYNX M20S / Operation / Prone dimensions L×W×H
820×600×185 mm
LYNX M20S / Specifications / Autonomous charging
Optional
M20S V1.0.6 connectors / Power and Fast Ethernet
⑤24 V,3 A and100 Mbps Ethernet.
M20S link geometry / Left-right hip spacing Whip
≈ 0.137m
M20S sensor coordinates / Rear wide-angle camera
X=-376.46, Y=0, Z=37.38 mm relative to the body frame.
M20S sensor coordinates / Front wide-angle camera
X=376.46, Y=0, Z=37.38 mm relative to the body frame.
LYNX M20S / Specifications / Operating temperature
-30…55 °C
LYNX M20S / Specifications / Weight with batteries
Approximately36 kg
M20S mounting and expansion / Leg motion clearance
In extreme poses, joints can rise above the body; payload mounting must preserve clearance from the legs.
LYNX M20S / Specifications / Laboratory speed limit
9 m/s; extreme laboratory test, unavailable to users; software safety limit3 m/s.
M20S V1.0.6 connectors / Power and Gigabit Ethernet
②③④: each 24 V,3 A and Gigabit Ethernet.
LYNX M20S / Specifications / Maximum operating speed
2 m/s
LYNX M20S / Specifications / Single battery charging
1.5 h
M20S mounting and expansion / External power maximum
72 V:360 W total;24 V:250 W total.
M20S mounting and expansion / Actual72 V output range
56–84 V
LYNX M20S / Specifications / Standing dimensions L×W×H
820×430×570 mm
M20S mounting and expansion / Payload installation limits
No more than 35 kg; recommended height up to 30 cm, within the illustrated mounting area.
LYNX M20S / Specifications / Effective payload on standard terrain
35 kg