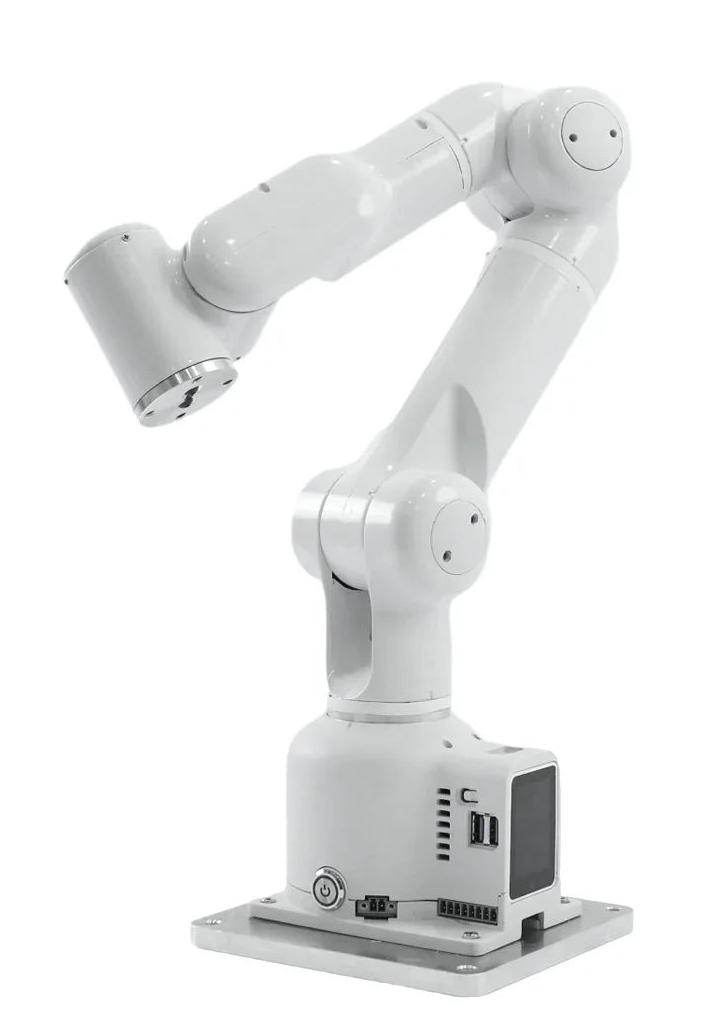
Category
Collaborative Robots and Manipulators
Robot / Main CPU
Quad-core ARM Cortex-A72 ARMv8 64-bit, 1.5 GHz.
Joint limits / J1
-165…165°; maximum speed150°/s, acceleration200°/s².
Joint limits / J2
-50…120°; maximum speed150°/s, acceleration200°/s².
Joint limits / J3
-165…165°; maximum speed150°/s, acceleration200°/s².
Joint limits / J4
-165…1°; maximum speed150°/s, acceleration200°/s².
Joint limits / J5
-165…165°; maximum speed150°/s, acceleration200°/s².
Joint limits / J6
-75…255°; maximum speed150°/s, acceleration200°/s².
Joint limits / J7
-165…165°; maximum speed150°/s, acceleration200°/s².
Robot / Materials
Carbon fibre, aluminium alloy and engineering plastics.
Robot / Interfaces
CAN, Wi-Fi, Ethernet, Bluetooth, USB and serial port.
Robot / Digital I/O
24 V:6 inputs and 6 outputs.
Robot / Joint brake
Electromagnetic friction plate.
CM4 controller / USB
USB3.2, ASM3042 high-speed PCIe bridge.
Robot / Product size
98×128×640 mm
Base I/O / Base inputs
6digital inputs, NPN only; 24 V supply.
CM4 controller / Wi-Fi
2.4/5.0 GHz, IEEE802.11b/g/n/ac.
Robot / Emergency stop
STOP connector for an external emergency-stop loop; the loop must be connected and closed during operation.
Robot / Working radius
450 mm
Tool flange / Tool I/O
1 PNP input and 2 PNP outputs; 24 V DC supply.
Base I/O / Base outputs
6digital outputs, PNP only; DC24 V and GND.
Robot / Arm power input
24 V DC, 9.2 A.
Robot / Base connectors
2×USB3.2, Micro-HDMI, UART, I²C, USB2.0 with OTG, development USB-C, DC24 V input and Ethernet.
Robot / Main controller
M5-CM4STACK, M5Stack CM4 4 GB.
Robot / Maximum payload
1 kg; single-arm payload.
CM4 controller / Display
2.0-inch IPS-LCD capacitive touchscreen; ST7789V2.
CM4 controller / Speaker
2 W, AW88298 driver.
Robot / Operating supply
24 V DC
Tool pinout / M8 / 1 GND
DC24 V negative; white wire.
Tool pinout / M8 / 6 IN1
Input 1; pink.
Tool pinout / M8 / 7 IN2
Unavailable; blue.
CM4 controller / Ethernet
RJ45 Gigabit Ethernet, 1 Gbps.
Robot / Arm repeatability
±0.05 mm
Tool pinout / M8 / 2 OUT1
Output 1; brown.
Tool pinout / M8 / 3 OUT2
Output 2; green.
Tool pinout / M8 / 5 24 V
DC24 V positive; grey.
Tool pinout / M8 / 8 485B
Reserved, undeveloped; purple.
Robot / Degrees of freedom
7
Tool pinout / M8 / 4 485 A
Reserved, undeveloped; yellow.
Atom / Auxiliary controller
ESP32, dual-core 240 MHz, 600 DMIPS, 520 KB SRAM; Wi-Fi and dual-mode Bluetooth; 4 MB flash.5×5 RGB LED matrix.
CM4 controller / CM4 module
CM4104032; Broadcom BCM2711, quad-core 64-bit Cortex-A72 at 1.5 GHz; 4 GB RAM and 32 GB eMMC.
Pico / Auxiliary controller
ESP32, dual-core 240 MHz, 600 DMIPS, 520 KB SRAM; Wi-Fi and dual-mode Bluetooth; 4 MB flash.
Robot / Reduction mechanism
Harmonic reducer.
CM4 controller / Video output
HDMI 4K/60p
Drawing geometry / Base holes
4through holes Ø4.5 mm, 80×112 mm pitch.
Tool flange / Tool interfaces
Round8-pin M8 I/O and 4-pin USB for an external camera.
Robot / Specified service life
5000 h.
Drawing geometry / Corner radii
Base4×R5; mounting plate4×R10.
Drawing geometry / Base fasteners
4M4×10 hex-socket screws.
Drawing geometry / Mounting plate
190×150 mm, 8 mm thick.
Drawing geometry / Height in drawing
653.9 mm in the illustrated extended pose.
Drawing geometry / Workspace drawing
Outer circle Ø936 mm, inner circle Ø184 mm; side view shows184 mm offset.
Options / Tools and vision / Options
Optional grippers, suction pumps and 2D/3D machine-vision systems.
Programming / Motion and development
Supports free movement, joint and Cartesian commands, path recording, wireless control and emergency stop.
Drawing geometry / Base without plate
98×128 mm.
Drawing geometry / Mounting-plate holes
4through holes Ø5.5 mm.
Drawing geometry / Projected dimensions
108×142 mm in the illustrated pose.
Joint module / Harmonic module / Torque
Power Spring component: maximum torque 80 Nm.
Joint module / Harmonic module / Encoder
19-bit encoder; component repeatability 0.6 arcmin.
Mechanical interface / Flange / Diameter
Outside Ø51.6 mm; hole pitch circle Ø40 mm.
Programming / Environments and protocols
ROS 1, serial protocol, TCP/IP, MODBUS; myStudio Pro.
Robot / Net weight / Store configuration
5.1 kg
Mechanical interface / Flange / Fasteners
8equally spaced M6 through holes.
Drawing geometry / Drawing dimension chain
Annotated segments55.8; 42.88; 130; 67; 113.85; 87.65; 95.15; 91.5 mm, plus441.38 mm linear dimension. Segment endpoints are defined by the drawing.
Programming / Languages and operating systems
Windows, Linux, macOS; Python, C++, C#, JavaScript.