← Back to Robots
Humanoid

Elephant Robotics Mercury B1

Submit correction
Request a Quote

About Elephant Robotics Mercury B1

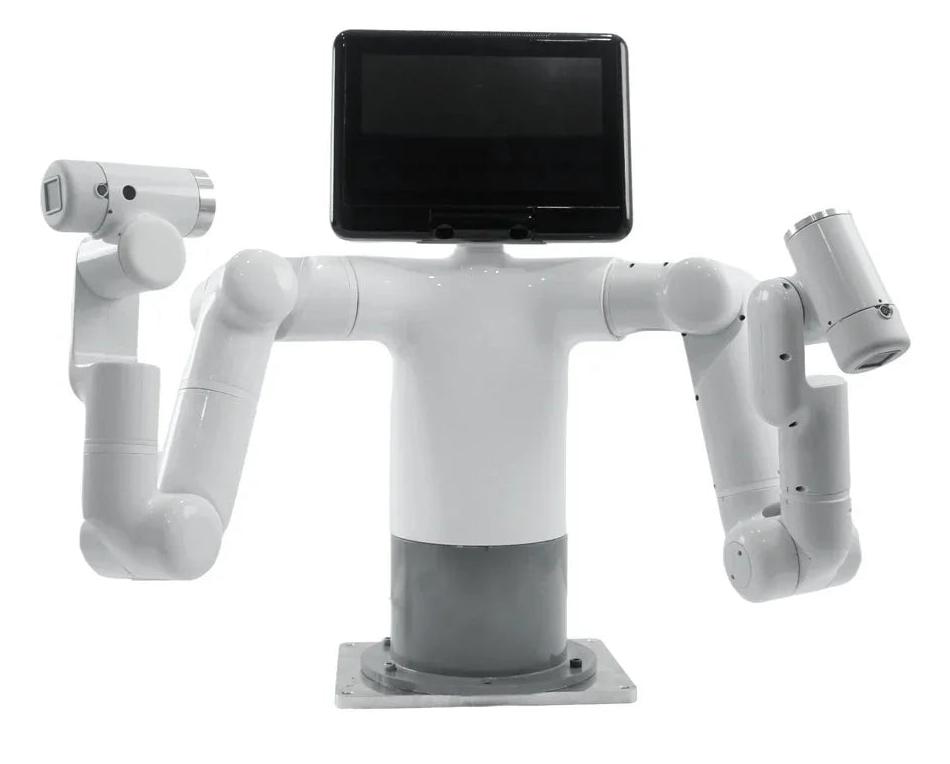
Elephant Robotics Mercury B1 is a desktop dual-arm robot for studying coordinated manipulation and human interaction.


Manufacturer

Key Specifications

Status
ACTIVE
Category
Humanoid
Robot / Model
Mercury B1
Robot / Cables
Hollow internal routing
Robot / Reducers
Harmonic
Development / ROS
ROS1, ROS2
Perception / Camera
Integrated 3D camera
Perception / Screen
9-inch LCD touchscreen
Robot / Composition
Two seven-axis A1 arms and torso
Development / Modbus
Supported
Robot / A1 arm reach
450 mm (For one A1 arm.)
Robot / Joint brakes
Electromagnetic
Robot / A1 arm payload
1 kg (For one constituent A1 arm; two-arm loads are not added.)
Development / Languages
Python, C++, C#, JavaScript
Development / Libraries
pymycobot Python API and Mercury C++ API
Development / myBlockly
Separate left/right arm programs
Control and IO / Tool IO
M8, 8 pins
Development / Simulation
RVIZ, MoveIt, Gazebo, MuJoCo
Robot / Manufacturer SKU
4011300002
Control and IO / Base USB
2×USB 3.0
Control and IO / Ethernet
External network port
Control and IO / Tool USB
4-pin camera connector
Robot / Arm repeatability
±0.05 mm
Robot / Operating voltage
24 V
Development / Motion modes
Free, joint, Cartesian; trajectory recording
Development / myStudio Pro
Supported
Robot / Degrees of freedom
17
Control and IO / Digital IO
6 inputs / 6 outputs, 24 V
Development / Teleoperation
VR/Aloha
Control and IO / Base supply
24 V DC
Control and IO / ESP32: SRAM
520 KB
Control and IO / Tool supply
24 V DC
Development / Development OS
Windows, Linux, macOS
Control and IO / ESP32: flash
4 MB
Perception / Microphone angle
180°
Perception / Microphone array
Linear, 4 microphones
Development / Network protocol
TCP/IP
Control and IO / Arm indication
5×5 RGB LED
Control and IO / Changing tools
With power off
Control and IO / Emergency stop
Emergency-stop circuit connector
Control and IO / Computer family
NVIDIA Jetson (Hardware revision and detailed parameters require order configuration.)
Perception / Display expressions
User-customizable
Perception / Microphone distance
5 m
Control and IO / Tool RS-485 pins
Reserved, not implemented
Development / Optional exoskeleton
myController S570
Control and IO / Arm subcontrollers
ESP32, left and right arms
Control and IO / ESP32: clock/cores
240 MHz, 2 cores
Control and IO / ESP32: performance
600 DMIPS
Control and IO / Wi-Fi and Bluetooth
Supported
Packing list in the handbook / Shipping list
Included
Packing list in the handbook / Product manual
Included
Packing list in the handbook / Mercury B1 robot
Included
Packing list in the handbook / 24 V power supply
Included
Packing list in the handbook / User instructions
Included
Packing list in the handbook / Product certificate
Included

Verified ecosystem

Software and resources

Official links and community projects are shown separately. Every published relationship has reviewable evidence.

0
verified official resources
0
verified compatible projects
0
public maintainers
No activity yet
latest verified ecosystem activity

Projects are ordered only within this robot ecosystem using verified compatibility, GitHub freshness and activity, and accepted community reports. This is not a global RobotSpace score.

Official resources

No first-party resource has been independently verified yet. Unverified catalog links are not shown as official.

Official software

No official software project has been verified yet.

Community projects

No verified community project has been linked yet.

Developers and contributors

No public maintainer profile is linked yet.

Verified activity

No verified project activity is available.

This ecosystem is still empty

The robot page remains useful for specifications while official resources and compatible projects are being verified.

Imported from the Unibot owner catalog · Not independently verified · Imported 2026-11-11 · Unibot source · Methodology