Robot / Cables
Hollow internal routing
Development / ROS
ROS1, ROS2
Perception / Camera
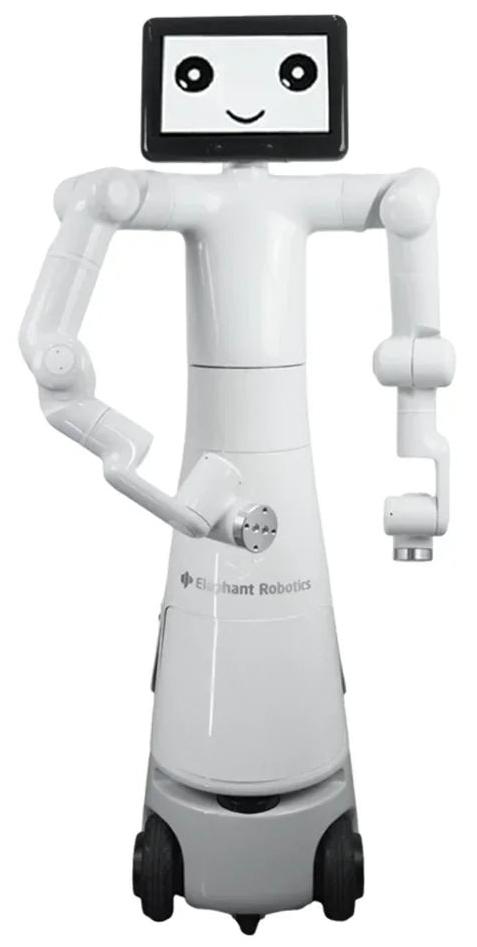
Integrated 3D camera
Perception / Screen
9-inch LCD touchscreen
Robot / Base motors
Direct drive
Robot / Composition
Mercury B1 and mobile base
Development / Modbus
Supported
Robot / A1 arm reach
450 mm (For one A1 arm.)
Robot / Base sensors
LiDAR, ultrasonic sensors and 2D vision
Robot / Joint brakes
Electromagnetic
Robot / Maximum speed
4.32 km/h
Robot / Storage space
15 L
Robot / A1 arm payload
1 kg (For one constituent A1 arm; two-arm loads are not added.)
Development / Languages
Python, C++, C#, JavaScript
Development / Libraries
pymycobot Python API and Mercury C++ API
Development / myBlockly
Separate left/right arm programs
Control and IO / Tool IO
M8, 8 pins
Development / Simulation
RVIZ, MoveIt, Gazebo, MuJoCo
Robot / Manufacturer SKU
4011300003
Control and IO / Base USB
2×USB 3.0
Control and IO / Ethernet
External network port
Control and IO / Tool USB
4-pin camera connector
Robot / Arm repeatability
±0.05 mm
Robot / Operating voltage
24 V
Development / Motion modes
Free, joint, Cartesian; trajectory recording
Development / myStudio Pro
Supported
Robot / Battery life up to
480 min (Maximum; load and route not specified.)
Robot / Degrees of freedom
19
Control and IO / Digital IO
6 inputs / 6 outputs, 24 V
Development / Teleoperation
VR/Aloha
Control and IO / Base supply
24 V DC
Control and IO / ESP32: SRAM
520 KB
Control and IO / Tool supply
24 V DC
Development / Development OS
Windows, Linux, macOS
Control and IO / ESP32: flash
4 MB
Perception / Microphone angle
180°
Perception / Microphone array
Linear, 4 microphones
Development / Network protocol
TCP/IP
Robot / Maximum climbing angle
15 °
Control and IO / Arm indication
5×5 RGB LED
Control and IO / Changing tools
With power off
Control and IO / Emergency stop
Emergency-stop circuit connector
Control and IO / Computer family
NVIDIA Jetson (Hardware revision and detailed parameters require order configuration.)
Perception / Display expressions
User-customizable
Perception / Microphone distance
5 m
Control and IO / Tool RS-485 pins
Reserved, not implemented
Development / Optional exoskeleton
myController S570
Control and IO / Arm subcontrollers
ESP32, left and right arms
Control and IO / ESP32: clock/cores
240 MHz, 2 cores
Control and IO / ESP32: performance
600 DMIPS
Control and IO / Wi-Fi and Bluetooth
Supported
Packing list in the handbook / Shipping list
Included
Packing list in the handbook / Product manual
Included
Packing list in the handbook / Mercury X1 robot
Included
Packing list in the handbook / 24 V power supply
Included
Packing list in the handbook / User instructions
Included
Packing list in the handbook / Product certificate
Included