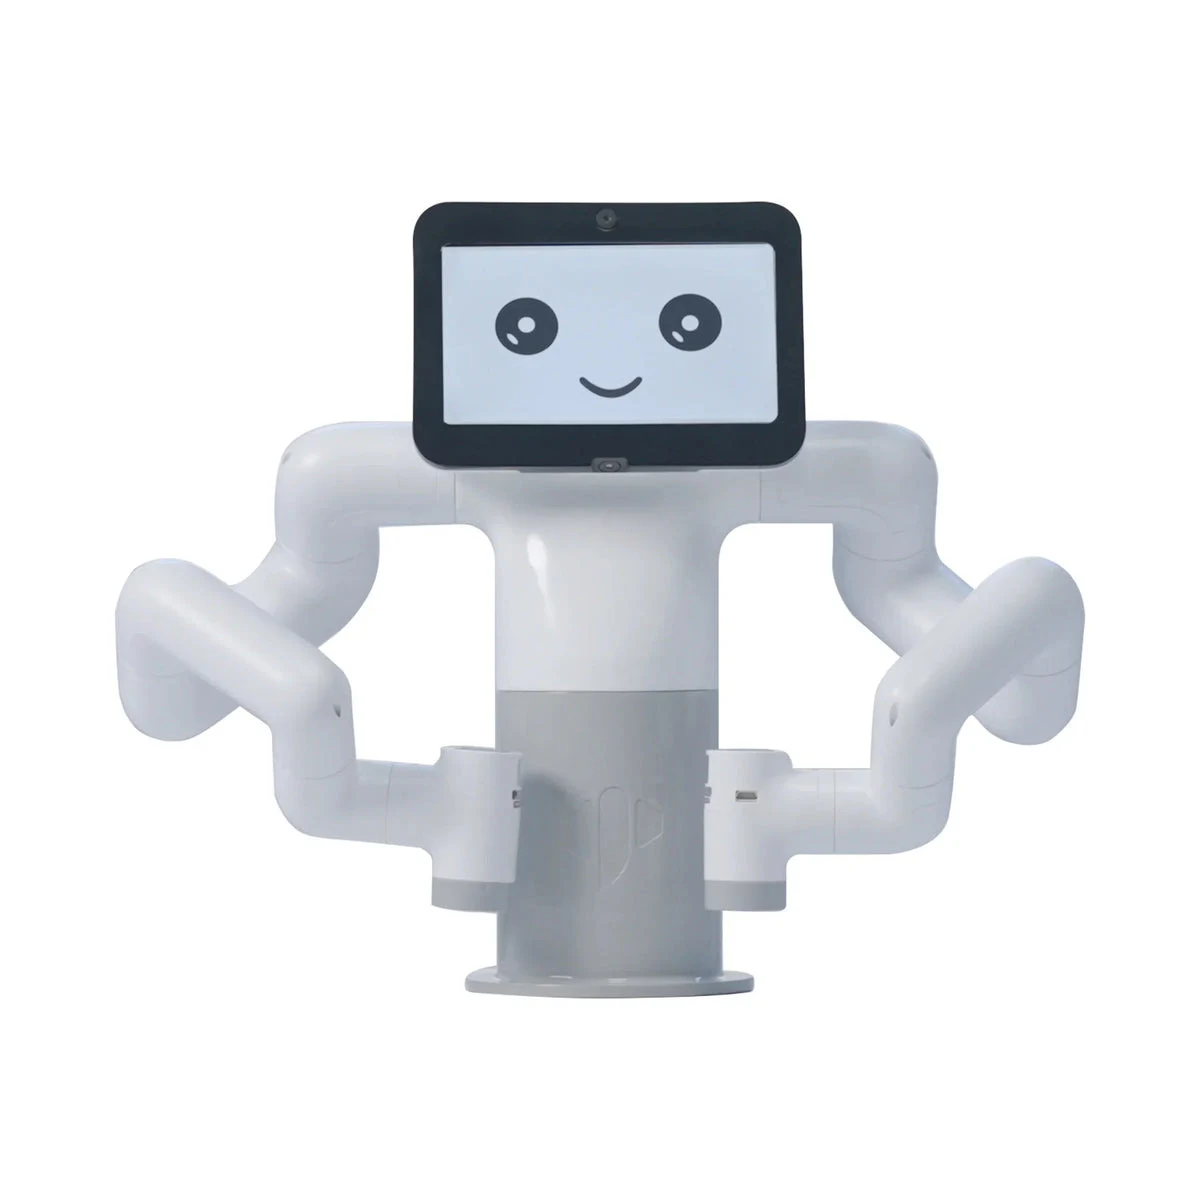
Category
Collaborative Robots and Manipulators
Programming / ROS 1
MoveIt; mybuddy package
Programming / ROS 2
Rviz2, slider control and model following
Programming / Python API
MyBuddy Python API for left/right arms and waist
Programming / VR control
VR control supported (VR controller is not listed in the base set)
Base GPIO and power / Power
External 24 V DC, 9.2 A
Programming / Control modes
Joint angles, coordinates and coordinate transforms
Geometry and mounting / Base
Ø123.4 mm; four Ø4.5 mm holes, 94×80 mm spacing
Display and cameras / Cameras
Two 2 MP HD cameras
Dual-arm platform / Actuators
13 brushless DC servos
Dual-arm platform / Execution
myBuddy 280, base platform without optional hands
Programming / Visual teaching
myBlockly, drag teaching and trajectory recording
Programming / Firmware updates
myStudio
Set and environment / Base set
myBuddy 280 Raspberry Pi, manual, power supply, flat base and G-clamp, jumpers, M4×35 screws and hex key
Base GPIO and power / Power plug
DC 5.5×2.1 mm
Dual-arm platform / Installation
Fixing to a rigid stationary or mobile base
Programming / Collision checking
API software function; off by default
Programming / Library interfaces
Over 100 control interfaces
Base GPIO and power / Output type
PNP, 3.3 V logic
Display and cameras / Expressions
Over 20 built-in dynamic expressions
Display and cameras / Touchscreen
7 inch
Dual-arm platform / Repeatability
±0.5 mm
Set and environment / Environment
Indoors; avoid water, dust, direct sunlight, vibration and strong electromagnetic interference
Base GPIO and power / Power switch
Latching button
Display and cameras / Lower camera
45° orientation; region localisation and object/QR recognition examples
Display and cameras / Upper camera
Face and body recognition examples
Geometry and mounting / End flange
Ø60 mm; nine Ø4.8 mm LEGO holes and Ø2.5 mm threaded holes; 8 mm spacing
Raspberry Pi main controller / CPU
Broadcom BCM2711, 64-bit, quad-core, 1.5 GHz
Raspberry Pi main controller / GPU
VideoCore VI, 500 MHz
Base GPIO and power / GPIO1 signals
G17, G18, G27, G23, G22, G24, G10, G25, G9, G8, G11, G7; 3.3 V logic
Set and environment / Optional hands
Gesture hands, grippers, pump and mounting tools are separate bundles
Base GPIO and power / GPIO1 connector
14 pins, 2.54 mm pitch
Dual-arm platform / Single-arm radius
280 mm
Base GPIO and power / Base Grove ports
Interfaces 2/3: G2/G3 and G5/G6; 5 V supply and GND
Dual-arm platform / Single-arm payload
250 g
Dual-arm platform / Whole-platform DOF
13
Programming / Minimum command response
30 ms (Declared fastest response; not a cycle time or whole-system latency)
Base GPIO and power / GPIO multiplexing
General I/O is unavailable when the pin is used for another function
Set and environment / Relative humidity
20–70%
Dual-arm platform / Declared service life
500 h
End controllers and connectors / Firmware
Separate atomMain and picoMain
Geometry and mounting / Front-view height
368 mm (Pose and projections shown in original drawings)
Raspberry Pi main controller / Controller
Raspberry Pi 4B, 4 GB
Raspberry Pi main controller / Memory card
32 GB
Geometry and mounting / Side-view dimension
158.44 mm (Pose and projections shown in original drawings)
Raspberry Pi main controller / External USB
USB 2.0
Raspberry Pi main controller / Network port
Ethernet for communication with PC and other equipment
Set and environment / Operating temperature
0–45 °C
Geometry and mounting / Width, arms extended
863 mm (Pose and projections shown in original drawings)
Dual-arm platform / Independent group control
Separate left arm, right arm and waist control
End controllers and connectors / Per-arm GPIO
G22, G19, G23, G33; 3.3 V logic; 5 V/3.3 V supplies and GND
Raspberry Pi main controller / External display
HDMI Type-A with internal/external display toggle button
End controllers and connectors / Atom indication
5×5 RGB matrix on G27 and G39 button
End controllers and connectors / Gripper control
Servo port for optional adaptive gripper
Geometry and mounting / Vertical dimension chain
101.5 / 140 mm (Pose and projections shown in original drawings)
Raspberry Pi main controller / Display indicator
Green when the external display is selected; off for the internal screen
End controllers and connectors / Interface symmetry
Left and right arm end interfaces are identical
End controllers and connectors / Per-arm output type
PNP, 3.3 V logic
Raspberry Pi main controller / Wireless connectivity
Bluetooth and Wi-Fi
Geometry and mounting / Arm and shoulder dimension chain
75 / 96 / 110 / 131 mm (Pose and projections shown in original drawings)
End controllers and connectors / Communication and firmware
Type-C for PC and firmware updates; Grove