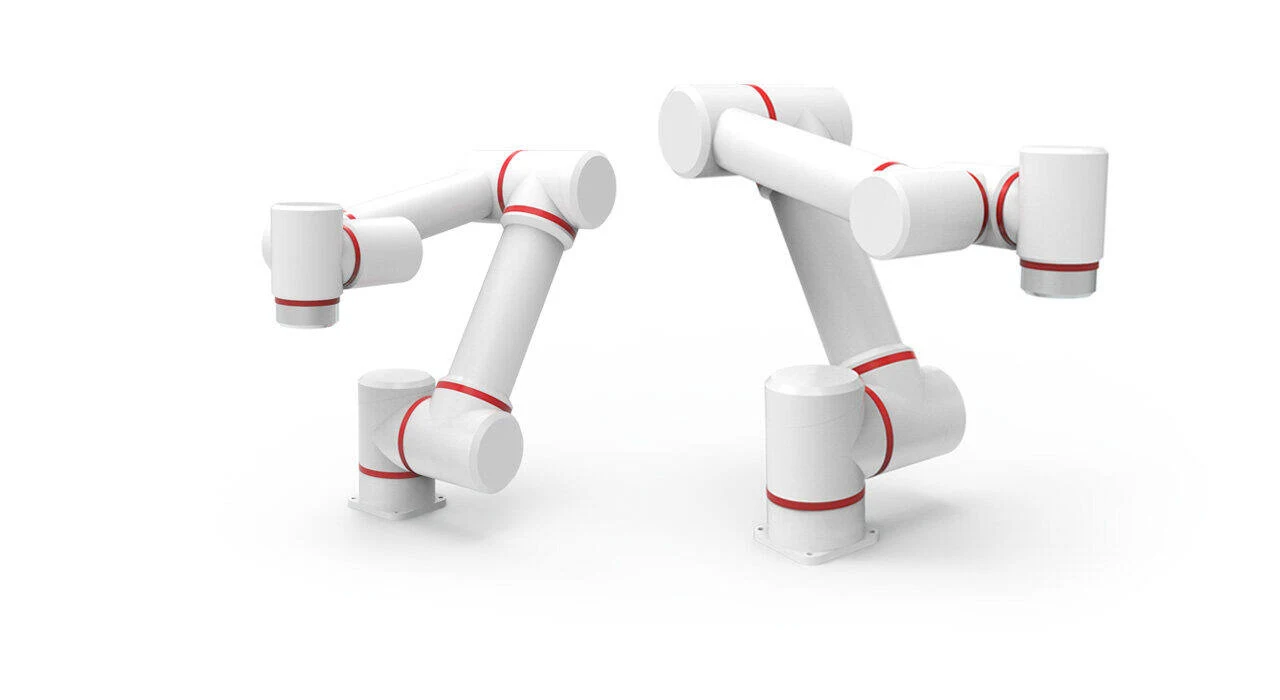
Category
Collaborative Robots and Manipulators
Robot arm / Payload
3 kg (Permissible load decreases as its centre moves away from the J6 flange.)
Robot arm / Arm base
123 × 123 mm (Two base dimensions, not the overall arm size.)
Robot arm / Arm mass
17 kg
Control / Programming
Graphical
Controller / Box mass
25 kg
Mounting / Base holes
4 × Ø9 mm (Through holes.)
Robot arm / Materials
Aluminium alloy, rubber
Control / Path teaching
Hand-guided teaching
Control / SDK languages
Python, C++, Java
Robot arm / Family name
Panda 3
Robot arm / Joint range
±360 ° (Each of the six joints.)
Control / ROS extensions
Supported (ROS version is not specified.)
Mounting / Base mounting
4 × M8
Mounting / Flange threads
8 × M6,5mm depth (Ø5mm drilling to6mm depth.)
Robot arm / Arm protection
IP54
Controller / Box dimensions
545 × 285 × 433 mm (L × W × H; separate box.)
Controller / Box protection
IP40
Mounting / Base bolt length
Selected for platform thickness
Mounting / Flange outer step
Ø63 mm (Nominal diameter.)
Teach pendant / Pendant mass
1.8 kg
Control / Collision detection
Motion stop (Depends on collision-detection settings and the working application.)
Control / Control environment
RoboFlow
Controller / Box input supply
110–240 V AC, 50/60 Hz
Mounting / Flange bolt circle
Ø50 mm
Robot arm / Drives and brakes
Integrated in the arm body
Robot arm / System components
Arm, controller, teach pendant
Mounting / Bolt strength class
12.9
Mounting / Flange central bore
Ø31.5 mm (Nominal diameter.)
Mounting / Locating-hole angle
22.5 ° (Relative to the vertical radius in the drawing.)
Robot arm / Degrees of freedom
6
Robot arm / Typical tool speed
1 m/s
Teach pendant / Pendant screen
10.4 in
Control / Programming interface
API
Mounting / Flange locating hole
Ø6, +0.015/0 mm (5mm depth.)
Robot arm / Storage temperature
0…50 °C
Mounting / Mounting-hole spacing
100 × 100 mm
Robot arm / Mounting orientation
Any angle
Mounting / Base tightening torque
28 N·m
Robot arm / J1–J3 maximum speed
180 °/s
Robot arm / J4–J6 maximum speed
208 °/s
Robot arm / Operating temperature
0…50 °C
Equipment connections / I/O supply
24 V, 2 A
Robot arm / Position repeatability
±0.05 mm
Teach pendant / Pendant dimensions
255 × 230 × 90 mm (L × W × H.)
Teach pendant / Pendant protection
IP20
Teach pendant / Pendant resolution
1024 × 768 px
Equipment connections / Input groups
IN0–3/COM1; IN4–7/COM2; IN8–11/COM3; IN12–15/COM4
Robot arm / Installation environment
Indoors
Controller / Controller certification
CE
Equipment connections / Output groups
OUT0–3, OUT4–7, OUT8–11, OUT12–15 (Signals alternate with24V terminals in each8-pin group.)
Equipment connections / Pendant cable
4 m
Mounting / Packaged mounting hardware
M8 bolts, washers and nuts (Exact quantities are not stated.)
Robot arm / Typical power consumption
160 W
Equipment connections / Controller USB
2 ports (USB1/USB2 for program files, a mouse or keyboard.)
Control / Additional protective devices
LiDAR, light curtain (Optional workstation equipment.)
Equipment connections / Network protocol
TCP/IP
Equipment connections / RS-232 terminals
0:GND;1:232RX;2:232TX
Equipment connections / RS-485 terminals
3:485D+;4:485D−
Equipment connections / Controller AC cable
2 m
Equipment connections / Controller Ethernet
1 port (Communication with a computer and other equipment.)
Equipment connections / DC supply terminals
0–3:24V;4–7:GND
Equipment connections / Digital output type
NPN; active0V
Equipment connections / Serial communication
RS-232: full duplex;RS-485: half duplex
Equipment connections / External E-STOP pin 0
Undefined
Equipment connections / External E-STOP pin 1
ES1+
Equipment connections / External E-STOP pin 2
ES1−
Equipment connections / External E-STOP pin 3
ES2+
Equipment connections / External E-STOP pin 4
ES2−
Equipment connections / Controller–arm cable
4 m
Equipment connections / External control pin 0
SS1
Equipment connections / External control pin 1
SS2
Equipment connections / External control pin 2
START
Equipment connections / External control pin 3
STOP
Equipment connections / External control pin 4
COM0
Equipment connections / Input common terminals
COM1–COM4 (Input polarity depends on connecting the common to24V or0V.)
Equipment connections / Controller digital inputs
16: IN0–IN15
Equipment connections / Controller digital outputs
16: OUT0–OUT15