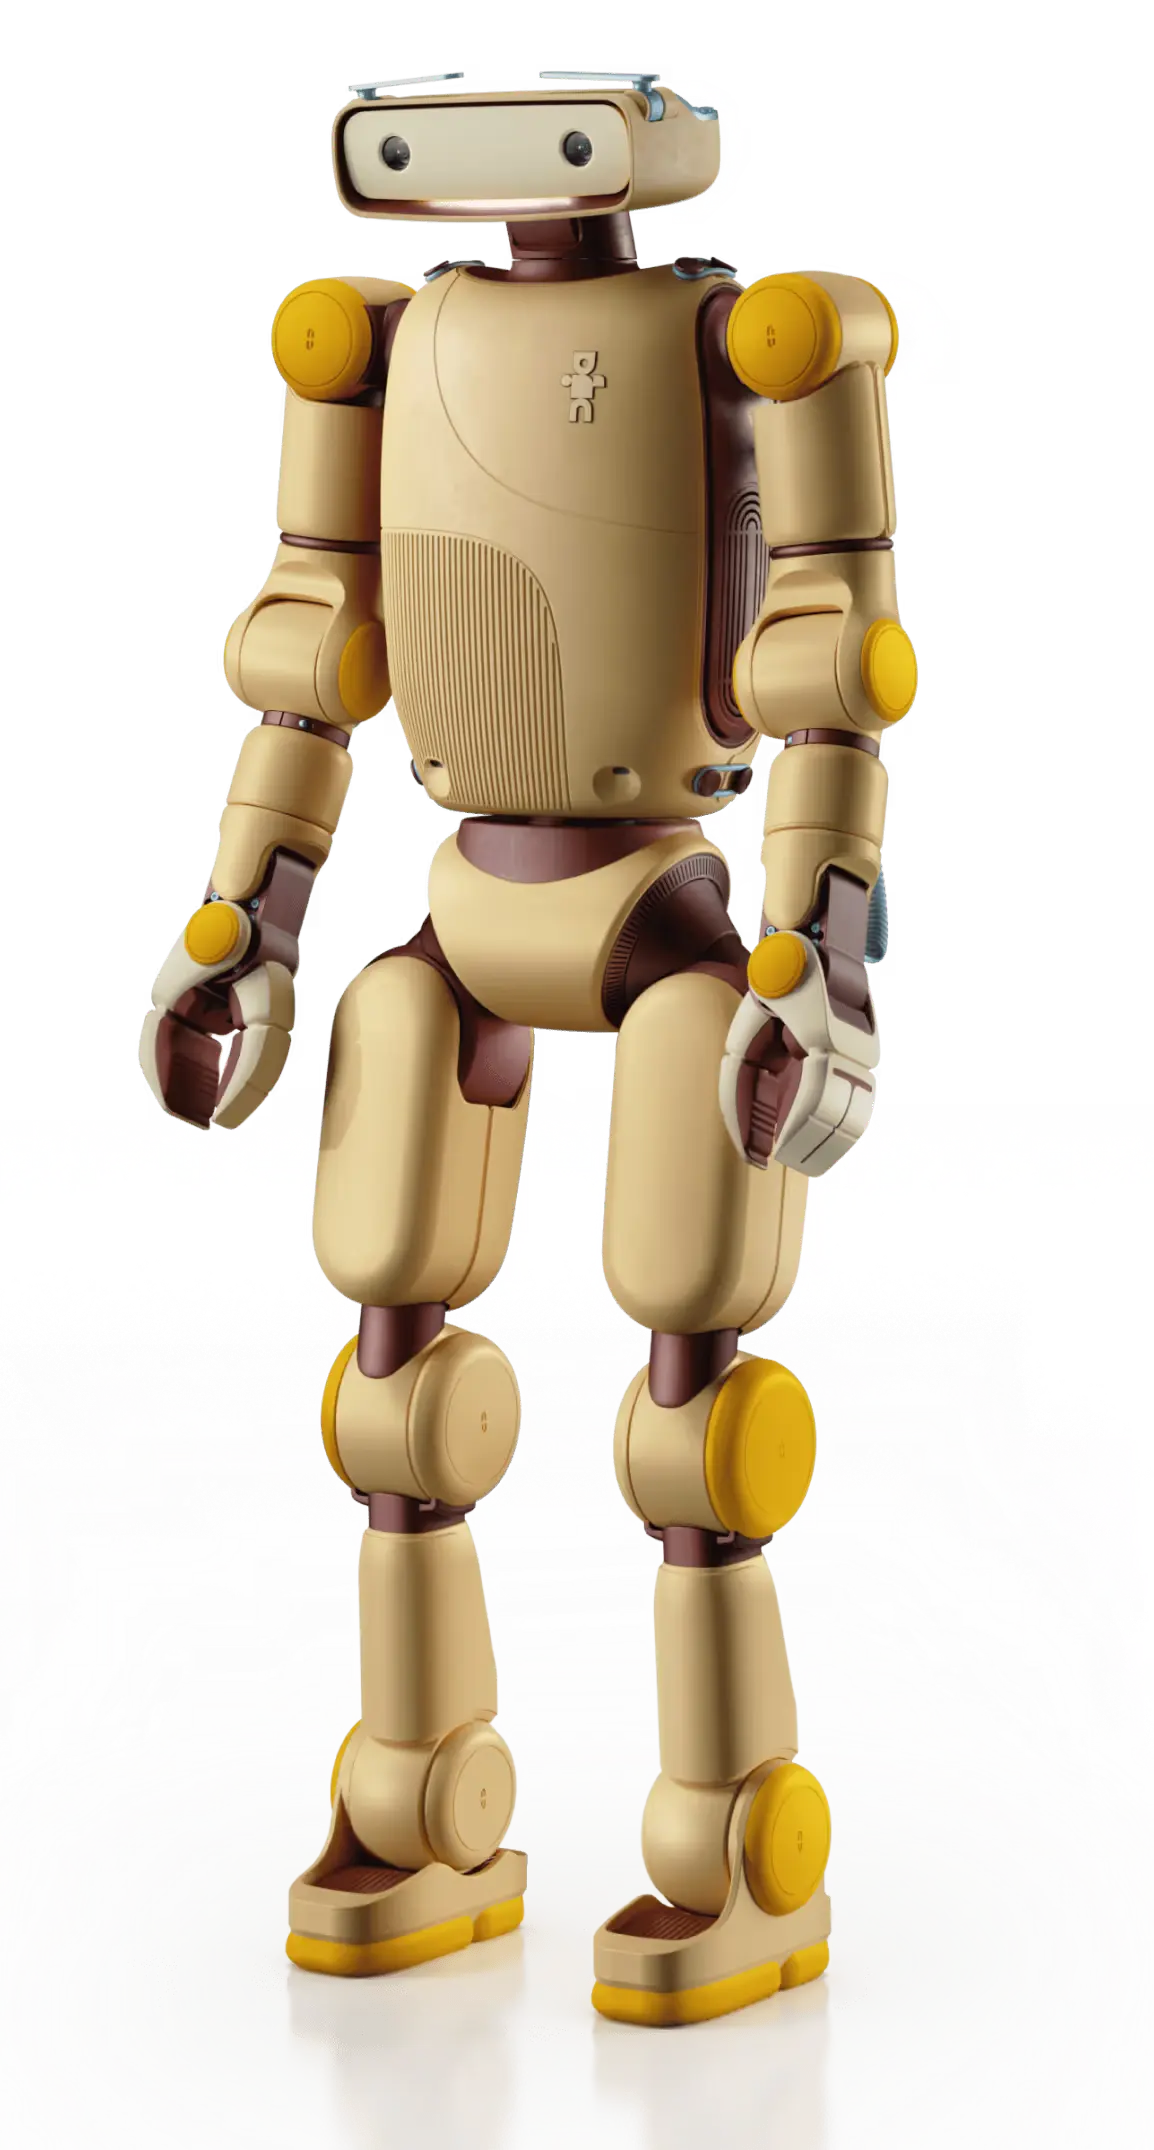
Power / Runtime
180-210 min (Swappable battery)
Actuation / Feet
Low-impact design
Sensing / Camera
ZED2i RGB-D stereo
Power / DC system
46.8 V DC (Nominal system voltage)
Operation / Handle
Ergonomic
Sensing / ToF grid
8 × 8 (Component: VL53L8CX)
Body / Construction
Aluminium and composites; padded exterior
Computing / Compute
NVIDIA Jetson AGX Orin
Computing / Storage
1 TB (NVMe SSD)
Actuation / Arm axes
6 DOF (Component: each arm)
Actuation / Grippers
Rubberised interior
Actuation / Leg axes
5 DOF (Component: each leg)
Actuation / Neck axes
2 DOF (Component: neck)
Power / Battery cells
Molicel P50B
Sensing / Microphones
4 MEMS
Sensing / ToF sensors
4 × VL53L8CX
Environment / Humidity
10-90 % RH (Operation and storage; noncondensing)
Software platform / SDK
Fauna SDK
Actuation / Gripper axes
1 DOF (Component: each gripper)
Environment / Protection
IP20
Power / Battery chemistry
Li-ion
Power / Battery, extended
10000 mAh (Extended-run battery)
Power / Battery, standard
5000 mAh (Standard battery)
Sensing / Inertial sensor
9-axis IMU
Sensing / ToF depth range
4 m (Component: VL53L8CX)
Operation / Emergency stop
E-Stop
Sensing / ToF field of view
65 ° (Component: VL53L8CX)
Connectivity / External port
Ethernet
Sensing / Camera FoV H×V×D
110 × 70 × 120 ° (Component: ZED2i)
Sensing / Camera depth range
0.3-20 m (Component: ZED2i; diagram range)
Actuation / Degrees of freedom
29 DOF (Including2actuated eyebrows)
Service rates / Planning cycle
10 Hz (Default)
Software platform / Simulation
NVIDIA Isaac Sim / Gazebo / MuJoCo
Audio and expression / Speakers
2
Operation / Safety architecture
High-level / low-level / inherent layers
Service rates / State recording
125 Hz (Proprioceptive state; data-collection mode)
Developer services / Agent tools
MCP server for motion modes, behaviours and navigation (Manufacturer technical report v1; developer services)
Operation / Included accessories
Li-ion battery / Fauna Charger / controller / documentation
Developer services / Motion modes
Walking / kneeling / crawling; separately trained controllers (Manufacturer technical report v1; developer services)
Environment / Storage temperature
5-35 °C
Service rates / Command recording
50 Hz (Pose, joint and velocity commands; data-collection mode)
Service rates / Odometry estimate
50 Hz (Pose / velocity / covariance)
Software platform / API languages
Python / C++
Software platform / Visualisation
Foxglove
Architecture and control / Mapping
Visual-inertial-kinematic odometry / TSDF SLAM
Connectivity / Wireless connection
Wi-Fi5.2
Actuation / Gripper fingertip force
12 N (Software force limit; component: gripper)
Environment / Operating environment
Indoor only
Environment / Operating temperature
10-30 °C
Service rates / Stereo RGB recording
30 Hz (Data-collection mode)
Software platform / VR teleoperation
Meta Quest3 (VR headset not included)
Architecture and control / Deployment
Docker containers
Architecture and control / Navigation
Global and local route planning / obstacle avoidance
Audio and expression / Facial display
Full-colour360° LED array
Developer services / VR communication
JSON over WebSocket; video and audio over WebRTC (Manufacturer technical report v1; developer services)
Developer services / Voice activation
openWakeWord; hey robot wake phrase (Manufacturer technical report v1; developer services)
Audio and expression / Audio processor
Cirrus Logic CS47L35 DSP
Audio and expression / Audio processing
ASR / TTS / beamforming
Architecture and control / Voice services
ASR / TTS; developer assembles an agent from services
Architecture and control / On-device voice
NVIDIA Riva, configurable option
Developer services / Developer diagnostics
Companion web app; synchronized telemetry, event and sensor logs (Manufacturer technical report v1; developer services)
Audio and expression / Articulated eyebrows
2
Architecture and control / Operator feedback
Visual / haptic feedback
Architecture and control / Teleoperation app
Embody for Meta Quest
Per-arm payloads / Rated payload, bent elbow
1.1 kg (Per arm; Bent elbow; Indefinitely; theoretical payload, availability depends on teleoperation controller)
Architecture and control / Internal CAN, MCM0
CAN0:left leg;CAN1:right leg;CAN2:torso (Internal component)
Architecture and control / Internal CAN, MCM1
CAN0:left arm;CAN1:right arm;CAN2:neck (Internal component)
Architecture and control / Control motherboard
Power distribution / sensor acquisition / motor control
Per-arm payloads / Maximum payload, bent elbow
11.2 kg (Per arm; Bent elbow; <10s; theoretical payload, availability depends on teleoperation controller)
Per-arm payloads / Nominal payload, bent elbow
5.0 kg (Per arm; Bent elbow; <90s; theoretical payload, availability depends on teleoperation controller)
Architecture and control / Internal camera link
USB to Jetson (Internal component)
Per-arm payloads / Rated payload, forward raise
0.7 kg (Per arm; Forward raise; Indefinitely; theoretical payload, availability depends on teleoperation controller)
Per-arm payloads / Rated payload, lateral raise
0.0 kg (Per arm; Lateral raise; Indefinitely; theoretical payload, availability depends on teleoperation controller; maintaining this pose indefinitely is not recommended even without payload)
Architecture and control / Application transport
ROS2 / RMW Zenoh
Architecture and control / Internal sensor links
UART/I2C:IMU and ToF array (Internal component)
Architecture and control / Motor control modules
3 MCMs:0/1/2
Architecture and control / Independent monitoring
Embedded processors independent of application compute
Per-arm payloads / Maximum payload, forward raise
3.7 kg (Per arm; Forward raise; <10s; theoretical payload, availability depends on teleoperation controller)
Per-arm payloads / Maximum payload, lateral raise
5.6 kg (Per arm; Lateral raise; <10s; theoretical payload, availability depends on teleoperation controller)
Per-arm payloads / Nominal payload, forward raise
1.75 kg (Per arm; Forward raise; <90s; theoretical payload, availability depends on teleoperation controller)
Per-arm payloads / Nominal payload, lateral raise
2.5 kg (Per arm; Lateral raise; <90s; theoretical payload, availability depends on teleoperation controller)
Architecture and control / External voice services
Deepgram Flux / ElevenLabs v2
Architecture and control / Controller communication
CBOR over Ethernet
Architecture and control / Robot description formats
USD / URDF / MJCF