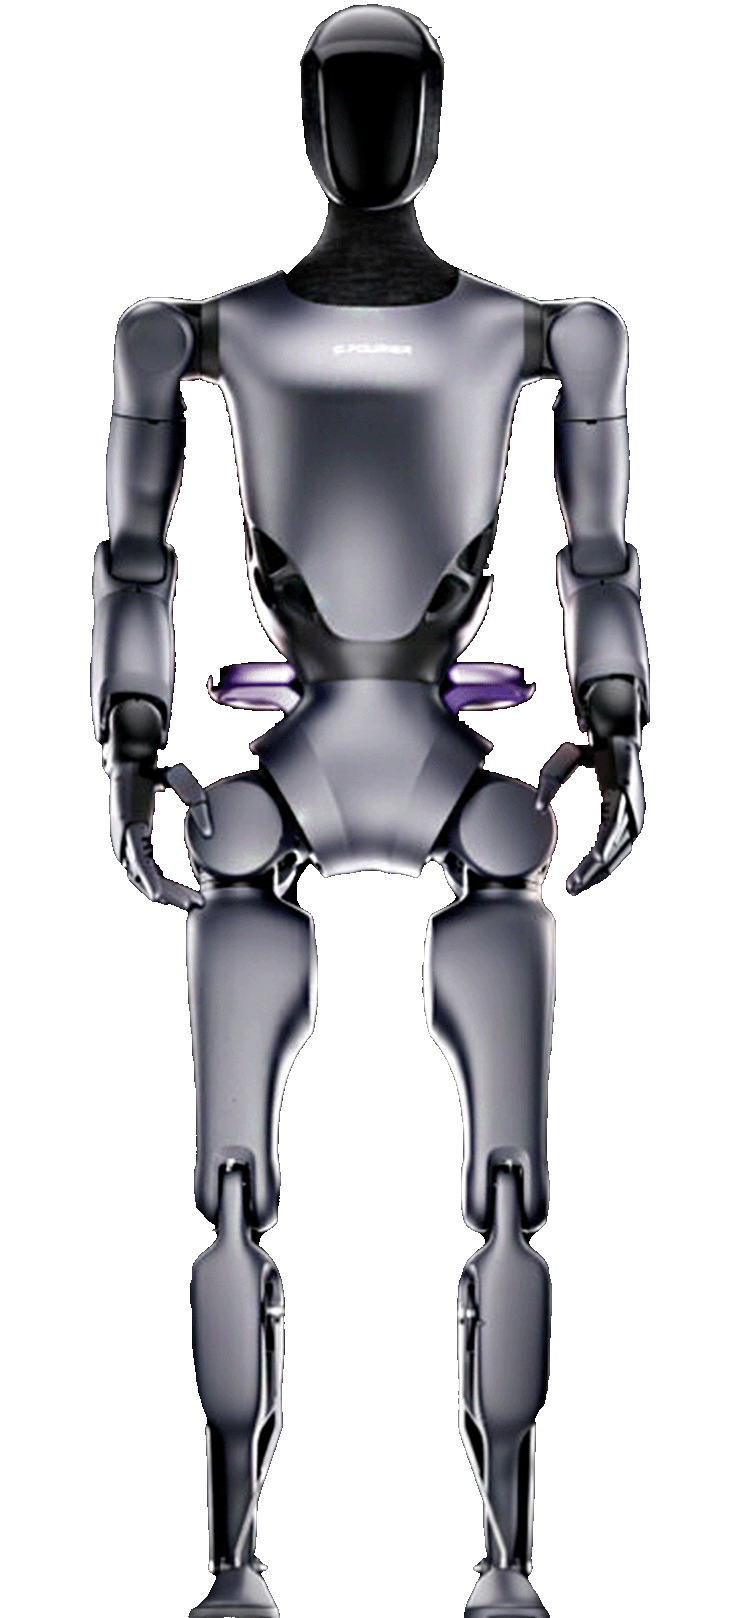
Specifications and equipment / IMU
6 axes (Acceleration and angular velocity)
Joint limits / head yaw: Torque limit
17.325 N·m (Control upper limit)
Specifications and equipment / Camera
Binocular
Specifications and equipment / Height
175 cm
Specifications and equipment / USB3.0
Available (Under protective cover)
Joint limits / waist yaw: Torque limit
74.45 N·m (Control upper limit)
Specifications and equipment / Arm DOF
7 DOF (Per arm excluding hand)
Specifications and equipment / Leg DOF
6 DOF (Per leg)
Joint limits / head pitch: Torque limit
17.325 N·m (Control upper limit)
Joint limits / head yaw: Velocity limit
9.1627 rad/s (Control upper limit)
Specifications and equipment / Arm span
1520 mm
Specifications and equipment / Head DOF
2 DOF
Specifications and equipment / Material
Aluminium alloy and engineering plastic
Joint limits / head yaw: Position limits
-1.3963…1.3963 rad (Lower…upper limit)
Joint limits / waist yaw: Velocity limit
7.7568 rad/s (Control upper limit)
Specifications and equipment / Waist DOF
1 DOF
Joint limits / head pitch: Velocity limit
9.1627 rad/s (Control upper limit)
Joint limits / left hip yaw: Torque limit
54.33 N·m (Control upper limit)
Joint limits / waist yaw: Position limits
-2.618…2.618 rad (Lower…upper limit)
Specifications and equipment / Basic hand
6 DOF (Per hand)
Specifications and equipment / Net weight
≈63 kg (Battery inclusion not stated)
Specifications and equipment / USB Type-C
Available (Dock must be connected before power-on; dock expands USB/HDMI)
Joint limits / head pitch: Position limits
-0.5236…0.5236 rad (Lower…upper limit)
Joint limits / left hip roll: Torque limit
95.472 N·m (Control upper limit)
Joint limits / right hip yaw: Torque limit
54.33 N·m (Control upper limit)
Joint limits / left hip pitch: Torque limit
366.05 N·m (Control upper limit)
Joint limits / left hip yaw: Velocity limit
14.745 rad/s (Control upper limit)
Joint limits / left wrist yaw: Torque limit
17.325 N·m (Control upper limit)
Joint limits / right hip roll: Torque limit
95.472 N·m (Control upper limit)
Specifications and equipment / Battery type
Lithium-ion
Joint limits / left ankle roll: Torque limit
29.835 N·m (Control upper limit)
Joint limits / left hip roll: Velocity limit
12.362 rad/s (Control upper limit)
Joint limits / left hip yaw: Position limits
-0.69813…1.5708 rad (Lower…upper limit)
Joint limits / left knee pitch: Torque limit
366.05 N·m (Control upper limit)
Joint limits / left wrist roll: Torque limit
17.325 N·m (Control upper limit)
Joint limits / right hip pitch: Torque limit
366.05 N·m (Control upper limit)
Joint limits / right hip yaw: Velocity limit
14.745 rad/s (Control upper limit)
Joint limits / right wrist yaw: Torque limit
17.325 N·m (Control upper limit)
Specifications and equipment / 100M Ethernet
100 Mbit/s
Specifications and equipment / Charging time
≈120 min
Specifications and equipment / Dual encoders
23/23; 24/24 bit (Lower limbs; upper limbs)
Specifications and equipment / Enhanced hand
12 DOF (Optional; per hand)
Specifications and equipment / Perception AI
6 TOPS
Specifications and equipment / Walking speed
5 km/h (Not stated as maximum)
Joint limits / left ankle pitch: Torque limit
54.33 N·m (Control upper limit)
Joint limits / left elbow pitch: Torque limit
42.75 N·m (Control upper limit)
Joint limits / left hip pitch: Velocity limit
6.4997 rad/s (Control upper limit)
Joint limits / left hip roll: Position limits
-0.59341…1.5708 rad (Lower…upper limit)
Joint limits / left wrist pitch: Torque limit
17.325 N·m (Control upper limit)
Joint limits / left wrist yaw: Velocity limit
9.1627 rad/s (Control upper limit)
Joint limits / right ankle roll: Torque limit
29.835 N·m (Control upper limit)
Joint limits / right hip roll: Velocity limit
12.362 rad/s (Control upper limit)
Joint limits / right hip yaw: Position limits
-1.5708…0.69813 rad (Lower…upper limit)
Joint limits / right knee pitch: Torque limit
366.05 N·m (Control upper limit)
Joint limits / right wrist roll: Torque limit
17.325 N·m (Control upper limit)
Specifications and equipment / Actuator count
≤53 (With optional 12-DOF hands)
Specifications and equipment / Battery energy
≈950 Wh
Specifications and equipment / Battery weight
≤9 kg
Specifications and equipment / Endurance time
≈120 min (Load and mode unspecified)
Specifications and equipment / Perception CPU
4 × Cortex-A76 + 4 × Cortex-A55 (8 cores; max2.4GHz)
Specifications and equipment / Perception GPU
Arm Mali-G610 MC4
Specifications and equipment / Perception RAM
8 GB
Joint limits / left ankle roll: Velocity limit
16.755 rad/s (Control upper limit)
Joint limits / left hip pitch: Position limits
-2.618…2.618 rad (Lower…upper limit)
Joint limits / left knee pitch: Velocity limit
6.4997 rad/s (Control upper limit)
Joint limits / left shoulder yaw: Torque limit
42.75 N·m (Control upper limit)
Joint limits / left wrist roll: Velocity limit
9.1627 rad/s (Control upper limit)
Joint limits / left wrist yaw: Position limits
-1.8326…1.8326 rad (Lower…upper limit)
Joint limits / right ankle pitch: Torque limit
54.33 N·m (Control upper limit)
Joint limits / right elbow pitch: Torque limit
42.75 N·m (Control upper limit)
Joint limits / right hip pitch: Velocity limit
6.4997 rad/s (Control upper limit)
Joint limits / right hip roll: Position limits
-1.5708…0.59341 rad (Lower…upper limit)
Joint limits / right wrist pitch: Torque limit
17.325 N·m (Control upper limit)
Joint limits / right wrist yaw: Velocity limit
9.1627 rad/s (Control upper limit)
Specifications and equipment / External supply
16 V DC / 6 A (FGG.0B connector; red contact positive)
Joint limits / left ankle pitch: Velocity limit
14.745 rad/s (Control upper limit)
Joint limits / left ankle roll: Position limits
-0.38397…0.38397 rad (Lower…upper limit)
Joint limits / left elbow pitch: Velocity limit
6.283 rad/s (Control upper limit)
Joint limits / left knee pitch: Position limits
-0.087266…2.3562 rad (Lower…upper limit)
Joint limits / left shoulder roll: Torque limit
74.45 N·m (Control upper limit)
Joint limits / left wrist pitch: Velocity limit
9.1627 rad/s (Control upper limit)
Joint limits / left wrist roll: Position limits
-0.95993…0.95993 rad (Lower…upper limit)
Joint limits / right ankle roll: Velocity limit
16.755 rad/s (Control upper limit)
Joint limits / right hip pitch: Position limits
-2.618…2.618 rad (Lower…upper limit)
Joint limits / right knee pitch: Velocity limit
6.4997 rad/s (Control upper limit)
Joint limits / right shoulder yaw: Torque limit
42.75 N·m (Control upper limit)
Joint limits / right wrist roll: Velocity limit
9.1627 rad/s (Control upper limit)
Joint limits / right wrist yaw: Position limits
-1.8326…1.8326 rad (Lower…upper limit)
Specifications and equipment / Gigabit Ethernet
1000 Mbit/s
Specifications and equipment / Perception audio
Microphone
Joint limits / left ankle pitch: Position limits
-0.7854…0.7854 rad (Lower…upper limit)
Joint limits / left elbow pitch: Position limits
-1.5272…0.47997 rad (Lower…upper limit)
Joint limits / left shoulder pitch: Torque limit
74.45 N·m (Control upper limit)
Joint limits / left shoulder yaw: Velocity limit
6.283 rad/s (Control upper limit)
Joint limits / left wrist pitch: Position limits
-0.61087…0.61087 rad (Lower…upper limit)
Joint limits / right ankle pitch: Velocity limit
14.745 rad/s (Control upper limit)
Joint limits / right ankle roll: Position limits
-0.38397…0.38397 rad (Lower…upper limit)
Joint limits / right elbow pitch: Velocity limit
6.283 rad/s (Control upper limit)
Joint limits / right knee pitch: Position limits
-0.087266…2.3562 rad (Lower…upper limit)
Joint limits / right shoulder roll: Torque limit
74.45 N·m (Control upper limit)
Joint limits / right wrist pitch: Velocity limit
9.1627 rad/s (Control upper limit)
Joint limits / right wrist roll: Position limits
-0.95993…0.95993 rad (Lower…upper limit)
Joint limits / left shoulder roll: Velocity limit
7.7568 rad/s (Control upper limit)
Joint limits / left shoulder yaw: Position limits
-1.8326…1.8326 rad (Lower…upper limit)
Joint limits / right ankle pitch: Position limits
-0.7854…0.7854 rad (Lower…upper limit)
Joint limits / right elbow pitch: Position limits
-1.5272…0.47997 rad (Lower…upper limit)
Joint limits / right shoulder pitch: Torque limit
74.45 N·m (Control upper limit)
Joint limits / right shoulder yaw: Velocity limit
6.283 rad/s (Control upper limit)
Joint limits / right wrist pitch: Position limits
-0.61087…0.61087 rad (Lower…upper limit)
Specifications and equipment / Battery cycle life
≥500 cycles (80% DoD)
Specifications and equipment / Motion-control CPU
Intel Core i7 (14 cores, 18 threads, max4.5GHz)
Specifications and equipment / Motion-control RAM
16 GB
Specifications and equipment / Operating humidity
20–80 % RH (Non-condensing)
Specifications and equipment / Perception storage
64 GB
Joint limits / left shoulder pitch: Velocity limit
7.7568 rad/s (Control upper limit)
Joint limits / left shoulder roll: Position limits
-0.5236…2.7925 rad (Lower…upper limit)
Joint limits / right shoulder roll: Velocity limit
7.7568 rad/s (Control upper limit)
Joint limits / right shoulder yaw: Position limits
-1.8326…1.8326 rad (Lower…upper limit)
Specifications and equipment / Single-hand payload
≈3 kg
Joint limits / left shoulder pitch: Position limits
-2.9671…2.9671 rad (Lower…upper limit)
Joint limits / right shoulder pitch: Velocity limit
7.7568 rad/s (Control upper limit)
Joint limits / right shoulder roll: Position limits
-2.7925…0.5236 rad (Lower…upper limit)
Specifications and equipment / Local emergency stop
1 pc
Joint limits / right shoulder pitch: Position limits
-2.9671…2.9671 rad (Lower…upper limit)
Specifications and equipment / Operating temperature
0…45 °C
Specifications and equipment / Calf and thigh lengths
465 + 378 mm
Specifications and equipment / Charging voltage limit
46.2 V
Specifications and equipment / Motion-control storage
512 GB
Specifications and equipment / Battery nominal voltage
39.6 V
Specifications and equipment / Compute-module networks
Gigabit Ethernet; Wi-Fi 6 (Both motion and perception modules)
Specifications and equipment / Wireless emergency stop
1 pc
Specifications and equipment / Maximum joint peak torque
436 N·m
Specifications and equipment / Span with dexterous hands
≤1920 mm (Optional 12-DOF hands)
Specifications and equipment / Dimensions in source order
1750 × 552 × 275 mm (Axis order not specified)