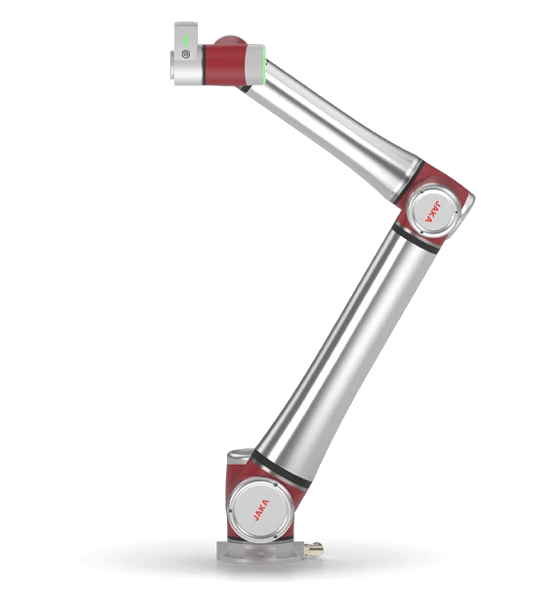
Category
Collaborative Robots and Manipulators
Arm / Programming
Graphical and hand-guided programming
Vision / Lighting
Built-in
Arm / Base diameter
18.8 cm
Arm / Repeatability
±0.03 mm
Camera / Image mode
Colour, monochrome (Modes listed in the camera table; the particular supplied configuration is not specified.)
Camera / Resolution
3456×2880 pixels
Camera / Consumption
<18 W
Vision / Calibration
Hand-eye
Arm / Body protection
IP54
Camera / Input supply
9–26 V DC
Tool / Digital inputs
2 channels
Arm / Operator devices
PC, tablet, smartphone
Camera / Communication
Gigabit Ethernet
Camera / Input current
1 A
Camera / Standard lens
12 mm
Image scale / At 80 mm
0.016 mm/pixel (Working distance 80 mm; typical table, lens and resolution not stated.)
Tool / Analogue inputs
2 channels
Tool / Digital outputs
2 channels
Camera / Optional light
Red / blue; polarised / non-polarised
Camera / Standard light
White
Image scale / At 150 mm
0.029 mm/pixel (Working distance 150 mm; typical table, lens and resolution not stated.)
Image scale / At 230 mm
0.043 mm/pixel (Working distance 230 mm; typical table, lens and resolution not stated.)
Image scale / At 300 mm
0.056 mm/pixel (Working distance 300 mm; typical table, lens and resolution not stated.)
Image scale / At 400 mm
0.074 mm/pixel (Working distance 400 mm; typical table, lens and resolution not stated.)
Image scale / At 600 mm
0.111 mm/pixel (Working distance 600 mm; typical table, lens and resolution not stated.)
Camera / Optional lenses
8 / 16 mm
Controller CAB L / RS485
Master / Slave
Image scale / At 1000 mm
0.184 mm/pixel (Working distance 1000 mm; typical table, lens and resolution not stated.)
Image scale / At 1500 mm
0.275 mm/pixel (Working distance 1500 mm; typical table, lens and resolution not stated.)
Joint protection / J5/J6
IP67
Tool / Maximum TCP speed
4 m/s
Vision / Vision software
Integrated with the robot
Arm / Typical consumption
500 W
Controller CAB H / Supply
100–240 V AC, 50–60 Hz (Alternative in the selection table; not an extra supplied cabinet.)
Controller CAB H / Weight
13 kg (Alternative in the selection table; not an extra supplied cabinet.)
Controller CAB L / Supply
100–240 V AC, 50–60 Hz
Controller CAB L / Weight
11.5 kg
Camera / Camera protection
IP65
Controller OEM-AC / Supply
100–240 V AC, 50–60 Hz (Alternative in the selection table; not an extra supplied cabinet.)
Controller OEM-AC / Weight
4.8 kg (Alternative in the selection table; not an extra supplied cabinet.)
Controller OEM-DC / Supply
32–58 V DC (Alternative in the selection table; not an extra supplied cabinet.)
Controller OEM-DC / Weight
3.4 kg (Alternative in the selection table; not an extra supplied cabinet.)
Joints / J1: maximum speed
150 °/s
Joints / J2: maximum speed
150 °/s
Joints / J3: maximum speed
210 °/s
Joints / J4: maximum speed
210 °/s
Joints / J5: maximum speed
210 °/s
Joints / J6: maximum speed
210 °/s
Camera / Maximum frame rate
45 fps
Controller CAB H / Mounting
Floor-standing / wall-mounted (Alternative in the selection table; not an extra supplied cabinet.)
Controller CAB L / Ethernet
2 Gigabit ports
Controller CAB L / Mounting
Floor-standing / wall-mounted
Field of view / 80 mm: H×V
55×41 mm (Working distance 80 mm; typical table, lens and resolution not stated.)
Arm / Weight including cable
41 kg
Controller CAB L / Protocols
TCP/IP, EtherCAT Master, EtherNet/IP Slave, PROFINET Slave
Controller OEM-AC / Mounting
Rail / floor / ear-mounted (Alternative in the selection table; not an extra supplied cabinet.)
Controller OEM-DC / Mounting
Rail / floor / ear-mounted (Alternative in the selection table; not an extra supplied cabinet.)
Field of view / 150 mm: H×V
99×75 mm (Working distance 150 mm; typical table, lens and resolution not stated.)
Field of view / 230 mm: H×V
149×113 mm (Working distance 230 mm; typical table, lens and resolution not stated.)
Field of view / 300 mm: H×V
194×146 mm (Working distance 300 mm; typical table, lens and resolution not stated.)
Field of view / 400 mm: H×V
257×194 mm (Working distance 400 mm; typical table, lens and resolution not stated.)
Field of view / 600 mm: H×V
383×290 mm (Working distance 600 mm; typical table, lens and resolution not stated.)
Field of view / 800 mm: H×V
514×388 mm (Working distance 800 mm; camera diagram, lens and resolution not stated.)
Controller CAB H / Protection
IP54 (Alternative in the selection table; not an extra supplied cabinet.)
Controller CAB L / Protection
IP54
Field of view / 1000 mm: H×V
635×481 mm (Working distance 1000 mm; typical table, lens and resolution not stated.)
Field of view / 1500 mm: H×V
951×720 mm (Working distance 1500 mm; typical table, lens and resolution not stated.)
Camera / Switchable resolution
2400×2000 pixels
Controller OEM-AC / Protection
IP20 (Alternative in the selection table; not an extra supplied cabinet.)
Controller OEM-DC / Protection
IP20 (Alternative in the selection table; not an extra supplied cabinet.)
Controller CAB L / Digital inputs
16 DI, NPN/PNP
Controller CAB L / Digital outputs
16 DO, NPN/PNP
Controller CAB H / Dimensions W×H×D
422×350×236 (Units are not stated in the table. Alternative in the selection table; not an extra supplied cabinet.)
Controller CAB L / Dimensions W×H×D
422×350×236 (Units are not stated in the table.)
Controller CAB L / Configurable inputs
16 CI; default safety mode, PNP
Controller CAB L / External I/O supply
24 V, 5 A
Controller CAB L / Internal I/O supply
24 V, 3 A
Controller OEM-AC / Dimensions W×H×D
422×197×136 (Units are not stated in the table. Alternative in the selection table; not an extra supplied cabinet.)
Controller OEM-DC / Dimensions W×H×D
422×197×136 (Units are not stated in the table. Alternative in the selection table; not an extra supplied cabinet.)
Controller CAB L / Configurable outputs
16 CO; default safety mode, PNP
Controller CAB H / Operating temperature
0–50 °C (Alternative in the selection table; not an extra supplied cabinet.)
Controller CAB L / Operating temperature
0–50 °C
Controller OEM-AC / Operating temperature
0–50 °C (Alternative in the selection table; not an extra supplied cabinet.)
Controller OEM-DC / Operating temperature
0–50 °C (Alternative in the selection table; not an extra supplied cabinet.)
Controller CAB L / Communication expansions
PROFINET Master, CC-Link Slave, Powerlink Master, E/P Master, EtherCAT Slave (Optional expansions.)