Category
Collaborative Robots and Manipulators
Tool / RS485
2 channels (Multiplexed with DO1/DO2 and AI1/AI2; not additional independent I/O.)
Model / Model
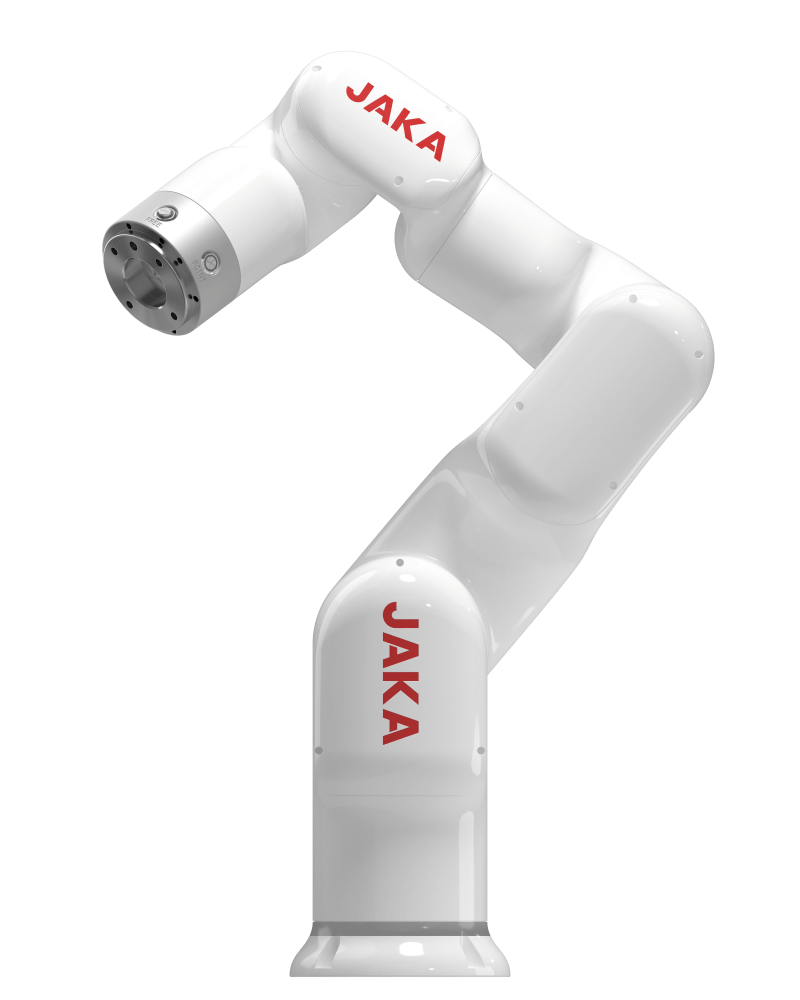
JAKA MiniCobo
Arm / Mounting
Any orientation
Arm / Materials
Aluminium alloy, PC
Arm / Programming
Graphical, hand-guided
MiniCab IPC / CPU
Intel Celeron J1900, 1.99 GHz
MiniCab IPC / RAM
DDR3L 2G (Manufacturer capacity notation.)
MiniCab IPC / USB
1×USB 3.0, 1×USB 2.0 (Internal debugging only; use requires contacting JAKA technicians.)
Tool / I/O supply
12/24 V DC (Switchable in the App; the current product table specifies 24 V mode.)
MiniCab IPC / HDMI
1 port (Internal debugging only; use requires contacting JAKA technicians.)
Arm / Base diameter
12.4 cm
Arm / Rated payload
1 kg (Permitted load depends on centre-of-gravity offset from the flange.)
Arm / Repeatability
±0.1 mm
MiniCab IPC / Drive
64G (Drive technology is not specified.)
Complete set / Robot
1 pc (When purchasing a complete set.)
Arm / Body protection
IP40
Power adapter / Model
GST280A24-C6P, MW
Tool / Digital inputs
2 channels
Arm / Operator devices
PC, tablet, smartphone
Tool / Analogue inputs
2 channels
Tool / Digital outputs
2 channels
Cables / Outer diameter
7.1 mm
Flange / Maximum torque
14 N·m
Power / Separate inputs
Cabinet VL+, robot VP+ (VP+ can also power the cabinet; separate robot power disconnection is supported.)
Safety / Function scope
JAKA App ≥1.7 (Version 1.5 supports only some functions; a risk assessment of the complete cell is required.)
Arm / Operating humidity
0–90 % RH (Non-condensing.)
Robot power / Peak power
280 W (Load and application dependent; maximum, not average consumption.)
Tool / Typical TCP speed
1 m/s
Arm / Average consumption
150 W
Controller MiniCab / LAN1
10/100 Mbit/s
Controller MiniCab / LAN2
10/100/1000 Mbit/s
Tool / Digital input mode
Sink / Source (Configurable in the App.)
Tool / Maximum DO current
1 A
Controller MiniCab / Model
MiniCab
Controller MiniCab / RS485
Master / Slave (Two external-device interfaces: master and slave.)
Operation / Flange buttons
Free / Point (Hand-guided movement and recording a point in the App program.)
Storage / Storage humidity
20–85 % RH (Avoid condensation.)
Tool / Digital output mode
Sink / Source / Push-pull
Tool / Peak supply current
2 A (Peak duration is not stated.)
Arm / Operating temperature
0–50 °C
Controller MiniCab / Weight
1.1 kg (Cabinet itself; accessory weight is not included.)
Tool / Analogue input range
0–10 V
Cables / Control stick cable
6 m
Cables / Minimum bend radius
42.6 mm
Complete set / Control stick
1 pc (When purchasing a complete set.)
Installation / Base mounting
4×M6 (Tightening torque 15 N·m; fasteners are not stated as supplied.)
Installation / Tool mounting
4×M6, PCD 50 mm (Tightening torque 15.3 N·m.)
Arm / Weight including cables
9.4 kg
Base loads / Maximum force Fz
140 N (Rare maximum values; not reached simultaneously.)
Controller MiniCab / Mounting
Panel / guide rail (Rail mounting accessory is purchased separately.)
Power adapter / Current range
0–11.67 A
Power adapter / Rated current
11.67 A
Safety / Safety I/O: channels
I/O1–4: DI/DO; I/O6–7: DI (Paired channels; I/O6–7 for protective stop only. Configured in the App.)
Safety / Safety I/O: versions
App≥1.7.1.37; Controller≥1_7_1_36; PSCB≥03_02_PR; Servo≥R3196 (All version requirements apply together.)
Storage / Storage temperature
−10–50 °C (Avoid condensation.)
Base loads / Maximum torque Mz
90 N·m (Rare maximum values; not reached simultaneously.)
Complete set / 24 V DC adapter
1 pc (When purchasing a complete set.)
Complete set / MiniCab cabinet
1 pc (When purchasing a complete set.)
Controller MiniCab / Materials
Steel, aluminium alloy
Controller MiniCab / Protocols
TCP/IP, Modbus TCP, Modbus RTU, PROFINET, EtherNet/IP
Power adapter / Output voltage
24 V DC
Controller MiniCab / I/O supply
24 V DC (When both VP+ and VL+ are below 26 V, UDIO_24V output is below 24 V.)
Controller MiniCab / Protection
IP20
Duty cycle / Duty cycle example
8 s motion + 2 s waiting (Example 10 s cycle; exceeding 80% motion duty can reduce gearbox life.)
Power adapter / Line regulation
±1 %
Power adapter / Load regulation
±3 %
Base loads / Maximum force Fx/Fy
120 N (Rare maximum values; not reached simultaneously.)
Complete set / Quick start guide
1 pc (When purchasing a complete set.)
Controller MiniCab / Digital I/O
7 channels (Multiplexed NPN inputs/outputs; one mode per channel at a time.)
Power adapter / Voltage accuracy
±3 %
Recommended conditions / Warm-up
At ambient temperature <10 °C
Safety / External emergency stop
Dual-channel E-STOP input
Storage / Long storage: humidity
45–65 % RH (Avoid condensation.)
Tool / Continuous supply current
1 A
Base loads / Maximum torque Mx/My
100 N·m (Rare maximum values; not reached simultaneously.)
Cables / Robot cable installation
Fixed (Not suitable for a cable carrier; a flexible option requires separate agreement.)
Complete set / Cabinet power cord
1 pc (When purchasing a complete set.)
Controller MiniCab / Rated supply
24 V DC
Operation / Control stick and App
Interlocked control (An unlocked control stick prevents App control.)
Cabinet power / Maximum consumption
≤30 W
Cabinet power / Typical consumption
12 W
Operation / Control stick functions
Power, enable, start/stop, reset, pause, lock, emergency stop
Power adapter / Rated maximum power
280.08 W
Safety / Function performance level
PL d / Cat.3 (Declared for functions together with the controller; not safety certification of the complete cell.)
Safety functions / SF8: Power limit
250 ms (Response time; App ≥1.7. Cat.1 stop.)
Storage / Long storage: temperature
25±10 °C (Avoid condensation.)
Complete set / Robot connection cable
1 pc (When purchasing a complete set.)
Recommended conditions / Peak current
12 A (Peak current depends on operating state and mode.)
Safety functions / SF1: Emergency stop
250 ms (Response time; App ≥1.7. Cat.1 stop.)
Safety functions / SF3: Safeguard stop
350 ms (Response time; App ≥1.7. Cat.2 stop.)
Safety functions / SF9: TCP speed limit
250 ms (Response time; App ≥1.7. Cat.1 stop.)
Complete set / After-sales warranty card
1 pc (When purchasing a complete set.)
Controller MiniCab / Remote power on/off
Digital inputs (External momentary switch; wiring according to the manual.)
Controller MiniCab / Wireless connection
Wi-Fi 2.4 GHz
Power adapter / Maximum ripple and noise
200 mV p-p
Safety functions / SF26: TCP force limit
350 ms (Response time; App ≥1.7. Cat.2 stop.)
Safety functions / SF5: Joint speed limit
250 ms (Response time; App ≥1.7. Cat.1 stop.)
Safety functions / SF7: Joint power limit
250 ms (Response time; App ≥1.7. Cat.1 stop.)
Controller MiniCab / Operating temperature
0–50 °C
Controller MiniCab / User connector supply
24 V (Built-in 2.7 A overcurrent protection; voltage depends on input supply.)
Safety functions / SF6: Joint torque limit
250 ms (Response time; App ≥1.7. Cat.1 stop.)
Controller MiniCab / Digital output current
≤1 A
Operation / Operation without control stick
Possible with an external emergency stop
Safety functions / SF11: TCP position limit
250 ms (Response time; App ≥1.7. Cat.1 stop.)
Safety functions / SF18: Reduced mode input
250 ms (Response time; App ≥1.7. Cat.1 stop.)
Complete set / Product qualified certificate
1 pc (When purchasing a complete set.)
Recommended conditions / Maximum RMS current
8 A
Safety functions / SF22: Robot moving output
100 ms (Response time; App ≥1.7. Dual-channel low or high-impedance output.)
Recommended conditions / Recommended humidity
10–90 % RH (Non-condensing.)
Safety functions / SF14: Collision protection
350 ms (Response time; App ≥1.7. Cat.2 stop.)
Safety functions / SF4: Joint position limits
250 ms (Response time; App ≥1.7. Cat.1 stop.)
Safety functions / SF17: Safeguard reset input
350 ms (Response time; App ≥1.7. Cat.2 stop.)
Safety functions / SF10: Tool orientation limit
250 ms (Response time; App ≥1.7. Cat.1 stop.)
Safety functions / SF2: External emergency stop
250 ms (Response time; App ≥1.7. Cat.1 stop.)
Recommended conditions / Recommended robot supply
>20–30 V DC
Safety functions / SF23: Robot not stopping output
100 ms (Response time; App ≥1.7. Dual-channel low or high-impedance output.)
Safety functions / SF24: Robot reduced mode output
250 ms (Response time; App ≥1.7. Dual-channel low or high-impedance output.)
Recommended conditions / Altitude in typical column
1000 m (In the recommended-conditions table; an altitude limit is not specified.)
Safety functions / SF12: TCP position mismatch limit
250 ms (Response time; App ≥1.7. Cat.1 stop.)
Safety functions / SF13: Hand-guided TCP speed limit
350 ms (Response time; App ≥1.7. Cat.2 stop.)
Safety functions / SF27: Three-position enable input
350 ms (Response time; App ≥1.7. Cat.2 stop.)
Recommended conditions / Typical atmospheric pressure
1 bar
Safety functions / SF21: System safeguard state output
350 ms (Response time; App ≥1.7. Dual-channel low or high-impedance output.)
Safety functions / SF15: Additional emergency stop input
250 ms (Response time; App ≥1.7. Cat.1 stop.)
Safety functions / SF16: Additional safeguard stop input
350 ms (Response time; App ≥1.7. Cat.2 stop.)
Safety functions / SF25: Robot not in reduced mode output
250 ms (Response time; App ≥1.7. Dual-channel low or high-impedance output.)
Safety functions / SF19: Emergency stop button state output
250 ms (Response time; App ≥1.7. Dual-channel low or high-impedance output.)
Safety functions / SF20: System emergency stop state output
250 ms (Response time; App ≥1.7. Dual-channel low or high-impedance output.)