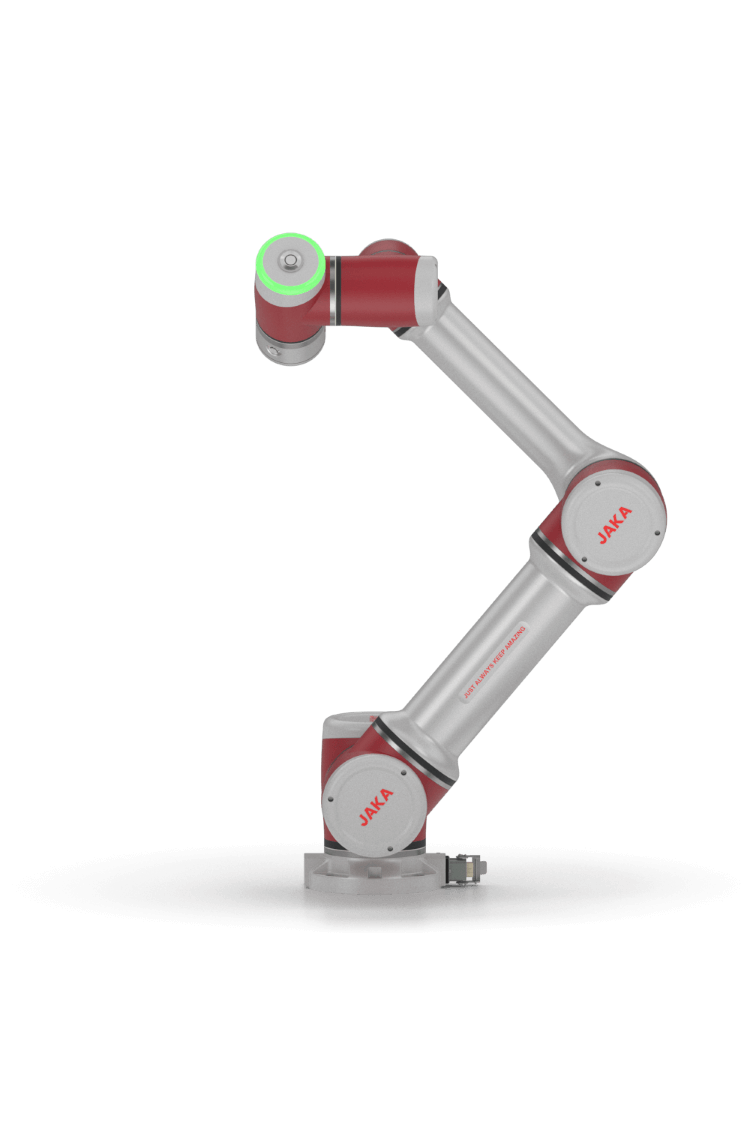
Category
Collaborative Robots and Manipulators
Arm / Mounting
Any orientation
Arm / Materials
Aluminium, PC
Arm / Programming
Graphical and freedrive programming
Tool / I/O supply
12/24 V DC
Arm / Base diameter
15.8 cm
Arm / Base mounting
M8×4 (Mounting-point designation; not supplied fasteners.)
Arm / Repeatability
±0.02 mm
Tool / Digital inputs
2 channels
Arm / Operator devices
PC, tablet, smartphone
Tool / Analogue inputs
2 channels
Tool / Digital outputs
2 channels
Control cabinet / Model
CAB 7
Applications / Processes
Assembly, screwdriving, adhesive application, surface finishing (With the appropriate gripper or process tool.)
Joint motion / J1: range
±360 °
Joint motion / J1: speed
180 °/s
Joint motion / J2: range
−85…+265 °
Joint motion / J2: speed
180 °/s
Joint motion / J3: range
±175 °
Joint motion / J3: speed
180 °/s
Joint motion / J4: range
−85…+265 °
Joint motion / J4: speed
180 °/s
Joint motion / J5: range
±360 °
Joint motion / J5: speed
180 °/s
Joint motion / J6: range
±360 °
Joint motion / J6: speed
180 °/s
Arm / Declared compliance
CR, CE, 15066 (Manufacturer declaration; the supplied conformity documents are not specified.)
Force Fx/Fy/Fz / Overload
3000 N
Control cabinet / Material
Powder-coated carbon steel
Torque Mx/My/Mz / Overload
300 N·m
Force Fx/Fy/Fz / Resolution
0.1 N
Arm / Weight including cable
23 kg
Control cabinet / I/O supply
24 V DC
Torque Mx/My/Mz / Resolution
0.1 N·m
Arm / Collaborative operation
According to GB 11291.1-2011 (As stated by the manufacturer.)
Arm / Connection cable length
6 m
Control cabinet / Digital I/O
16 channels (Inputs and outputs are listed together; the allocation is not specified in this row.)
Control cabinet / Analogue I/O
2 channels (Inputs or outputs.)
Control cabinet / Input supply
100–240 V AC, 50–60 Hz
Control cabinet / Communication
TCP/IP, Modbus TCP, Modbus RTU
Force sensing / Embedded sensor
Three-axis forces and torques
Tool motion / Maximum TCP speed
3 m/s
Control cabinet / Cabinet weight
15.4 kg
Force Fx/Fy/Fz / Measurement range
200 N
Torque Mx/My/Mz / Measurement range
24 N·m
Control cabinet / Cabinet protection
IP44
Control cabinet / Dimensions W×H×D
41×30.7×23.5 (Own table: 410×307×235 mm (W×H×D).) cm
Force Fx/Fy/Fz / Combined system accuracy
1 % F.S. (Typical combined system error, including sensor and arm absolute positioning. F.S. means full scale.)
Torque Mx/My/Mz / Combined system accuracy
1 % F.S. (Typical combined system error, including sensor and arm absolute positioning. F.S. means full scale.)