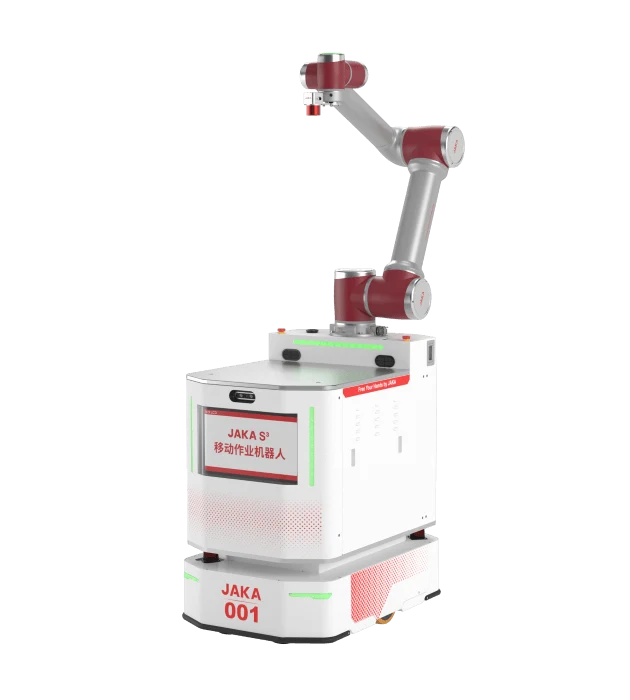
Category
Wheeled Robots and AMRs
Interfaces / I/O
Expandable for customer requirements
System / Runtime
≥8 h (Factory test; depends on route, cycle, temperature and load)
Environment / Air
Free of dust and flammable, explosive or corrosive gases
Controls / Buttons
Start, reset, pause, unlock; 2 spare buttons and 2 indicators
System / Protocols
TCP/IP, RS485, Modbus TCP
Camera / Resolution
2592 × 1944
Battery / Cycle life
1500 cycles; DOD ≥80% (0.5C charge, 1C discharge, room temperature; charging at SOC ≥15% recommended)
Chassis / Navigation
Laser SLAM (Standard configuration)
System / Programming
JAKA Cobo π; integrated JAKA software
Camera / Focal length
8 mm; optional 16 mm
Controls / Indicators
At four body corners (Standard equipment)
Camera / Field of view
>70 × 50 mm at 8 mm; >35 × 25 mm at 16 mm
Chassis / Drive layout
Two-wheel differential drive; forward/reverse and on-the-spot rotation
Controls / Touchscreen
7 inches (Standard equipment)
Environment / Humidity
5–95%, non-condensing
Environment / Location
Indoors
Origin / Brand country
China
Battery / Dual batteries
2 × 51.2 V, 27.6 Ah; LiFePO4 (Optional: upper module, with JAKA battery swapping cabinet)
Camera / Object distance
100–1000 mm (200–300 mm recommended)
Chassis / Floor flatness
3 mm/m
Protection / Safety edge
360° perimeter (Standard equipment)
Chassis / Turning passage
At least 1200 mm
Battery / Charging methods
Uninterrupted swapping; manual ≤10 A; automatic ≤20 A
Battery / Standard battery
51.2 V, 50.6 Ah; LiFePO4 (Single battery installed in the AGV base)
Chassis / Turning diameter
1000 mm
System / Body carried load
≤95 kg
Chassis / Chassis gap width
≤30 mm
Chassis / Precision docking
±5 mm (With optional two-dimensional-code-assisted positioning)
Manipulator / Arm TCP speed
≤1.8 m/s (Specifications for a JAKA12kg-rated arm; other arm configurations require separate selection)
System / Automatic charging
1.5 h, single battery from 15 to 95%
Controls / Voice annunciator
Standard equipment
Environment / Floor material
Concrete or epoxy flooring (Other flooring requires manufacturer confirmation)
Manipulator / Working radius
≤1327 mm (Specifications for a JAKA12kg-rated arm; other arm configurations require separate selection)
Chassis / Stop angle accuracy
±1°
Controls / Additional display
15.6 inches (Optional B: JAKA application for status display)
Environment / Floor condition
Dry and oil-free
Manipulator / Arm-end payload
≤12 kg, including tooling (Specifications for a JAKA12kg-rated arm; other arm configurations require separate selection)
System / Weight including arm
Approximately 402.5 kg
Manipulator / Manipulator axes
6
Chassis / Wireless connectivity
Wi-Fi802.11a/b/g/n; optional5G n28,n41,n78,n79
Chassis / Repeated stop accuracy
±10 mm (Static environment; repeated body stop position)
Pneumatics / Pneumatic interface
8 × Φ6; compressor 5 L / 48 V / 360 W (Optional B integrated pneumatic module for pneumatic tooling)
Battery / Automatic battery hatch
Optional (B configuration with dual batteries)
Chassis / Chassis obstacle height
≤10 mm
Chassis / Straight travel passage
At least 820 mm
Protection / Front and rear LiDAR
Diagonal layout, 270° (Standard equipment)
Environment / Operating temperature
0–50 °C
Protection / Emergency stop buttons
4: two on the upper module and two on the chassis (Standard equipment)
Chassis / Body dimensions L × W × H
950 × 620 × 975 mm; excluding arm, tolerance ±2 mm
Protection / Vision obstacle avoidance
0.2–1.0 m; H79° / V55° / D88.5° ±3° (Optional: front, low and overhanging object detection)
System / Combined positioning accuracy
±0.5 mm (With JAKA two-dimensional vision; not guaranteed with other vision or third-party components)
Chassis / Chassis speed and acceleration
≤1.5 m/s and ≤0.3 m/s²; 0.8 m/s recommended at rated load
Environment / Floor friction coefficient
≥0.5