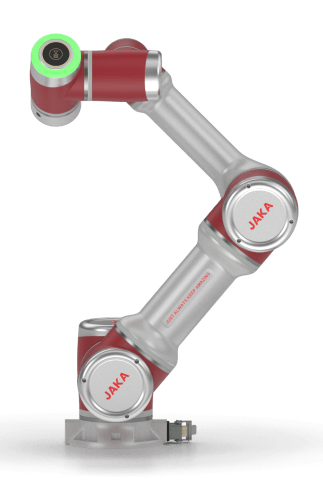
Category
Collaborative Robots and Manipulators
Zu7 arm V11 / Reach
819 mm
Zu7 arm V11 / Humidity
0…90 % RH (Non-condensing.)
Zu7 arm V11 / Mounting
Any orientation
Zu7 arm V11 / Materials
Aluminium alloy, PC
Zu7 axes V11 / J1 range
±360 °
Zu7 axes V11 / J1 speed
180 °/s
Zu7 axes V11 / J2 range
-85…+265 °
Zu7 axes V11 / J2 speed
180 °/s
Zu7 axes V11 / J3 range
±175 °
Zu7 axes V11 / J3 speed
180 °/s
Zu7 axes V11 / J4 range
-85…+265 °
Zu7 axes V11 / J4 speed
180 °/s
Zu7 axes V11 / J5 range
±360 °
Zu7 axes V11 / J5 speed
180 °/s
Zu7 axes V11 / J6 range
±360 °
Zu7 axes V11 / J6 speed
180 °/s
Tool TIO V11 / Connector
M8
Tool TIO V11 / Tool supply
12 /24 V
CAB7/CAB2.1 V11 / Protocols
TCP/IP, Modbus TCP, Modbus RTU
Zu7 arm V11 / Base diameter
158 mm
Zu7 arm V11 / Rated payload
7 kg (Allowable payload depends on the centre-of-mass offset from the flange.)
Zu7 arm V11 / Repeatability
±0.02 mm
CAB7/CAB2.1 V11 / DI/DO mode
PNP
CAB7/CAB2.1 V11 / I/O supply
24 V
Tool TIO V11 / Analog inputs
2 pcs
Zu7 arm V11 / Arm protection
IP54
Zu7 arm V11 / Flange buttons
FREE / POINT
CAB2.1 internal IPC V11 / CPU
Intel Celeron J1900 (Internal cabinet board.)
CAB2.1 internal IPC V11 / RAM
2 GB (Internal cabinet board.)
Tool TIO V11 / Digital inputs
2 pcs
Zu7 arm V11 / Cleanroom class
Class5 (ISO14644-1:2015 and ISO14644-14:2016.)
CAB7/CAB2.1 V11 / DI low level
0…11 V (With V+=24V.)
CAB7/CAB2.1 V11 / Mains supply
100…240 V AC
CAB7/CAB2.1 V11 / P10 Ethernet
Three-position enabling device network interface
Tool TIO V11 / Digital outputs
2 pcs
Tool TIO V11 / Serial channels
2 × RS-485 (TIO3.0; multiplexed with digital outputs and analog inputs.)
Zu7 arm V11 / Base programming
Graphical programming and drag teaching
Zu7 arm V11 / Handheld control
Emergency stop; power; enabling; start/stop; reset; pause/resume; lock
Zu7 arm V11 / Storage humidity
20…85 % RH (Avoid condensation and mould.)
CAB7/CAB2.1 V11 / DI high level
15…30 V (With V+=24V.)
CAB7/CAB2.1 V11 / Safety inputs
EI1/EI2, SI1/SI2 (Dual-channel emergency and protective stop.)
Tool TIO V11 / TIO cable length
400 mm
Zu7 arm V11 / Maximum TCP speed
2.5 m/s
CAB7/CAB2.1 V11 / Cabinet weight
15.4 kg
CAB7/CAB2.1 V11 / Compatible arm
JAKA Zu7
CAB7/CAB2.1 V11 / Digital inputs
16 pcs
Zu7 arm V11 / Degrees of freedom
6 DOF
CAB2.1 internal IPC V11 / Storage
64 GB (Internal cabinet board.)
CAB7/CAB2.1 V11 / Digital outputs
16 pcs
CAB7/CAB2.1 V11 / Internal USB P9
USB3.0 (Internal debugging, not an external user port.)
CAB7/CAB2.1 V11 / Mains frequency
50…60 Hz
Tool TIO V11 / Analog input range
0…10 V (TIO3.0.)
Zu7 arm V11 / Ambient temperature
0…50 °C (Preheat before use below10°C.)
Zu7 arm V11 / Storage temperature
-10…50 °C
CAB7/CAB2.1 V11 / Cabinet material
Powder-coated carbon steel
CAB7/CAB2.1 V11 / High-speed input
P6: conveyor encoder
CAB7/CAB2.1 V11 / P5 analog supply
5 V (100mA maximum.)
CAB7/CAB2.1 V11 / Safety I/O pairs
DI1+DI9 …DI8+DI16; DO1+DO9 …DO8+DO16 (Dual-channel configuration.)
CAB7/CAB2.1 V11 / Serial interface
RS-485, P7
Tool TIO V11 / Digital input modes
PNP / NPN (TIO3.0.)
Tool TIO V11 / Peak supply current
2 A (TIO3.0.)
Zu7 arm V11 / Button and indicator
Pause/resume; ring-shaped status indicator
Zu7 arm V11 / Programming terminal
PC, tablet or smartphone
CAB2.1 internal IPC V11 / Board VGA
1 pcs (Internal cabinet board.)
CAB7/CAB2.1 V11 / P6 encoder supply
5 V (100mA maximum.)
Tool TIO V11 / Digital output modes
PNP / NPN / push-pull (TIO3.0.)
Zu7 installation V11 / Base force X
480 N (Separate maxima cannot occur simultaneously.)
Zu7 installation V11 / Base force Y
480 N (Separate maxima cannot occur simultaneously.)
Zu7 installation V11 / Base force Z
500 N (Separate maxima cannot occur simultaneously.)
Zu7 installation V11 / Flange depth
32.5 mm
CAB2.1 internal IPC V11 / Board HDMI
1 pcs (Internal cabinet board.)
CAB7/CAB2.1 V11 / Analog I/O voltage
0…10 V
CAB7/CAB2.1 V11 / Cabinet protection
IP44
CAB7/CAB2.1 V11 / Dimensions W×D×H
410 ×235 ×307 mm
CAB7/CAB2.1 V11 / External I/O cable
<30 m (Front-panel P1–P8 wiring harnesses, table 6-14.)
CAB7/CAB2.1 V11 / External V+ supply
10…35 V (Requires the appropriate jumper configuration.)
CAB7/CAB2.1 V11 / Mains cable length
3 m
Zu7 arm V11 / Additional programming
SRCI; offline
Zu7 arm V11 / Handheld control cable
6 m
Zu7 arm V11 / Peak power consumption
2000 W
Zu7 arm V11 / Robot connection cable
6 m
Zu7 installation V11 / Base torque X
440 N·m (Separate maxima cannot occur simultaneously.)
Zu7 installation V11 / Base torque Y
440 N·m (Separate maxima cannot occur simultaneously.)
Zu7 installation V11 / Base torque Z
400 N·m (Separate maxima cannot occur simultaneously.)
CAB2.1 internal IPC V11 / Memory type
DDR3L (Internal cabinet board.)
CAB7/CAB2.1 V11 / Cabinet temperature
0…50 °C
CAB7/CAB2.1 V11 / Industrial networks
PROFINET, Ethernet/IP (With JAKA App1.7.)
Tool TIO V11 / Digital output current
≤1 A (TIO3.0.)
Zu7 arm V11 / Collaborative operation
GB11291.1-2011 (The complete application requires a risk assessment.)
Zu7 arm V11 / Weight including cables
22 kg
Zu7 installation V11 / Base fasteners
4 ×M8
Zu7 installation V11 / Tool fasteners
4 ×M6,6mm depth
CAB2.1 internal IPC V11 / Board USB2.0
3 pcs (Internal cabinet board.)
CAB2.1 internal IPC V11 / Board USB3.0
1 pcs (Internal cabinet board.)
CAB7/CAB2.1 V11 / Analog current input
4…20 mA
CAB7/CAB2.1 V11 / Bottom Ethernet port
Gigabit; dynamic IP
CAB7/CAB2.1 V11 / Remote power control
P7: ON/OFF (5…24V signals; internal5V supply,100mA maximum.)
CAB2.1 internal IPC V11 / CPU frequency
1.99 GHz (Internal cabinet board.)
CAB7/CAB2.1 V11 / Analog current output
0…20 mA
CAB7/CAB2.1 V11 / Ventilation clearance
≥100 mm (Left, right and above.)
Zu7 arm V11 / Average power consumption
350 W
Zu7 installation V11 / Tool bolt circle
50 mm
CAB2.1 internal IPC V11 / Board Ethernet
2 pcs (Internal cabinet board.)
Tool TIO V11 / Continuous supply current
1 A (TIO3.0.)
Zu7 arm V11 / Long-term storage humidity
45…65 % RH (Recommended range.)
CAB7/CAB2.1 V11 / Default analog I/O mode
0…10V input
Zu7 arm V11 / EU page nominal consumption
350 W
Zu7 installation V11 / Base through holes
9 mm
Zu7 installation V11 / Tool locating hole
6 mm (Tolerance+0.012/0mm.)
Zu7 installation V11 / Base locating holes
8 mm
Zu7 installation V11 / Cable carrier speed
≤2 m/s
CAB7/CAB2.1 V11 / Internal24V total current
≤1.5 A (Internal supply;≤1A recommended.)
Zu7 arm V11 / Long-term storage temperature
25±10 °C (Recommended range.)
Zu7 installation V11 / Mounting screw grade
12.9 (Recommended grade; engagement1.5…2 nominal diameters.)
Zu7 installation V11 / Robot cable diameter
10.2 mm
Zu7 installation V11 / Maximum flange torque
34 N·m
Zu7 installation V11 / Base tightening torque
40 N·m
CAB7/CAB2.1 V11 / Configurable analog channels
2 pcs
Zu7 installation V11 / Flange outside diameter
81 mm
CAB7/CAB2.1 V11 / Single digital output current
≤1 A
V11 system contents and connections / TIO cable
1 pcs
Zu7 installation V11 / Mounting plate thickness
≥20 mm (Steel plate recommended.)
Zu7 installation V11 / Minimum cable bend radius
81.6 mm
Zu7 installation V11 / Cable carrier acceleration
≤5 m/s²
V11 system contents and connections / Cabinet and key
1 set (V11 full system; CAB7 is the cabinet model listed for this arm.)
Zu7 installation V11 / Mounting plate torque capacity
3000 N·m
V11 system contents and connections / Handheld control
1 pcs
V11 system contents and connections / V11 cabinet WLAN
Built-in wireless module connects the operating terminal to the cabinet WLAN. (The network name is the cabinet number. An external router is an alternative connection method.)
V11 system contents and connections / Cabinet power cable
1 pcs
V11 system contents and connections / P5 / Analog grounding
Analog I/O is not galvanically isolated from the cabinet; the equipment and cabinet use a common ground.
V11 system contents and connections / P7 / Remote switching
ON and OFF inputs must not be shorted simultaneously.
V11 system contents and connections / Arm in complete system
1 pcs (V11 full-system packing list.)
V11 system contents and connections / P1–P8 wiring harness
UL1007 #20 AWG (Table 6-14, front-panel wiring; length less than 30 m.)
V11 system contents and connections / P7 / RS485 termination
120 Ω (Recommended terminating resistor; YAGEO MF0207FTE52-120R is specified.)
V11 system contents and connections / Robot connection cable
1 pcs
V11 system contents and connections / Complete-system documents
JAKA certificate, warranty card and safety leaflet: 1 each. (Documents in the complete-system V11 packing list.)
V11 system contents and connections / P6 / Differential encoder
Inputs A+/A−, B+/B−, Z+/Z−; DG is isolated from internal GND.
V11 system contents and connections / TIO3.0 supply configuration
12/24 V; the supply can be enabled or disabled through configuration.
V11 system contents and connections / Default V11 cabinet generation
CAB2.1 (V11 states CAB2.1 is the default; MiniCab has a separate manual.)