Category
Wheeled Robots and AMRs
TRON 2 EDU / Specifications / SDK
√
TRON 2 EDU / Specifications / Sole
- Overall width: 453 mm - Standing height: 987 mm
TRON 2 EDU / Operation / Robot Wi-Fi
Robot Wi-Fi supports computer and VR-device connection
TRON 2 EDU / Specifications / Material
Aluminum alloy, plastic
TRON 2 / Optional kits / Perception kit
3D mapping, localization and navigation indoors and outdoors, including multi-floor environments (Optional configuration; confirm its contents separately.)
TRON 2 EDU / Specifications / Dual-Arms
- Shoulder width: 447 mm - Arm length: 730 mm (without gripper)
TRON 2 / Optional kits / Auto-recharging
Available as a configuration extension; not automatically included in the base set (Optional configuration; confirm its contents separately.)
TRON 2 EDU / Specifications / RS485 Port
√ (1 port)
TRON 2 EDU / Tri-form set packing / Body
1 unit(s) (EDU tri-form set, illustrated packing list.)
TRON 2 EDU / Operation / Operating ground
Flat ground with high friction; caution on smooth surfaces
TRON 2 EDU / Operation / Battery / storage
Charge to 50–60% before storage; recharge to that range every 3 months
TRON 2 EDU / Operation / Outdoor operation
Outdoor use prohibited in heavy fog, rain, snow or thunderstorms
TRON 2 EDU / Operation / Remote / charging
Type-C cable connects to remote controller
TRON 2 EDU / Specifications / Battery Type
Ternary lithium battery
TRON 2 EDU / Specifications / USB 3.0 Port
√ (1 port)
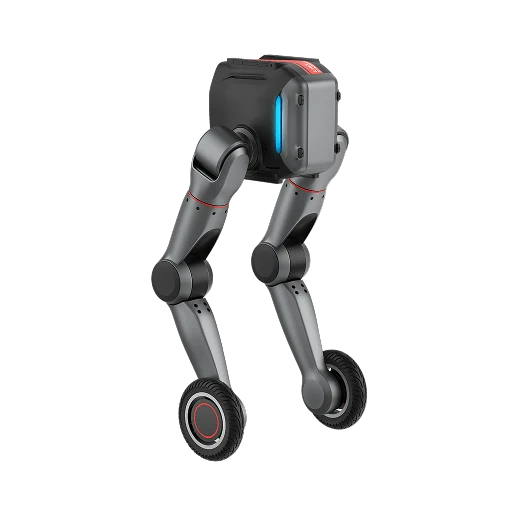
TRON 2 EDU / Specifications / Wheeled-legs
- Overall width: 478 mm - Standing height: 1015 mm
TRON 2 EDU / Specifications / Charging Time
20-80% Charge: 30min ; 20-100% Charge: 54min
TRON 2 EDU / Specifications / Data Platform
√
TRON 2 EDU / Specifications / EtherCAT Port
√ (2 port)
TRON 2 EDU / Specifications / Ethernet Port
√ (1 port)
TRON 2 EDU / Tri-form set packing / Battery
1 unit(s) (EDU tri-form set, illustrated packing list.)
Dual arms / Joints / Joint 3 / elbow_L_Joint
-150…15°; -2.61…0.26 rad (Relative to zero position.)
TRON 2 EDU / Operation / Operating clearance
At least 1 m from obstacles, people and water surfaces; keep robot in sight
TRON 2 EDU / Specifications / Charging Power
542W
Dual arms / Joints / Joint 10 / elbow_R_Joint
-150…15°; -2.61…0.26 rad (Relative to zero position.)
TRON 2 EDU / Tri-form set packing / VR device
1 unit(s) (EDU tri-form set, illustrated packing list.)
Dual arms / Joints / Joint 15 / head_yaw_Joint
-90…90°; -1.57…1.57 rad (Relative to zero position.)
TRON 2 / Mobile dual-arms option / Mobile base
1 unit (Mobile dual-arms version only; not automatically included in the base tri-form set.)
TRON 2 EDU / Operation / Operating temperature
-5…40 °C
TRON 2 EDU / Ports and components / Body / USB
USB-A 3.0
TRON 2 EDU / Specifications / Battery Capacity
9Ah
TRON 2 EDU / Specifications / Head RGBD Camera
✓ (only for Dual-Arms / Mobile Dual-Arms )
TRON 2 EDU / Tri-form set packing / Fixed base
1 unit(s) (EDU tri-form set, illustrated packing list.)
TRON 2 / Mobile dual-arms option / Mobile stand
1 unit (Mobile dual-arms version only; not automatically included in the base tri-form set.)
TRON 2 EDU / Specifications / Waist RGBD Camera
√
TRON 2 EDU / Specifications / Wrist RGBD Camera
✓ (only for Dual-Arms / Mobile Dual-Arms)
TRON 2 EDU / Tri-form set packing / Certificate
1 unit(s) (EDU tri-form set, illustrated packing list.)
TRON 2 EDU / Tri-form set packing / Fixed stand
1 unit(s) (EDU tri-form set, illustrated packing list.)
TRON 2 EDU / Tri-form set packing / Head camera
1 unit(s) (EDU tri-form set, illustrated packing list.)
TRON 2 EDU / Tri-form set packing / User manual
1 unit(s) (EDU tri-form set, illustrated packing list.)
Dual arms / Joints / Joint 14 / head_pitch_Joint
-45…60°; -0.78…1.04 rad (Relative to zero position.)
Dual arms / Joints / Joint 4 / wrist_yaw_L_Joint
-100…80°; -1.74…1.39 rad (Relative to zero position.)
TRON 2 / Mobile dual-arms option / Base tool kit
1 unit (Mobile dual-arms version only; not automatically included in the base tri-form set.)
TRON 2 / Optional kits / Mobile manipulation kit
Working height up to 1.5 m; integrated arm-leg coordination (Optional configuration; confirm its contents separately.)
TRON 2 EDU / Architecture and development / URDF
URDF description for simulation-to-real development (EDU hardware/software configuration; verify feature availability against the version.)
TRON 2 EDU / Operation / Locomotion-form testing
Use a tether during remote control and early development testing
TRON 2 EDU / Specifications / Degrees of Freedom
Single arm: 7 DOF; single leg: 5 DOF; head: 2 DOF
TRON 2 EDU / Specifications / Top Expansion Area
Width: 146 mm; depth: 170 mm
TRON 2 EDU / Tri-form set packing / Leg tool kit
1 unit(s) (EDU tri-form set, illustrated packing list.)
Dual arms / Joints / Joint 11 / wrist_yaw_R_Joint
-80…100°; -1.39…1.74 rad (Relative to zero position.)
Dual arms / Joints / Joint 6 / wrist_roll_L_Joint
-90…90°; -1.57…1.57 rad (Relative to zero position.)
TRON 2 / Mobile dual-arms option / Stand tool kit
1 unit (Mobile dual-arms version only; not automatically included in the base tri-form set.)
TRON 2 EDU / Operation / Environmental protection
Not waterproof or dustproof; avoid humid, sandy or dusty environments
TRON 2 EDU / Specifications / Simulation Platform
√
TRON 2 EDU / Tri-form set packing / Body foot pad
1 unit(s) (EDU tri-form set, illustrated packing list.)
TRON 2 EDU / Tri-form set packing / Power adapter
1 unit(s) (EDU tri-form set, illustrated packing list.)
Dual arms / Joints / Joint 13 / wrist_roll_R_Joint
-90…90°; -1.57…1.57 rad (Relative to zero position.)
Dual arms / Joints / Joint 5 / wrist_pitch_L_Joint
-45…45°; -0.78…0.78 rad (Relative to zero position.)
TRON 2 EDU / Ports and components / Body / network
Gigabit Ethernet
Dual arms / Joints / Joint 12 / wrist_pitch_R_Joint
-45…45°; -0.78…0.78 rad (Relative to zero position.)
Dual arms / Joints / Joint 2 / proximal_yaw_L_Joint
-210…85°; -3.66…1.48 rad (Relative to zero position.)
Dual arms / Joints / Joint 9 / proximal_yaw_R_Joint
-85…210°; -1.48…3.66 rad (Relative to zero position.)
TRON 2 EDU / Specifications / Maximum Battery Power
2800W
TRON 2 EDU / Specifications / Secondary Development
√
Dual arms / Joints / Joint 1 / proximal_roll_L_Joint
-15…183°; -0.26…3.22 rad (Relative to zero position.)
Dual arms / Joints / Joint 8 / proximal_roll_R_Joint
-183…15°; -3.22…0.26 rad (Relative to zero position.)
TRON 2 EDU / Specifications / 24 V Power Output Port
√ (2 port)
TRON 2 EDU / Specifications / 48 V Power Output Port
√ (1 port)
TRON 2 EDU / Specifications / Battery Output Voltage
46.8V
TRON 2 EDU / Specifications / Developer module / CPU
Intel Core Ultra
TRON 2 EDU / Specifications / Software Compatibility
Compatible with Python, C++ development environments; Supports ROS1/ROS2 systems
Dual arms / Joints / Joint 0 / proximal_pitch_L_Joint
-180…149°; -3.14…2.60 rad (Relative to zero position.)
Dual arms / Joints / Joint 7 / proximal_pitch_R_Joint
-180…149°; -3.14…2.60 rad (Relative to zero position.)
TRON 2 EDU / Ports and components / Body / indicators
Separate robot status and battery level indicators
TRON 2 EDU / Tri-form set packing / Remote controller
1 unit(s) (EDU tri-form set, illustrated packing list.)
Sole or wheeled legs / Joints / Joint 3 / knee_L_Joint
-150…15°; -2.61…0.26 rad (Relative to zero position; ankle and wheel sharing one ID are alternative forms.)
Sole or wheeled legs / Joints / Joint 8 / knee_R_Joint
-150…15°; -2.61…0.26 rad (Relative to zero position; ankle and wheel sharing one ID are alternative forms.)
TRON 2 EDU / Architecture and development / SDK access
High- and low-level interfaces (EDU hardware/software configuration; verify feature availability against the version.)
TRON 2 EDU / Architecture and development / Simulators
NVIDIA Isaac Sim, MuJoCo, Gazebo (EDU hardware/software configuration; verify feature availability against the version.)
TRON 2 EDU / Ports and components / Body / 24 V output
LCB female, stable 24 V DC; rated 5 A, maximum 20 A
TRON 2 EDU / Ports and components / Body / 48 V output
LCB female, stable 48 V DC; rated 10 A, maximum 20 A
TRON 2 EDU / Tri-form set packing / Roll-cage tool kit
1 unit(s) (EDU tri-form set, illustrated packing list.)
TRON 2 EDU / Tri-form set packing / Wheeled lower legs
2 unit(s) (EDU tri-form set, illustrated packing list.)
Sole or wheeled legs / Joints / Joint 4 / wheel_L_Joint
∞ (continuous rotation) (Relative to zero position; ankle and wheel sharing one ID are alternative forms.)
Sole or wheeled legs / Joints / Joint 9 / wheel_R_Joint
∞ (continuous rotation) (Relative to zero position; ankle and wheel sharing one ID are alternative forms.)
TRON 2 EDU / Ports and components / Peripheral mounting
Top, front and bottom platforms; all threaded holes M4
TRON 2 EDU / Specifications / Robot Management Platform
√
TRON 2 EDU / Tri-form set packing / Fixed base tool kit
1 unit(s) (EDU tri-form set, illustrated packing list.)
TRON 2 / Mobile dual-arms option / Mobile base / battery
Normal voltage range24–29.4 V; separate mobile base only
TRON 2 / Mobile dual-arms option / Mobile base / charger
10 A charger supplied with the separate mobile base
TRON 2 EDU / Architecture and development / VLA workflow
Data collection, cleaning and annotation, training, inference and task management (EDU hardware/software configuration; verify feature availability against the version.)
TRON 2 EDU / Architecture and development / Wrist design
Spherical human-like wrist design (EDU hardware/software configuration; verify feature availability against the version.)
TRON 2 EDU / Operation / Battery / low-charge indication
Low warning below 20%; critical warning below 5%
TRON 2 EDU / Specifications / External Power Supply Port
√ (1 port)
TRON 2 EDU / Tri-form set packing / Flight case tool kit
1 unit(s) (EDU tri-form set, illustrated packing list.)
TRON 2 EDU / Tri-form set packing / Rear roll-cage frame
1 unit(s) (EDU tri-form set, illustrated packing list.)
TRON 2 / Mobile dual-arms option / AC 220 V power charger
1 unit (Mobile dual-arms version only; not automatically included in the base tri-form set.)
TRON 2 EDU / Operation / Published performance conditions
LimX laboratory data; actual performance depends on environment, usage, device condition and software version
TRON 2 EDU / Ports and components / Body / emergency stop
Button enters torque-off mode and cuts motor power
TRON 2 EDU / Tri-form set packing / Battery charging dock
1 unit(s) (EDU tri-form set, illustrated packing list.)
TRON 2 EDU / Tri-form set packing / Front roll-cage frame
1 unit(s) (EDU tri-form set, illustrated packing list.)
TRON 2 / Mobile dual-arms option / 4-pin male aviation plug
1 unit (Mobile dual-arms version only; not automatically included in the base tri-form set.)
TRON 2 EDU / Specifications / Developer module / Interfaces
3 x ETH ports, 3 x USB 3.0, 1 x 24 V input power, 1 x 12 V output power
TRON 2 EDU / Specifications / Dual arms / End-Effector Type
Gripper \ Dexterous hand
TRON 2 EDU / Specifications / Dual-Arm Teleoperation Method
VR device (PICO 4 Ultra)
TRON 2 EDU / Tri-form set packing / Wrist camera data cable
2 unit(s) (EDU tri-form set, illustrated packing list.)
TRON 2 / Mobile dual-arms option / Certificate of conformity
1 unit (Mobile dual-arms version only; not automatically included in the base tri-form set.)
TRON 2 EDU / Ports and components / Arm adapter / pin 5 XT30
48 V power supply
TRON 2 EDU / Specifications / Charging Input Voltage/Current
100~240V/8A
TRON 2 EDU / Specifications / IMU(Inertial Measurement Unit)
√
TRON 2 EDU / Specifications / Sole/Wheeled Control Functions
Four-directional Movement, Turning, Static Standing, Squatting Down In-place, Robot Height Adjustment, Stand Up After a Fall, and Ground Clearance Detection
Sole or wheeled legs / Joints / Joint 4 / ankle_pitch_L_Joint
-97…97°; -1.69…1.69 rad (Relative to zero position; ankle and wheel sharing one ID are alternative forms.)
Sole or wheeled legs / Joints / Joint 9 / ankle_pitch_R_Joint
-97…97°; -1.69…1.69 rad (Relative to zero position; ankle and wheel sharing one ID are alternative forms.)
TRON 2 EDU / Ports and components / Arm adapter / pin 1 MX3.0
Power supply positive, 24 V
TRON 2 EDU / Ports and components / Arm adapter / pin 2 MX3.0
Power supply negative, GND
TRON 2 EDU / Ports and components / Arm adapter / pin 3 MX3.0
Gripper control signal (positive logic)
TRON 2 EDU / Ports and components / Arm adapter / pin 4 MX3.0
Gripper control signal (negative logic)
TRON 2 EDU / Specifications / Charging Output Voltage/Current
54.275V/10A
TRON 2 EDU / Specifications / Dual arms / Gripper Performance
Gripping Force: 20N Maximum; Gripping Width: 85mm
TRON 2 EDU / Specifications / Dual arms / Teleoperation Delay
100ms
TRON 2 EDU / Specifications / Support for Battery Replacement
√
TRON 2 EDU / Tri-form set packing / Thigh and sole lower legs
2 unit(s) (EDU tri-form set, illustrated packing list.)
Sole or wheeled legs / Joints / Joint 2 / proximal_yaw_L_Joint
-210…85°; -3.66…1.48 rad (Relative to zero position; ankle and wheel sharing one ID are alternative forms.)
Sole or wheeled legs / Joints / Joint 7 / proximal_yaw_R_Joint
-85…210°; -1.48…3.66 rad (Relative to zero position; ankle and wheel sharing one ID are alternative forms.)
TRON 2 EDU / Ports and components / Developer module / network
Gigabit Ethernet
TRON 2 EDU / Tri-form set packing / Wrist cameras and brackets
2 unit(s) (EDU tri-form set, illustrated packing list.)
Sole or wheeled legs / Joints / Joint 1 / proximal_roll_L_Joint
-15…183°; -0.26…3.19 rad (Relative to zero position; ankle and wheel sharing one ID are alternative forms.)
Sole or wheeled legs / Joints / Joint 6 / proximal_roll_R_Joint
-183…15°; -3.19…0.26 rad (Relative to zero position; ankle and wheel sharing one ID are alternative forms.)
TRON 2 EDU / Specifications / Data Collection and Local Storage
√
Sole or wheeled legs / Joints / Joint 0 / proximal_pitch_L_Joint
-180…149°; -3.14…2.60 rad (Relative to zero position; ankle and wheel sharing one ID are alternative forms.)
Sole or wheeled legs / Joints / Joint 5 / proximal_pitch_R_Joint
-180…149°; -3.14…2.60 rad (Relative to zero position; ankle and wheel sharing one ID are alternative forms.)
TRON 2 EDU / Architecture and development / Dual-arm power design
Dual redundant power design (EDU hardware/software configuration; verify feature availability against the version.)
TRON 2 EDU / Specifications / Developer module / Storage Capacity
2TB
TRON 2 EDU / Specifications / Dual-Arm Safety Boundary Protection
√
TRON 2 EDU / Ports and components / Developer module / 12 V output
LCB female, stable 12 V DC; maximum 5 A
TRON 2 EDU / Tri-form set packing / EDU developer expansion module
1 unit(s) (EDU tri-form set, illustrated packing list.)
TRON 2 EDU / Specifications / Dual arms / Maximum End-Effector Speed
5m/s
TRON 2 EDU / Tri-form set packing / Remote controller charging cable
1 unit(s) (EDU tri-form set, illustrated packing list.)
TRON 2 EDU / Specifications / Dual arms / Repeat Positioning Accuracy
± 0.5mm
TRON 2 EDU / Tri-form set packing / Fixed-stand developer-module bracket
1 unit(s) (EDU tri-form set, illustrated packing list.)
TRON 2 EDU / Specifications / Sole and wheeled legs / Maximum Step Height
20cm
TRON 2 EDU / Specifications / Dual arms / Maximum End-Effector Acceleration
36m/s²
TRON 2 EDU / Specifications / Sole and wheeled legs / Maximum Load Capacity
30kg for flat ground walking; 20kg for stair climbing
TRON 2 EDU / Specifications / Sole and wheeled legs / Maximum Climbing Slope
Sole: 15°; wheeled: 30°
TRON 2 EDU / Specifications / Sole and wheeled legs / Maximum Movement Speed
Sole: 2-3 m/s; wheeled: 3-5 m/s