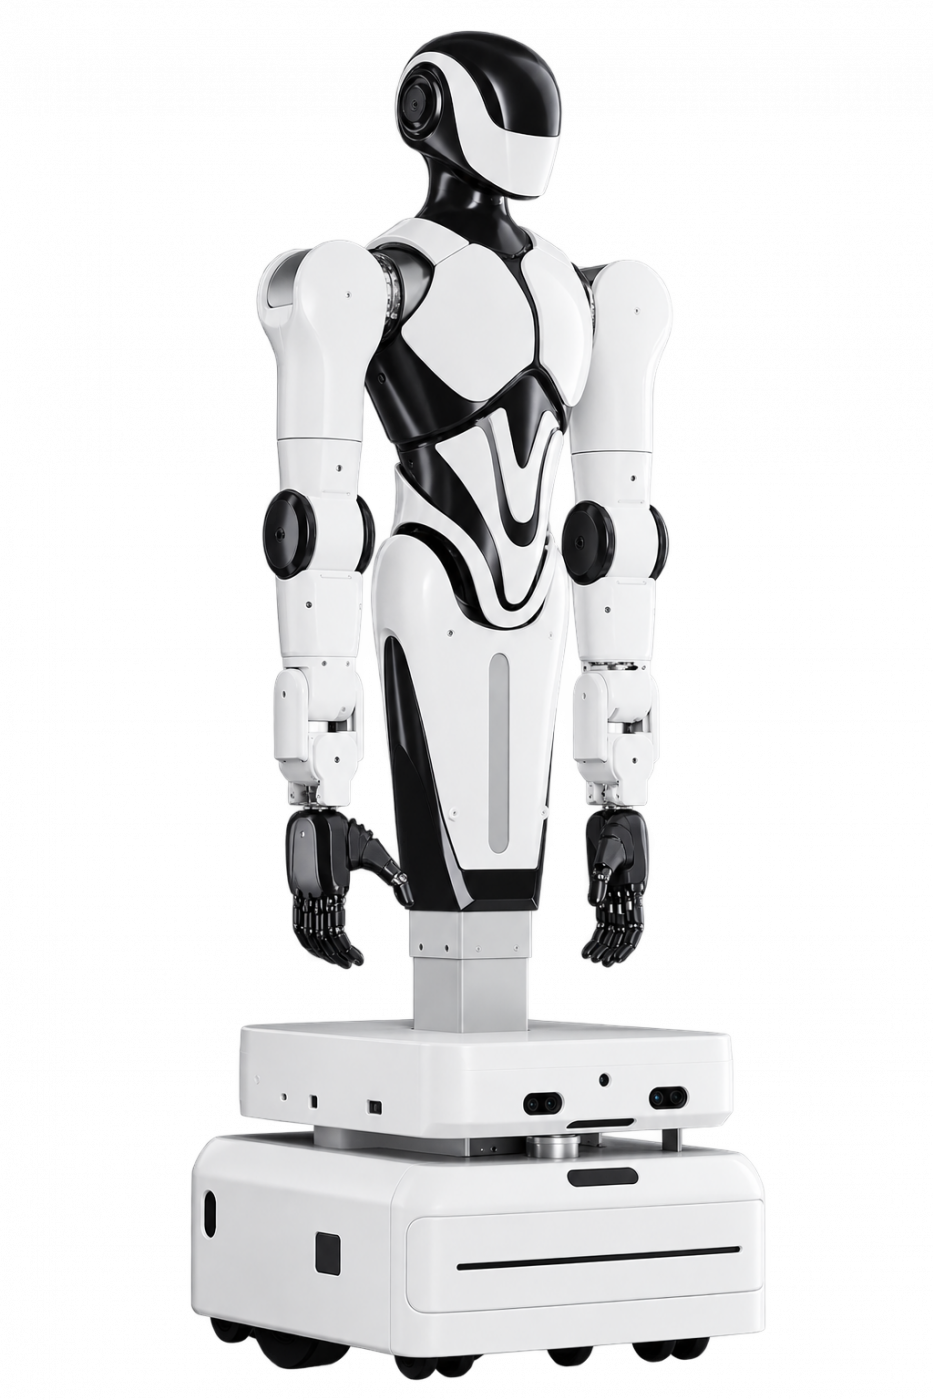
Linker Humanoid V2 / Model specifications / Model
Linker Humanoid V2
Linker Humanoid V2 / Model specifications / Height
≈1450–1950 mm
Linker Humanoid V2 / Model specifications / Weight
≈100 kg
Linker Humanoid V2 / Configuration / Parameter scope
Depend on application scenario, configuration and version
Linker Humanoid V2 / Optional mobile chassis / Drive
Two-wheel differential
Linker Humanoid V2 / Configuration / External execution
Appearance may vary with production batch and upgrades
Linker Humanoid V2 / Model specifications / Lift column
Adjustable height; customizable height setting
Linker Humanoid V2 / Model specifications / Two-arm span
≈1550 mm
Linker Humanoid V2 / Optional mobile chassis / Navigation
Autonomous route planning
Linker Humanoid V2 / Control and development / Programming
C; C++; Python
Linker Humanoid V2 / Model specifications / End-of-arm load
2 kg
Linker Humanoid V2 / Optional mobile chassis / Gradeability
10°
Linker Humanoid V2 / Model specifications / Compatible hands
All Linker Hand models
Linker Humanoid V2 / Optional mobile chassis / Chassis weight
60 kg
Linker Humanoid V2 / Control and development / Operating system
Ubuntu Linux
Linker Humanoid V2 / Optional mobile chassis / Chassis rotation
360°
Linker Humanoid V2 / Model specifications / Manipulation functions
Grasping; assembly; fine manipulation; playing instruments
Linker Humanoid V2 / Control and development / Arm and hand control
Teleoperation
Linker Humanoid V2 / Optional mobile chassis / Normal chassis speed
0.8–1.2 m/s
Linker Humanoid V2 / Control and development / Programming interface
Built-in API functions for motion control and development from a host computer
Linker Humanoid V2 / Optional mobile chassis / Chassis charging time
≤3 h
Linker Humanoid V2 / Optional mobile chassis / Maximum chassis speed
1.2 m/s
Linker Humanoid V2 / Optional mobile chassis / Chassis battery capacity
16 Ah
Linker Humanoid V2 / Optional mobile chassis / Chassis obstacle avoidance
Autonomous obstacle avoidance
Linker Humanoid V2 / Optional mobile chassis / Laser positioning accuracy
2 cm
Linker Humanoid V2 / Optional mobile chassis / Obstacle-avoidance sensors
RGB camera; infrared ranging; ultrasonic sensors
Linker Humanoid V2 / Model specifications / Degrees of freedom of two arms
2×7 DOF
Linker Humanoid V2 / Optional perception and interaction / Voice interaction
Command understanding; corresponding task execution; free question-and-answer interaction
Linker Humanoid V2 / Teleoperation master device / Master device: connectivity
Wired and wireless
Linker Humanoid V2 / Control and development / Teleoperation software framework
ROS
Linker Humanoid V2 / Optional perception and interaction / RGBD pose recognition
Standing, sitting and lying poses
Linker Humanoid V2 / Teleoperation master device / Master device: operator height
150–170 cm