← Back to Robots
Industrial Robots

MagicArm R1

Submit correction
Request a Quote

About MagicArm R1

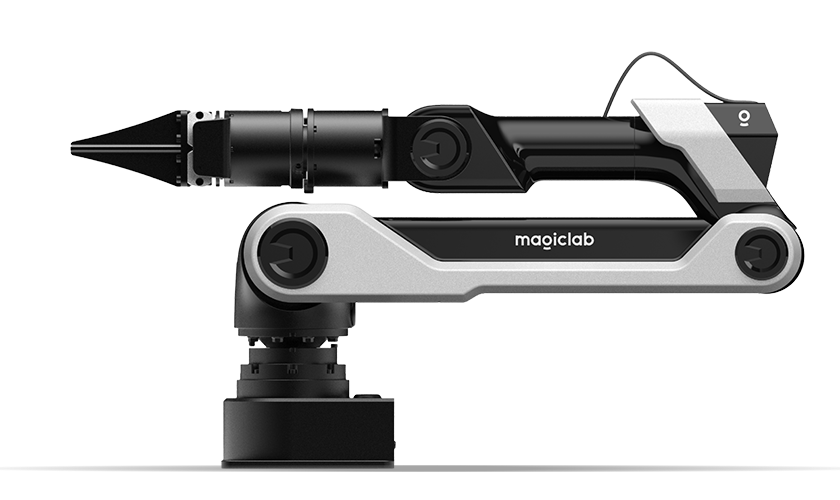
MagicArm R1 is a six-joint robotic arm for tool handling, data collection and manipulation research.


Manufacturer

🏢

MagicLab

CN

Key Specifications

Payload
4 kg
Reach
700 mm
Status
ACTIVE
Category
Industrial Robots
Data / Outputs
Force and pose
Control / Modes
Position, force control and drag-to-teach
Development / SDK
Open
Mechanics / Reach
700 mm
Control / Feedback
Real-time torque sensing at every joint
Kinematics / Model
Open; forward, inverse kinematics and batch calculation
Applications / Tasks
Transport, sorting, assembly and drag teaching
Tool / Compatibility
Grippers, dexterous hands and suction cups
Tool / Rated payload
4 kg
J6 Wrist roll / Range
±162 °
J5 Wrist pitch / Range
±95 °
Tool / Tool management
Built-in
Control / Teleoperation
Supported
J3 Forearm bend / Range
-180…0 °
Mechanics / Self weight
5.5 kg
Mounting / Orientations
Floor, wall and ceiling
J1 Base rotation / Range
±170 °
Mechanics / Forearm bend
180 °
Dynamics / Identification
Supported
J2 Upper arm lift / Range
0…+180 °
Precision / Repeatability
±0.1 mm
Development / AI toolchain
Data collection, training, deployment and evaluation
J4 Forearm rotation / Range
±153 °
J6 Wrist roll / Joint speed
180 °/s
Protection / Arm protection
IP54
Tool / Multi-tool switching
Grippers, dexterous hands and general end effectors
J5 Wrist pitch / Joint speed
180 °/s
Dynamics / Vibration settling
0.4 s (Method and operating conditions not disclosed)
J3 Forearm bend / Joint speed
180 °/s
Power supply / Supply voltage
24–48 V
J1 Base rotation / Joint speed
240 °/s
Mechanics / Degrees of freedom
6
J2 Upper arm lift / Joint speed
240 °/s
Development / Real-robot training
RL / DAgger
Development / Simulation workflow
URDF, motion and dynamics validation
J4 Forearm rotation / Joint speed
180 °/s
Teaching / Recording and playback
Drag-to-teach, trajectory recording and playback
Applications / Mounted applications
Quadruped-mounted applications
Development / General-purpose large models
Supported

Verified ecosystem

Software and resources

Official links and community projects are shown separately. Every published relationship has reviewable evidence.

0
verified official resources
0
verified compatible projects
0
public maintainers
No activity yet
latest verified ecosystem activity

Projects are ordered only within this robot ecosystem using verified compatibility, GitHub freshness and activity, and accepted community reports. This is not a global RobotSpace score.

Official resources

No first-party resource has been independently verified yet. Unverified catalog links are not shown as official.

Official software

No official software project has been verified yet.

Community projects

No verified community project has been linked yet.

Developers and contributors

No public maintainer profile is linked yet.

Verified activity

No verified project activity is available.

This ecosystem is still empty

The robot page remains useful for specifications while official resources and compatible projects are being verified.

Imported from the Unibot owner catalog · Not independently verified · Imported 2026-11-11 · Unibot source · Methodology