← Back to Robots
Humanoid

MagicBot D1

Submit correction
Request a Quote

About MagicBot D1

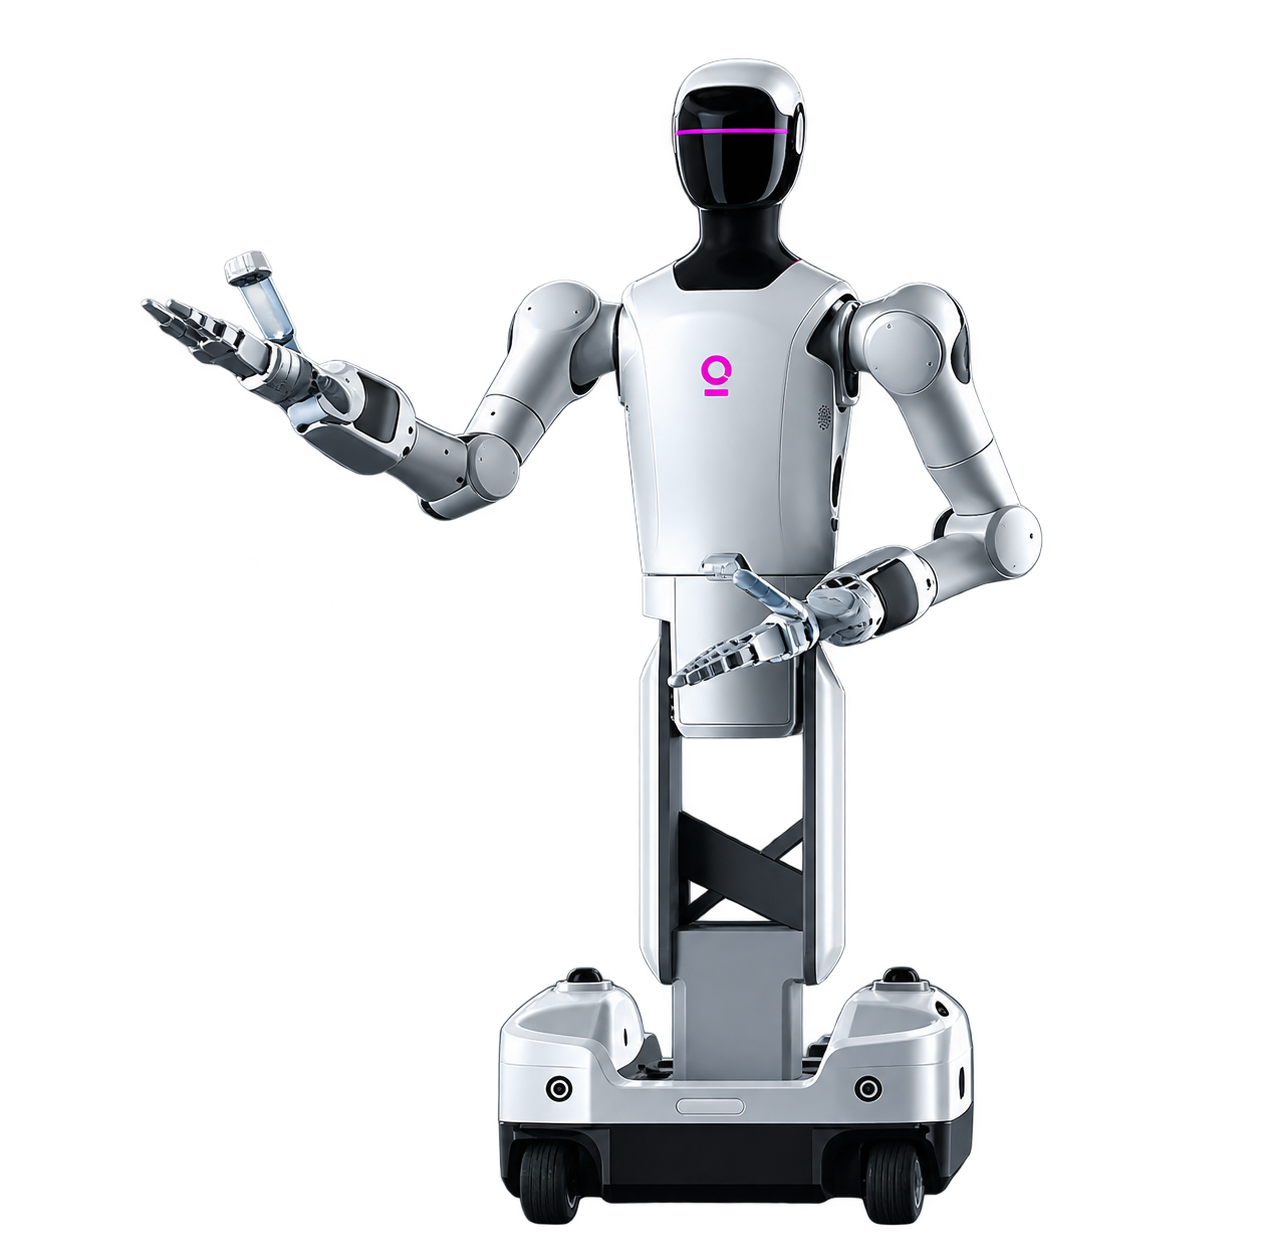
MagicBot D1n is a wheeled humanoid from MagicLab for moving materials between storage areas and production workstations.


Manufacturer

🏢

MagicLab

CN

Key Specifications

Status
ACTIVE
Category
Humanoid
Body / Weight
150 kg
Power / Runtime
4 h
Power / Batteries
2 pcs
Chassis / Mobility
Omnidirectional
Arms / Wrist design
Human-like cross-wrist
Arms / Tool changing
Quick-detachable wrist; multiple operation modules
Connectivity / Wi-Fi
Present
Kinematics / Leg axes
2 DOF
Power / Charging time
2 h
Power / Input voltage
100-240 V
Sensors / Head camera
Present
Kinematics / Neck axes
2 DOF
Chassis / Chassis speed
1.5 m/s
Kinematics / Waist axes
3 DOF
Safety / Emergency stop
Hardware button
Chassis / Turning radius
0 m
Connectivity / Bluetooth
Present
Power / Charging methods
Direct charging; hot-swappable batteries; automatic docking (Charging dock optional)
Power / Charging station
Supported (Optional)
Power / Return to charge
Automatic (With optional external charging station)
Sensors / LiDAR coverage
360 °
Body / Dimensions L×W×H
670 × 620 × 1190-1800 mm
Chassis / Steering wheels
4 pcs
Kinematics / Axes per arm
7 DOF
Kinematics / Chassis axes
4-6 DOF
Tooling / Dexterous hands
Compatible (Two-finger gripper listed as included)
Computing / Compute format
INT8
Computing / Compute rating
500 TOPS (INT8)
Safety / Main power switch
Hardware
Sensors / Chassis 3D LiDAR
2 pcs
Arms / Joint torque sensing
All joints
Interaction / Light signals
LED strip
Protection / Arm protection
IP50
Arms / Included end effector
Two-finger gripper
Arms / Maximum reach per arm
858 mm (Excluding end effector)
Connectivity / Wired network
10GE / 10 Gigabit Ethernet
Interaction / Hi-Fi speakers
2 pcs
Power / Total battery energy
1652 Wh
Sensors / Head stereo camera
1 pcs
Sensors / Ultrasonic sensors
Present (Near-field collision-avoidance warning)
Arms / Force-control accuracy
±0.5 N
Navigation / Route navigation
Point-to-point
Sensors / Wrist RGB-D cameras
2 pcs
Workflow / Fleet coordination
RCS; factory data integration
Arms / Maximum payload per arm
5 kg
Computing / Computing platform
Huawei R1
Interaction / Microphone array
Sound localization, noise reduction and echo cancellation
Power / Charger output current
15 A
Power / Charger output voltage
54.75 V
Sensors / Head fisheye cameras
3 pcs
Protection / Overall protection
IP42
Workflow / Working height range
80-230 cm
Control / VR teleoperation device
Supported (Device inclusion not specified)
Sensors / Panoramic video coverage
360 °
Development / Secondary development
Supported
Connectivity / Cellular connectivity
4G
Control / Handheld wireless terminal
Supported (Device inclusion not specified)

Verified ecosystem

Software and resources

Official links and community projects are shown separately. Every published relationship has reviewable evidence.

0
verified official resources
0
verified compatible projects
0
public maintainers
No activity yet
latest verified ecosystem activity

Projects are ordered only within this robot ecosystem using verified compatibility, GitHub freshness and activity, and accepted community reports. This is not a global RobotSpace score.

Official resources

No first-party resource has been independently verified yet. Unverified catalog links are not shown as official.

Official software

No official software project has been verified yet.

Community projects

No verified community project has been linked yet.

Developers and contributors

No public maintainer profile is linked yet.

Verified activity

No verified project activity is available.

This ecosystem is still empty

The robot page remains useful for specifications while official resources and compatible projects are being verified.

Imported from the Unibot owner catalog · Not independently verified · Imported 2026-11-11 · Unibot source · Methodology