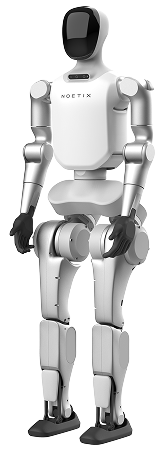
Joints / Knee
0…135 ° (General range table; SDK distinguishes right and left joints)
Joints / Hip P
-85…+50 ° (General range table; SDK distinguishes right and left joints)
Joints / Hip R
-40…+35 ° (General range table; SDK distinguishes right and left joints)
Joints / Hip Y
-40…+53 ° (General range table; SDK distinguishes right and left joints)
Joints / Waist Z
-90…+90 ° (General range table; SDK distinguishes right and left joints)
Connection / HDMI
1 port connected to RK3588S
Mechanics / Hands
Five-finger modelled hands; dexterous hands optional
Package / Charger
Provided
Operation / Stairs
Factory motion control does not support stair walking
Audio / Voice module
Language-model support
Power / Power source
Lithium battery
Sensors / SDK camera
Intel RealSense D435i
Audio / Wake distance
Up to 3 m
Connection / Ethernet
1 port
Mechanics / Arm reach
≈0.6 m
Mechanics / Waist DOF
1; optionally 1 more
Power / Battery model
GRP7865125-13S1P
Construction / Cooling
Local air cooling
Connection / USB Type-C
1 port
Dimensions / Body depth
32 cm
Documentation / Manuals
User manual and instructions
Mechanics / DOF per arm
5; optionally 2 more
Power / Battery voltage
48 V
Audio / Microphone array
Circular
Motion / Walking payload
≤5 kg (During continuous walking; laboratory data; load distribution unspecified)
Power / Battery capacity
10.6 Ah (Removable battery)
Sensors / Joint encoders
Dual
Development / Board access
Motion controller is not open to users; the EDU board is accessed through SSH
Mass / Weight with battery
≈40 kg
Mechanics / Whole-body DOF
23-28 (Depending on optional configuration)
Operation / Operating area
Level open area away from people
Package / Protective stand
Optional
Computing / EDU board clock
1.7 GHz
Development / SDK languages
C++ / Python
Development / SDK transport
DDS; CycloneDDS 0.11.0; client/server
Package / Remote controller
Provided
SDK base joints / Waist yaw
70 N·m; [-90, 90]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
Computing / EDU board memory
8 GB + 128 GB
Construction / Cable routing
Internal
Development / Control levels
HighControl and LowControl; accessed through the EDU compute board
Dimensions / Standing height
140 cm
Operation / Disabling drives
After drive disable the robot cannot balance without support
Audio / Network voice service
The cloud voice module requires network access; mobile-service terms depend on shipment activation
Computing / EDU board compute
67 TOPS
Computing / Motion controller
Rockchip RK3588S
Computing / Motion board clock
2.4 GHz
SDK base joints / Left hip yaw
90 N·m; [-40, 53]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
Computing / Motion board memory
8 GB + 64 GB
Mechanics / Maximum knee torque
150 N·m (Laboratory measurement)
SDK base joints / Left hip roll
90 N·m; [-40, 35]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
SDK base joints / Right hip yaw
90 N·m; [-53, 40]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
Audio / Voice-module microphones
6 microphones in a circular head array
Computing / Development computer
NVIDIA Jetson Orin Nano Super
Computing / Motion control board
6 TOPS
SDK base joints / Left hip pitch
150 N·m; [-85, 50]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
SDK base joints / Right hip roll
90 N·m; [-35, 40]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
Audio / Voice-module audio format
2 channels / 16 kHz / 16 bits
Connection / External XT30 output
12 V; max. 5 A
Connectivity / Internal joint bus
EtherCAT / CAN FD
Mechanics / Joint output bearings
Crossed-roller and deep-groove ball bearings
SDK base joints / Left ankle roll
70 N·m; [-90, 90]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
SDK base joints / Left knee pitch
150 N·m; [0, 135]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
SDK base joints / Right hip pitch
150 N·m; [-85, 50]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
Mechanics / Thigh and shank length
≈0.7 m combined
Operation / Development protection
A protective support stand is recommended during demonstrations and development
SDK base joints / Left ankle pitch
70 N·m; [-58, 24]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
SDK base joints / Left elbow pitch
27 N·m; [-130, 10]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
SDK base joints / Left forearm yaw
27 N·m; [-160, 160]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
SDK base joints / Right ankle roll
70 N·m; [-15, 15]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
SDK base joints / Right knee pitch
150 N·m; [0, 135]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
Development / SDK command frequency
500 Hz
Development / Secondary development
Supported for EDU
Documentation / Developer resources
SDK documentation and technical guidance
SDK base joints / Right ankle pitch
70 N·m; [-58, 24]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
SDK base joints / Right elbow pitch
27 N·m; [-130, 10]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
SDK base joints / Right forearm yaw
27 N·m; [-160, 160]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
Connectivity / Wireless connectivity
Wi-Fi 6 / Bluetooth 5.2
SDK base joints / Left shoulder roll
27 N·m; [0, 135]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
SDK base joints / Left upper arm yaw
27 N·m; [-150, 150]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
SDK base joints / Left shoulder pitch
27 N·m; [-163, 163]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
SDK base joints / Right shoulder roll
27 N·m; [-135, 0]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
SDK base joints / Right upper arm yaw
27 N·m; [-150, 150]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
SDK base joints / Right shoulder pitch
27 N·m; [-163, 163]° (Base arrangement with 23 joints; source does not specify rated or peak torque)
Basic SDK configuration / Powered joints
23 (Basic SDK arrangement; additional joints and dexterous fingers excluded.)