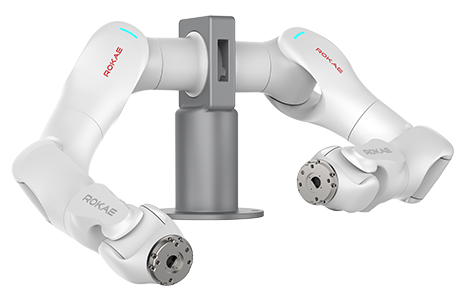
Category
Collaborative Robots and Manipulators
Single-arm specifications / Noise
≤60 dB
Single-arm specifications / Arm DOF
7 DOF (Per arm.)
Options and control / SDK algorithms
Dynamics, kinematics, impedance control, hybrid force/position control, collision detection
Single-arm specifications / Arm weight
8 kg (Brochure dated 31 August 2026; one arm, not the complete illustrated dual-arm stand.)
Options and control / Admittance control
Single-arm operation; parameters updated in real time during execution
Single-arm specifications / Axis 1 range
±178 ° (Brochure dated 31 August 2026.)
Single-arm specifications / Axis 2 range
±120 ° (Brochure dated 31 August 2026.)
Single-arm specifications / Axis 3 range
±178 ° (Brochure dated 31 August 2026.)
Single-arm specifications / Axis 4 range
-60…+145 ° (Brochure dated 31 August 2026.)
Single-arm specifications / Axis 5 range
±178 ° (Brochure dated 31 August 2026.)
Single-arm specifications / Axis 6 range
±60 ° (Brochure dated 31 August 2026.)
Single-arm specifications / Axis 7 range
±90 ° (Brochure dated 31 August 2026.)
Single-arm specifications / Joint brakes
Joints with holding brakes
Single-arm specifications / ROS2 support
Supported
Single-arm specifications / Wrist design
Cross-axis wrist
Single-arm specifications / Arm IP rating
IP54
Single-arm specifications / Rated payload
3 kg (Per arm.)
Single-arm specifications / Camera cabling
Internal routing supported
Single-arm specifications / EtherCAT cycle
1±0.1 ms (Brochure dated 31 August 2026.)
Single-arm specifications / Supply voltage
48 V DC (±15% tolerance; external power supply.)
Single-arm specifications / CAN FD protocol
Supported
Single-arm specifications / RS-485 protocol
Supported
Options and control / Joint data acquisition
Real-time force-control and motion data from all joints
Single-arm specifications / Arm construction
Integrated and modular
Single-arm specifications / Load recognition
Automatic
Single-arm specifications / Operating radius
650 mm (Brochure dated 31 August 2026.)
Single-arm specifications / Safety functions
22 functions described by the manufacturer as TÜV-certified
Single-arm specifications / Communication bus
EtherCAT (Arm communication bus.)
Single-arm specifications / Maximum TCP speed
≥2 m/s (Tool centre point speed, not platform travel speed.)
Single-arm specifications / Encoder redundancy
Dual-encoder design
Single-arm specifications / Operating humidity
10…90 % RH (Non-condensing.)
Options and control / End six-axis force sensor
Supported as an option
Options and control / Optional sensor: accuracy
≤2 % F.S. (End six-axis force sensor.)
Single-arm specifications / Collision detection
Supported
Single-arm specifications / Impact acceleration
10 g (Reference GB/T 39266-2020.)
Single-arm specifications / Joint torque sensors
Standard
Single-arm specifications / Software development
High-order algorithm SDK
Single-arm specifications / Vibration resistance
GB/T 4798.5-2007, severity 5M2
Single-arm specifications / Joint hollow aperture
6 mm
Single-arm specifications / Operating temperature
0…50 °C (Temperature rise ≤30°C; overall machine temperature ≤60°C.)
Options and control / Optional sensor: force range
200 N (End six-axis force sensor.)
Single-arm specifications / Force control accuracy
≤0.15 N (Reference value.)
Single-arm specifications / Position repeatability
±0.1 mm
Options and control / Optional sensor: torque range
7 N·m (End six-axis force sensor.)
Single-arm specifications / Torque control accuracy
≤0.05 N·m (Reference value.)
Single-arm specifications / Force control resolution
≤0.05 N (Reference value.)
Single-arm specifications / Torque loop architecture
Initial scheme: controller torque loop; advanced scheme: joint torque loop
Single-arm specifications / Torque control resolution
≤0.02 N·m (Reference value.)
Single-arm specifications / Arm force control bandwidth
>30 Hz (Whole-arm figure; not the bandwidth of a separate joint.)
Single-arm specifications / Absolute positioning accuracy
±1 mm
Single-arm specifications / Force sensor overload capacity
≥300 % F.S.
Single-arm specifications / Force sensor sampling frequency
≥5 kHz
Single-arm specifications / Comprehensive force control accuracy
≤1 % F.S.