← Back to Robots
Palletizing Robots

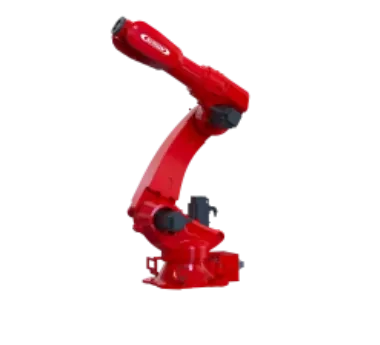
SIASUN SR270A-270/2.70

Submit correction
Request a Quote

About SIASUN SR270A-270/2.70

SIASUN SR270A-270/2.70 carries heavy tools and parts in welding, assembly and material-transfer applications.


Manufacturer

🏢

SIASUN

CN

Key Specifications

Reach
2700 mm
Status
ACTIVE
Category
Palletizing Robots
Arm / Payload
270 kg
Axis ranges / J1
±180 °
Axis ranges / J2
+80 / −60 °
Axis ranges / J3
+168 / −74 °
Axis ranges / J4
±360 °
Axis ranges / J5
±125 °
Axis ranges / J6
±360 °
Wrist moment / J4
1785 Nm
Wrist moment / J5
1500 Nm
Wrist moment / J6
950 Nm
Control / Planning
Variable acceleration
Arm / Working reach
2700 mm
Mounting / Position
Upright
Arm / Number of axes
6
Drive / Transmission
Gear transmission
Allowable inertia / J4
340 kg·m²
Allowable inertia / J5
340 kg·m²
Allowable inertia / J6
260 kg·m²
SRC L6 cabinet / Weight
145 kg (When this cabinet is selected.)
Maximum axis speeds / J1
120 °/s
Maximum axis speeds / J2
100 °/s
Maximum axis speeds / J3
100 °/s
Maximum axis speeds / J4
166 °/s
Maximum axis speeds / J5
140 °/s
Maximum axis speeds / J6
210 °/s
SRC L6 cabinet / Storage
4 GB (When this cabinet is selected.)
Applications / Operations
Spot welding, handling, assembly, adhesive application, stud welding, SPR
SRC L6 cabinet / Humidity
≤90 % (When this cabinet is selected. No condensation.)
Control / Process packages
For multiple industries
Mechanical unit / Arm mass
1382 kg
Control / Controller choices
SRC L6 (System parameters depend on the selected cabinet; these are alternative configurations.)
SRC L6 cabinet / CC-Link Slave
Optional (When this cabinet is selected.)
SRC L6 cabinet / I/O expansion
up to 64 DI/DO (When this cabinet is selected. Optional expansion;64DI/DO is not separately enumerated as inputs/outputs.)
Signal cable / Conductor count
32 pcs
SRC L6 cabinet / Digital inputs
16 channels (When this cabinet is selected. Standard NPN.)
SRC L6 cabinet / Supply voltage
380 (When this cabinet is selected. 3 phase(s).) V AC
SRC L6 cabinet / Digital outputs
16 channels (When this cabinet is selected. Standard NPN.)
SRC L6 cabinet / Supply tolerance
−10…+10 % (When this cabinet is selected.)
SRC L6 cabinet / Ethernet, options
EtherCAT Slave / EtherNet/IP Master (When this cabinet is selected.)
SRC L6 cabinet / Digital I/O option
PNP (When this cabinet is selected.)
SRC L6 cabinet / Ethernet, standard
TCP/IP / Profinet Slave / Profinet Master / Modbus TCP Slave / EtherNet/IP Slave (When this cabinet is selected.)
SRC L6 cabinet / Fieldbus, standard
DeviceNet Master (When this cabinet is selected.)
Wrist protection / Protection rating
IP67 (Wrist only, explicitly scoped in the technical table.)
SRC L6 cabinet / Enclosure protection
IP54 (When this cabinet is selected.)
Repeatability / Position repeatability
±0.06 mm
SRC L6 cabinet / Operating temperature
0…45 °C (When this cabinet is selected.)
Signal cable / Conductor cross-section
0.2 mm²
Robot protection / Whole-robot protection
IP54

Verified ecosystem

Software and resources

Official links and community projects are shown separately. Every published relationship has reviewable evidence.

0
verified official resources
0
verified compatible projects
0
public maintainers
No activity yet
latest verified ecosystem activity

Projects are ordered only within this robot ecosystem using verified compatibility, GitHub freshness and activity, and accepted community reports. This is not a global RobotSpace score.

Official resources

No first-party resource has been independently verified yet. Unverified catalog links are not shown as official.

Official software

No official software project has been verified yet.

Community projects

No verified community project has been linked yet.

Developers and contributors

No public maintainer profile is linked yet.

Verified activity

No verified project activity is available.

This ecosystem is still empty

The robot page remains useful for specifications while official resources and compatible projects are being verified.

Imported from the Unibot owner catalog · Not independently verified · Imported 2026-11-11 · Unibot source · Methodology