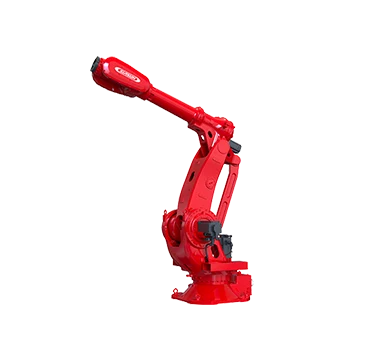
Category
Palletizing Robots
Drive / Motors
Manufacturer-developed
Drive / Axis five
Anti-backlash gearbox
Arm / Working reach
3200 mm
Mounting / Position
Upright
Allowable inertia / J4
215 kg·m²
Allowable inertia / J5
215 kg·m²
Allowable inertia / J6
140 kg·m²
SRC L6 cabinet / Weight
145 kg (When this cabinet is selected.)
Design / Balance linkage
Not used
Maximum axis speeds / J1
100 °/s
Maximum axis speeds / J2
90 °/s
Maximum axis speeds / J3
90 °/s
Maximum axis speeds / J4
120 °/s
Maximum axis speeds / J5
110 °/s
Maximum axis speeds / J6
160 °/s
SRC L6 cabinet / Storage
4 GB (When this cabinet is selected.)
Applications / Operations
Spot welding, handling, loading/unloading, adhesive application, visual inspection, assembly
SRC L6 cabinet / Humidity
≤90 % (When this cabinet is selected. No condensation.)
Mechanical unit / Arm mass
2100 kg
Control / Controller choices
SRC L6 (System parameters depend on the selected cabinet; these are alternative configurations.)
SRC L6 cabinet / CC-Link Slave
Optional (When this cabinet is selected.)
SRC L6 cabinet / I/O expansion
up to 64 DI/DO (When this cabinet is selected. Optional expansion;64DI/DO is not separately enumerated as inputs/outputs.)
Signal cable / Conductor count
32 pcs
Control cabinet / External axes
Reserved space for drive installation
SRC L6 cabinet / Digital inputs
16 channels (When this cabinet is selected. Standard NPN.)
SRC L6 cabinet / Supply voltage
380 (When this cabinet is selected. 3 phase(s).) V AC
SRC L6 cabinet / Digital outputs
16 channels (When this cabinet is selected. Standard NPN.)
SRC L6 cabinet / Supply tolerance
−10…+10 % (When this cabinet is selected.)
SRC L6 cabinet / Ethernet, options
EtherCAT Slave / EtherNet/IP Master (When this cabinet is selected.)
SRC L6 cabinet / Digital I/O option
PNP (When this cabinet is selected.)
SRC L6 cabinet / Ethernet, standard
TCP/IP / Profinet Slave / Profinet Master / Modbus TCP Slave / EtherNet/IP Slave (When this cabinet is selected.)
SRC L6 cabinet / Fieldbus, standard
DeviceNet Master (When this cabinet is selected.)
Wrist protection / Protection rating
IP67 (Wrist only, explicitly scoped in the technical table.)
SRC L6 cabinet / Enclosure protection
IP54 (When this cabinet is selected.)
Repeatability / Position repeatability
±0.1 mm
SRC L6 cabinet / Operating temperature
0…45 °C (When this cabinet is selected.)
Signal cable / Conductor cross-section
0.2 mm²
Control cabinet / Communication protocols
Mainstream protocols supported (Specific protocols are not identified.)