← Back to Robots
Wheeled Robots and AMRs

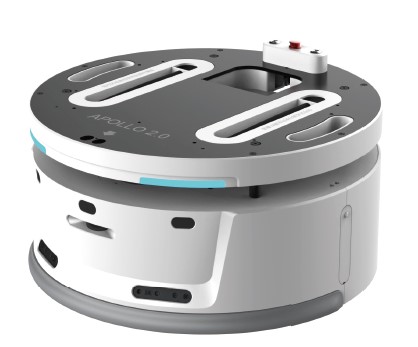
SLAMTEC Apollo 2.0

Submit correction
Request a Quote

About SLAMTEC Apollo 2.0

SLAMTEC Apollo 2.0 is an indoor mobile platform for developing delivery robots and equipment transport systems.


Manufacturer

🏢

SLAMTEC

CN

Key Specifications

Status
ACTIVE
Category
Wheeled Robots and AMRs
Technical specifications / Mass
40 kg
Technical specifications / Height
270 mm
Technical specifications / Sensors
1 LiDAR; 2 depth cameras; 3 ultrasonic (Magnetic sensors disabled by default)
Technical specifications / Charging
360 min (Fast-charging station in table; optional 1C: 30-80% in 1 h, not standard supply)
Technical specifications / Diameter
520 mm (Round chassis; not length × width)
Technical specifications / Interfaces
Gigabit Ethernet; Wi-Fi 2.4/5 GHz; HTTP API; SDK2
Technical specifications / Gap crossing
40 mm (Rated payload; 60 mm requires customized wheels)
Technical specifications / Maximum speed
4.32 km/h (1.5 m/s customizable; default 0.7 m/s)
Technical specifications / Rated payload
80 kg (Maximum 100 kg on flat concrete)
Technical specifications / Step crossing
20 mm (Rated payload)
Technical specifications / Climbing slope
10 °
Technical specifications / Loaded runtime
840 min (Full payload 80 kg)
Technical specifications / Minimum corridor
70 cm
Technical specifications / Manufacturer capacity marking
29.4 mAh (Printed unit is mAh; unit requires clarification)

Verified ecosystem

Software and resources

Official links and community projects are shown separately. Every published relationship has reviewable evidence.

0
verified official resources
0
verified compatible projects
0
public maintainers
No activity yet
latest verified ecosystem activity

Projects are ordered only within this robot ecosystem using verified compatibility, GitHub freshness and activity, and accepted community reports. This is not a global RobotSpace score.

Official resources

No first-party resource has been independently verified yet. Unverified catalog links are not shown as official.

Official software

No official software project has been verified yet.

Community projects

No verified community project has been linked yet.

Developers and contributors

No public maintainer profile is linked yet.

Verified activity

No verified project activity is available.

This ecosystem is still empty

The robot page remains useful for specifications while official resources and compatible projects are being verified.

Imported from the Unibot owner catalog · Not independently verified · Imported 2026-11-11 · Unibot source · Methodology