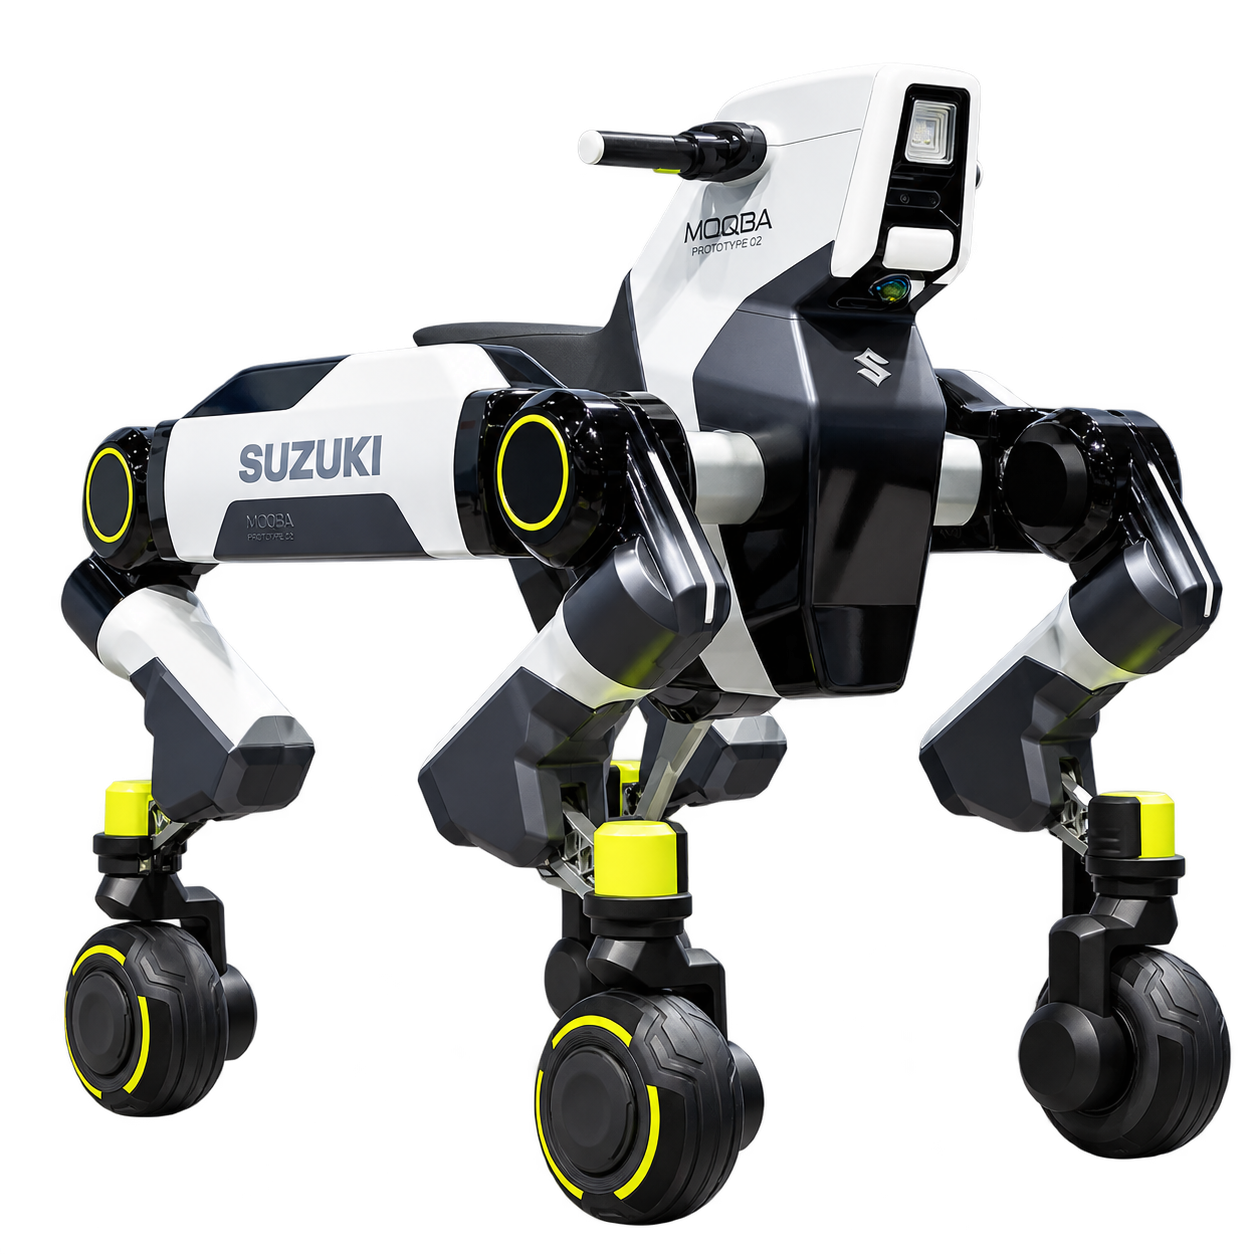
About Suzuki MOQBA 2
Suzuki MOQBA 2 is a four-legged mobility concept presented at Japan Mobility Show 2025.
Key Specifications
Verified ecosystem
Software and resources
Official links and community projects are shown separately. Every published relationship has reviewable evidence.
Projects are ordered only within this robot ecosystem using verified compatibility, GitHub freshness and activity, and accepted community reports. This is not a global RobotSpace score.
Official resources
No first-party resource has been independently verified yet. Unverified catalog links are not shown as official.
Official software
No official software project has been verified yet.
Community projects
No verified community project has been linked yet.
Developers and contributors
No public maintainer profile is linked yet.
Verified activity
No verified project activity is available.
This ecosystem is still empty
The robot page remains useful for specifications while official resources and compatible projects are being verified.
Imported from the Unibot owner catalog · Not independently verified · Imported 2026-11-11 · Unibot source · Methodology