← Back to Robots
Wheeled Robots and AMRs

SwagBot

Submit correction
Request a Quote

About SwagBot

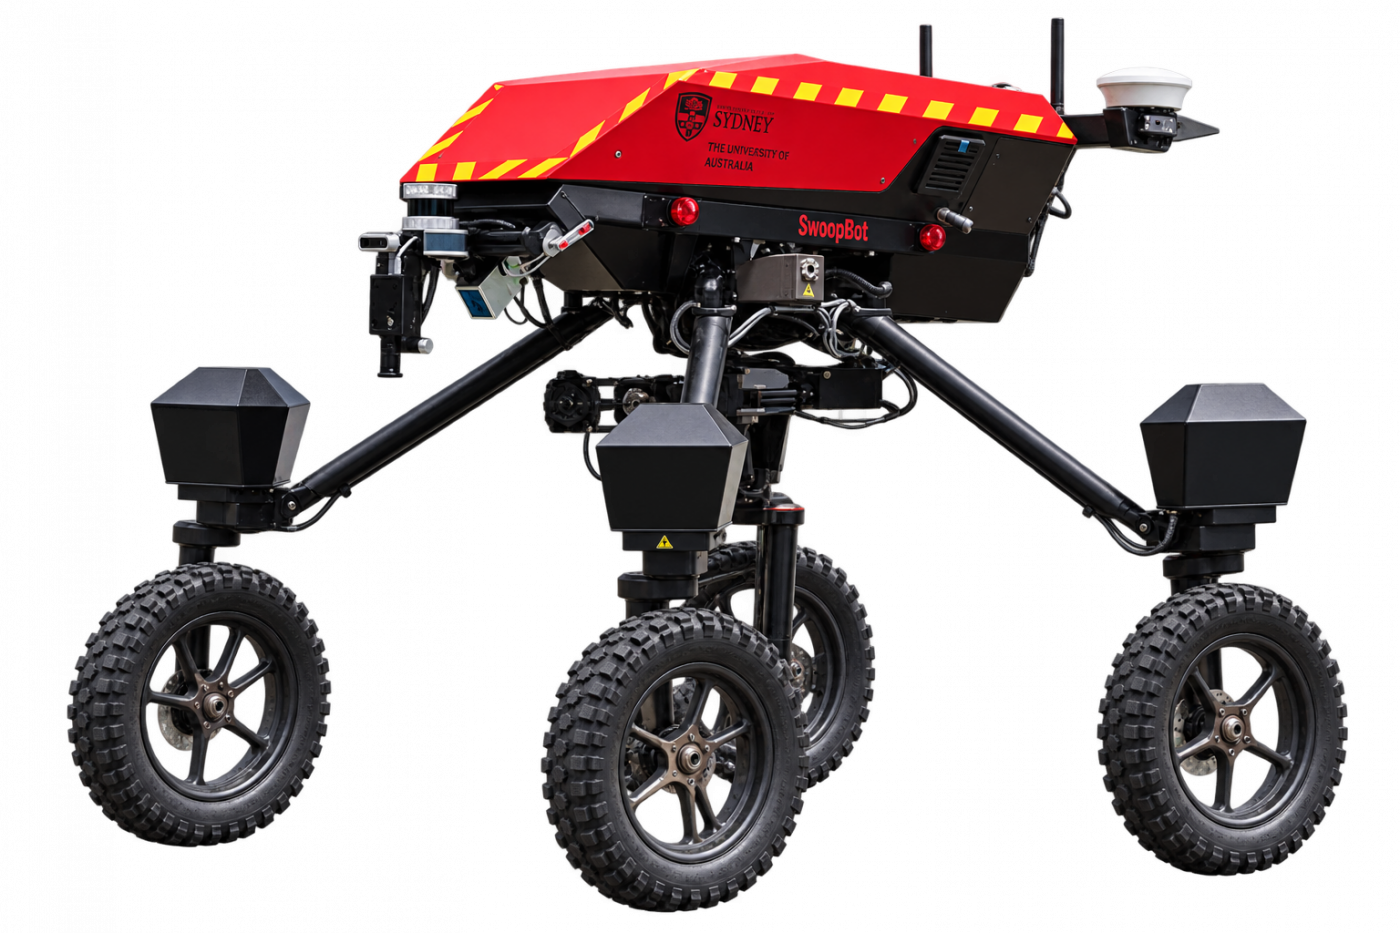
SwagBot is an electric ground robot developed at the University of Sydney for pasture and livestock farming research.


Manufacturer

Key Specifications

Status
ACTIVE
Category
Wheeled Robots and AMRs
Platform / Power
Electric
Platform / Wheels
4 (Configuration shown in the official project photograph)
Platform / Purpose
Agricultural research
Platform / Developer
The University of Sydney
Platform / Environment
Difficult and undulating terrain
Platform / Research centre
Australian Centre for Field Robotics
Platform / Developer country
Australia
Monitoring and research / Pastures
Field measurement
Monitoring and research / Livestock
Location monitoring
Project development / Autonomous tasks
Pasture monitoring, weed management and livestock herding (Described in the university commercialisation announcement of 8 April 2019; not a standard package specification)
Project development / Commercialisation
Agerris (Historical University of Sydney announcement of 8 April 2019)
Monitoring and research / Infrastructure
Farm infrastructure monitoring
Project development / Targeted treatment
Weed spraying (Research application requiring appropriate treatment equipment)
Monitoring and research / Data collection
Onboard sensors

Verified ecosystem

Software and resources

Official links and community projects are shown separately. Every published relationship has reviewable evidence.

0
verified official resources
0
verified compatible projects
0
public maintainers
No activity yet
latest verified ecosystem activity

Projects are ordered only within this robot ecosystem using verified compatibility, GitHub freshness and activity, and accepted community reports. This is not a global RobotSpace score.

Official resources

No first-party resource has been independently verified yet. Unverified catalog links are not shown as official.

Official software

No official software project has been verified yet.

Community projects

No verified community project has been linked yet.

Developers and contributors

No public maintainer profile is linked yet.

Verified activity

No verified project activity is available.

This ecosystem is still empty

The robot page remains useful for specifications while official resources and compatible projects are being verified.

Imported from the Unibot owner catalog · Not independently verified · Imported 2026-11-11 · Unibot source · Methodology