← Back to Robots
Humanoid

UBTECH Cruzr Y1

Submit correction
Request a Quote

About UBTECH Cruzr Y1

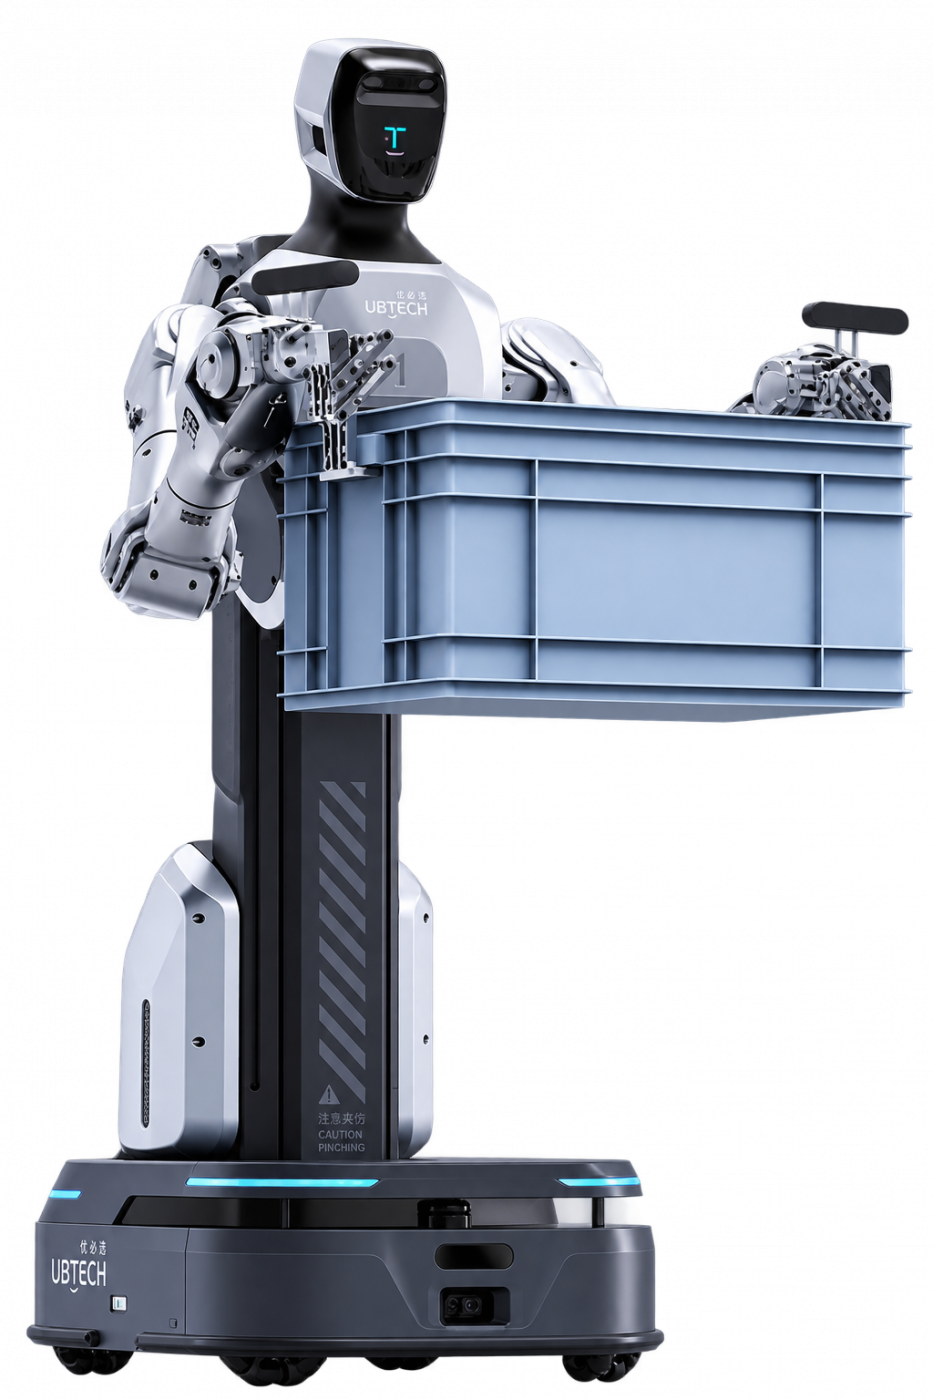
UBTECH Cruzr Y1 combines two anthropomorphic arms with an omnidirectional wheeled base for industrial material handling.


Manufacturer

🏢

UBTECH

CN

Key Specifications

Reach
750 mm
Status
ACTIVE
Category
Humanoid
Perception / Sensor
LiDAR
Power / Battery life
>4 h (Operating mode and load not specified)
Power / Charging time
<1.5 h
Applications / Sorting
Mixed materials and unordered placement
Construction / Mobility
Omnidirectional wheeled base
Manipulation / Arm reach
750 mm
Applications / Palletizing
Box-size matching and production-line integration
Power / Automatic charging
Supported
Power / Battery replacement
Quick swap
Manipulation / Single-arm DOF
7
Perception / Distance sensors
ToF
Software architecture / Tools
Tool use
Applications / Machine tending
Loading and unloading CNC and molding machines
Construction / Manual movement
Handle for manual pushing
Manipulation / Gripped objects
Bins, cartons and irregular items
Manipulation / Gripper changes
Modular quick-change design
Software architecture / Memory
Memory management
Software architecture / Models
Multimodal reasoning and interaction models
Interaction / Voice interaction
Supported
Manipulation / Dual-arm payload
10 kg (Two arms working together)
Construction / In-place rotation
360 °
Manipulation / Arm repeatability
±0.5 mm
Perception / Perception coverage
360 °
Software architecture / Planning
Intent understanding and task planning
Software architecture / Platform
Co-Agent
Software architecture / Task models
Task-specific models
Manipulation / Vertical working reach
0–1.8 m (Vertical lift for shelves and production lines)
Construction / Narrow-aisle navigation
0.8 m (Load configuration not specified)
Software architecture / Anomaly handling
Anomaly detection and handling
Applications / Stack disturbance handling
Action correction after stack displacement or collapse
Software architecture / Application framework
ROSA

Verified ecosystem

Software and resources

Official links and community projects are shown separately. Every published relationship has reviewable evidence.

0
verified official resources
0
verified compatible projects
0
public maintainers
No activity yet
latest verified ecosystem activity

Projects are ordered only within this robot ecosystem using verified compatibility, GitHub freshness and activity, and accepted community reports. This is not a global RobotSpace score.

Official resources

No first-party resource has been independently verified yet. Unverified catalog links are not shown as official.

Official software

No official software project has been verified yet.

Community projects

No verified community project has been linked yet.

Developers and contributors

No public maintainer profile is linked yet.

Verified activity

No verified project activity is available.

This ecosystem is still empty

The robot page remains useful for specifications while official resources and compatible projects are being verified.

Imported from the Unibot owner catalog · Not independently verified · Imported 2026-11-11 · Unibot source · Methodology