External connectivity / CAN
2 ports
External connectivity / GMSL
4 ports
Computing system / T5000: CPU
14-core 64-bit Arm Neoverse-V3AE
Computing system / T5000: GPU
NVIDIA Blackwell, 2560 cores
Power and equipment / Battery
Low-resistance lithium battery
Power and equipment / Charger
Listed (Listed by the manufacturer as equipment.)
Power and equipment / Cooling
Air cooling
Body and motion / Joint motors
Low-inertia, high-speed inner-rotor permanent-magnet synchronous motors
External connectivity / RS-485
4 ports
Computing system / Platform PC1
Intel Core i5 (Base computing for platform functions.)
External connectivity / USB 2.0
2 ports
External connectivity / USB 3.0
3 ports
Computing system / T5000: memory
128 GB LPDDR5X
External connectivity / USB + DP
3 ports
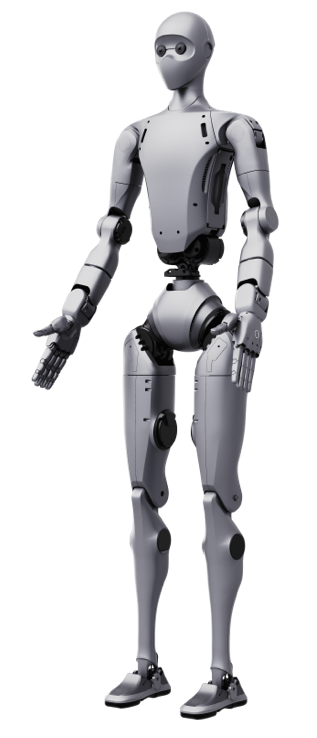
Body and motion / Standing height
182 cm
Body and motion / Peak arm payload
≈15 kg (Peak value; varies with scenario and configuration.)
Computing system / Development PC2
Intel Core i7 (Base computing for user development.)
Computing system / T5000: L2 cache
1 MB per core
Power and equipment / Battery life
≈180 min (Payload and duty cycle are not specified.)
Body and motion / Rated arm payload
≈7 kg (Not a combined two-arm payload; varies with scenario and configuration.)
Cameras and perception / Head camera
Stereo camera
Computing system / AI compute module
NVIDIA Jetson T5000
Computing system / T5000: memory bus
256 bit
Power and equipment / Battery energy
0.972 kWh
Body and motion / Main body materials
Aerospace-grade aluminium, titanium alloy and high-strength engineering plastics
Body and motion / Weight with battery
≈70 kg (The optional hand configuration used for the weight figure is not specified.)
Computing system / T5000: SSD storage
Supported through USB 3.2
Computing system / T5000: NVMe storage
Supported through PCIe
Computing system / T5000: Tensor Cores
5th generation
Power and equipment / Battery capacity
15 Ah
Body and motion / Joint output bearings
Industrial-grade crossed roller
Body and motion / Peak arm-joint torque
120 N·m (The value may vary with scenario and configuration.)
Body and motion / Peak leg-joint torque
360 N·m (The value may vary with scenario and configuration.)
Computing system / T5000: CPU frequency
≤2.6 GHz
Computing system / T5000: GPU frequency
≤1.57 GHz
Computing system / T5000: AI performance
2070 TFLOPS (FP4, sparse computation.)
Computing system / T5000: video decoding
2 × NVDEC
Computing system / T5000: video encoding
2 × NVENC
External connectivity / BAT power output
1 output
External connectivity / Gigabit Ethernet
4 ports
Body and motion / Body degrees of freedom
31 DOF (Number of joint motors, excluding optional dexterous hands.)
Computing system / T5000: shared L3 cache
16 MB
External connectivity / 12 V power output
1 output
External connectivity / 24 V power output
2 output
Body and motion / Degrees of freedom: Head
2 DOF
Computing system / T5000: memory bandwidth
273 GB/s
Body and motion / Degrees of freedom: Waist
3 DOF
External connectivity / Wireless interfaces
Wi-Fi 6; Bluetooth 5.2
Power and equipment / Remote emergency stop
Yes
Computing system / T5000: Multi-Instance GPU
10 TPC
Computing system / T5000: configurable power
40–130 W (Compute module, not the whole robot.)
Computing system / T5000: vision accelerator
1 × PVA v3
Body and motion / Degrees of freedom: One arm
7 DOF
Body and motion / Degrees of freedom: One leg
6 DOF
Body and motion / Standing dimensions H×W×D
182 × 45.6 × 21.8 cm
Cameras and perception / Head camera: shutter
Global
Development and software platform / Isaac ROS
Deployment of trained policies onto the robot
Power and equipment / Maximum battery voltage
75.6 V
Body and motion / Lower and upper leg combined
104.5 cm
Cameras and perception / Head camera: aperture
2.0
Power and equipment / Microphones and speakers
Array microphones and high-power speakers
Body and motion / Forearm and upper arm combined
69 cm
Cameras and perception / Head camera: resolution
5 MP
Development and software platform / Isaac TeleOp
Robot demonstration data capture
Development and software platform / OTA upgrades
Supported
Power and equipment / Handheld remote controller
Listed (Listed by the manufacturer as equipment.)
Power and equipment / Quick-release smart battery
Yes
Cameras and perception / Head camera: focal length
2.67 mm
Cameras and perception / Inertial measurement unit
Yes
Cameras and perception / Head camera: depth of field
0.4–∞ m (Optical depth of field, not a depth-measurement range.)
Cameras and perception / Wrist cameras: FOV, optional
196° H × 154° V (Optional cameras.)
Manufacturer reference terms / Unitree warranty period
12 months (Manufacturer reference period; detailed terms are defined in Unitree’s warranty brochure.)
Development and software platform / Development platform
NVIDIA Isaac GR00T
Cameras and perception / Wrist cameras: shutter, optional
Global (Optional cameras.)
Development and software platform / Secondary development
Supported (Development procedures are covered by the manufacturer’s secondary-development manual.)
SharpaWave hand - optional / SharpaWave, optional: weight
1.3 kg (Per optional hand.)
Development and software platform / Demonstrated functions
Some functions remain in development (Some examples on the product page are still being developed and tested and will be opened to users later.)
Development and software platform / Jetson Thor: execution
Real-time onboard inference and control
Development and software platform / Isaac Sim and Isaac Lab
Simulation, training, testing and policy evaluation
Cameras and perception / Head camera: Vertical field of view
102 ±3 °
Cameras and perception / Wrist cameras: resolution, optional
3 MP (Optional cameras.)
Development and software platform / Isaac GR00T: open models
Development of reasoning, learning and multitask behaviour
SharpaWave hand - optional / SharpaWave, optional: dimensions
20.8 × 9 × 5 cm (Per optional hand. Axis order is not specified.)
SharpaWave hand - optional / SharpaWave, optional: grip force
150 N (Per optional hand.)
Cameras and perception / Head camera: Horizontal field of view
140 ±3 °
Optional configuration / Body and two hands: degrees of freedom
75 DOF (With two optional SharpaWave hands, each with 22 active DOF; body - 31 DOF.)
SharpaWave hand - optional / SharpaWave, optional: hand payload
30 kg (Per optional hand. Hand specification, not the robot arm payload rating.)
SharpaWave hand - optional / SharpaWave, optional: tactile pixels
>1000 (Per optional hand. Per fingertip.)
SharpaWave hand - optional / SharpaWave, optional: fingertip force
20 N (Per optional hand.)
SharpaWave hand - optional / SharpaWave, optional: force sensitivity
0.005 N (Per optional hand.)
SharpaWave hand - optional / SharpaWave, optional: operating frequency
>4 Hz (Per optional hand.)
SharpaWave hand - optional / SharpaWave, optional: force detection range
0–30 N (Per optional hand.)
SharpaWave hand - optional / SharpaWave, optional: fingertip repeatability
±1 mm (Per optional hand.)
SharpaWave hand - optional / SharpaWave, optional: active degrees of freedom
22 DOF (Per optional hand.)