The secret of humanoid marathon robots
English translation from Unibot. Source published 2026-06-18.
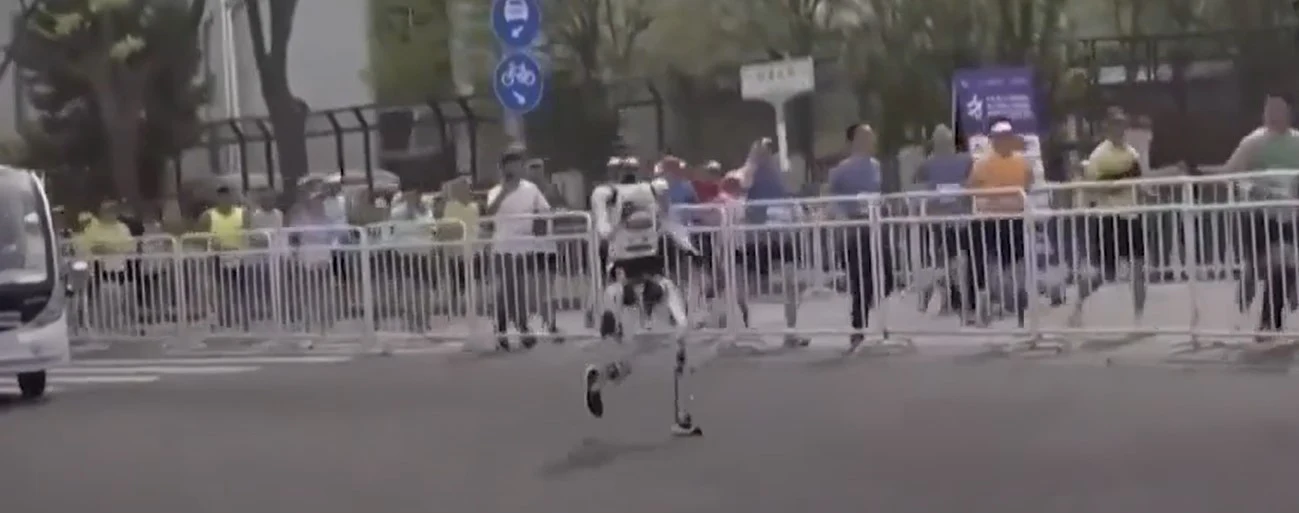
On April 19, 2026, the humanoid robot Honor Lightning ran a half marathon in 50 minutes 26 seconds. This is 7 minutes faster than the human world record and almost two hours better than the best robot of 2025.
How did they do it? Is there some kind of magical technology or special method behind this? Why did they bypass the much more famous Unitree (which, according to rumors, even froze an ice backpack to the robot so that it would not overheat and reach the finish line)?
The Physics of Running and Tradeoffs
My doctoral dissertation was on the creation and control of jumping and running robots. Since then, I've tried to design and build efficient commercial walking machines, so I'm no stranger to the limitations. In this article we will analyze the fundamental laws of physics that are behind this record and try to answer all the questions.
Running is an alternation of two phases: the foot rests on the ground (the support phase) and the body flies through the air (the flight phase). In the air, the body falls under the influence of gravity, losing vertical momentum. During the stance phase, the leg pushes off the ground to return upward momentum, while the other leg is brought forward for the next step.
Electric motors spend energy creating torque: the higher it is, the more energy goes into heat. If you place a gearbox after the motor, it increases the torque and reduces the speed. A high gear ratio helps with torque, but the rotor of the motor itself is forced to spin faster, and it takes longer to accelerate the output shaft. This is, of course, bad for the leg swing phase.
These contradictory effects lead to the fact that each motor has its own “golden ratio” gear ratio:
The power consumption of the robot leg is minimal at the optimal gear ratio (in this example, 30:1). Avik De / Datawrapper
The Secret of Honor's Record
The characteristics of the Lightning motors are not disclosed, but based on the appearance of the hips and knees, their outer diameter is approximately 110-150 mm. For approximate calculations, I took the ILM115x25 motor - it is close in size, and there are detailed data on it. A simple physical model allows you to estimate the energy consumption when running at a speed of 7 m/s (the average Lightning pace for a half marathon) depending on the gear ratio:
The blue curve shows how to select the optimal gearbox (45:1). Dark blue - how much heat will be generated in the knee motor: about 150 W at the optimal gear ratio. Avik De / Datawrapper
As you can see, there is no miracle in the drive. With a properly selected gearbox (we'll come back to this later), the robot consumes a very reasonable 400 W. But the power dissipation in the knee is approximately 150 W, and this is the main thermal limitation. There is almost no escape from it: if a humanoid robot runs at human speed, it will inevitably heat up that way. Keeping the motor from overheating for a long time is still a challenge, but Lightning has an ace up its sleeve.
According to Honor, liquid cooling penetrates inside the motors like capillaries. A powerful pump pumps more than 4 liters of coolant per minute. Each of the four lower limb drive motors has its own independent circuit.
Liquid cooling is not a new thing, but it’s not consumer goods either. It comes up in research from time to time. From commercial developments, Apptronik has tried it on several prototypes, but does not use it on the main Apollo platform (as far as I know). Conventional air cooling would not be able to continuously transfer 150 watts from a knee motor - so cooling technology was the key to this result.
Why are competitors lagging behind?
Why did Honor's competitors - including the more famous and mass-produced humanoids from Unitree or Agibot - perform worse? The same model can be applied to walking at a speed of 1.5 m/s. This is much more modest, but perhaps more necessary for a commercial robot:
Solid and dotted blue lines - design optimized for running. Green - for walking. The optimal gear ratio for walking is much lower (30:1 versus 45:1). But the power dissipated in the knee when running (dark blue) is much higher at 30:1 than at 45:1. This is the price for trying to run on a “walking” structure.
Avik De/Datawrapper
A new green curve has appeared on the graph - power when walking. And the optimal gear ratio is now completely different! Let's say you're designing a robot for normal walking and you choose a green design with a 30:1 gearing. The motor power for a half marathon knee would then exceed 300 watts (red arrow) - more than double that of a design optimized for running. No wonder ice packs were needed!
And if you look at the green curve in the other direction, you can see: a robot designed for running spends extra energy when walking. Large motors designed for running add weight to the car and waste power when it is standing or walking. And in practice, such motors interfere - for example, they touch objects in houses or factories.
Engineering as the art of compromise
The Honor Half Marathon is an impressive feat of engineering. No magical breakthroughs were needed here, but capillary cooling of the motor is a noticeable step forward. Without it, this running pace would simply be unsustainable. Cooling, weight optimization and increased reliability may also come in handy for more practical applications - say, carrying heavy loads in the future.
The Honor Lightning robot [right] has much larger motors on its legs than the Unitree H1 [left]. Therefore, he runs more efficiently, but walks worse. Left: Wei Zhiyang/Zhejiang Daily Press Group/VCG/Getty Images; Right: VCG/Getty Images
However, Lightning is not as good at other tasks as a robot designed with an emphasis on versatility. Engineering is always about compromises. And the ability to choose the right ones separates good products from great ones. Against the backdrop of ever-improving AI language models, this purely human skill is becoming the most valuable thing an engineer can have.
News headlines seem to have gotten a little too excited about a robot breaking a human half-marathon record. But machines and people have completely different capabilities and limitations. Why should their half marathon times be comparable? Just as in 1997, Deep Blue beat Garry Kasparov at chess, but could not physically move the pieces - so the capabilities of the Honor robot are much narrower than those of a person who runs elbow to elbow with other runners, navigates the track visually and does without GPS.
Comparing a robot runner to a human is like comparing apples to oranges. This risks diminishing both Honor's engineering achievement and human athletic achievement.